 ROS Index

|
mapping_controller package from mapping_controller repomapping_controller |
ROS Distro
|
Package Summary
| Version | 0.0.1 |
| License | Apache License 2.0 |
| Build type | AMENT_PYTHON |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/debbynirwan/mapping_controller.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2021-08-04 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Debby Nirwan
Authors
mapping_controller
Webots ROS2 Mapping Controller
Description
The Mapping Controller package starts e-puck robot on Webots Simulator to bounce for mapping the environment. The maps can be the simple mapping from webots_ros2 or probability mapping. The maps will be saved at the given path.
Build
The following instructions assume that a ROS2 workspace is already set up.
rosdep update
rosdep install -i --from-path src --rosdistro $ROS_DISTRO -y
colcon build --packages-select mapping_controller
. install/setup.bash
Execution
After building and installing the package, you can launch the simulation.
Simple Mapping with rviz2
ros2 launch mapping_controller mapping_controller_launch.py mapper:=true rviz:=true mapping_time:=3
mapping_time is the time for the robot to bounce in minute.
Probability Mapping with rviz2
ros2 launch mapping_controller mapping_controller_launch.py probability:=true rviz:=true mapping_time:=3
Specifying path
By default the map is saved at home directory, to change it use path parameter.
ros2 launch mapping_controller mapping_controller_launch.py probability:=true rviz:=true mapping_time:=3 path:=path:="/home/$USER/Documents"
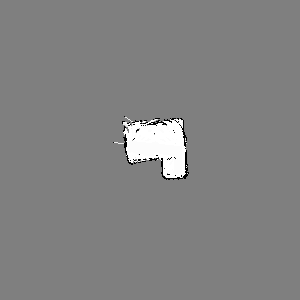
Map File Example
the map file looks like:
Dependencies
Webots ROS2 package
Documentation
If you’re interested in understanding the details, please read my post here
Issues
Please report issues if you found bugs or raise a Pull Request.
Package Dependencies
| Deps | Name |
|---|---|
| rclpy | |
| geometry_msgs | |
| sensor_msgs | |
| python-numpy | |
| webots_ros2 | |
| ament_copyright | |
| ament_flake8 | |
| ament_pep257 |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged mapping_controller at Robotics Stack Exchange
|
|
mapping_controller package from mapping_controller repomapping_controller |
ROS Distro
|
Package Summary
| Version | 0.0.1 |
| License | Apache License 2.0 |
| Build type | AMENT_PYTHON |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/debbynirwan/mapping_controller.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2021-08-04 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Debby Nirwan
Authors
mapping_controller
Webots ROS2 Mapping Controller
Description
The Mapping Controller package starts e-puck robot on Webots Simulator to bounce for mapping the environment. The maps can be the simple mapping from webots_ros2 or probability mapping. The maps will be saved at the given path.
Build
The following instructions assume that a ROS2 workspace is already set up.
rosdep update
rosdep install -i --from-path src --rosdistro $ROS_DISTRO -y
colcon build --packages-select mapping_controller
. install/setup.bash
Execution
After building and installing the package, you can launch the simulation.
Simple Mapping with rviz2
ros2 launch mapping_controller mapping_controller_launch.py mapper:=true rviz:=true mapping_time:=3
mapping_time is the time for the robot to bounce in minute.
Probability Mapping with rviz2
ros2 launch mapping_controller mapping_controller_launch.py probability:=true rviz:=true mapping_time:=3
Specifying path
By default the map is saved at home directory, to change it use path parameter.
ros2 launch mapping_controller mapping_controller_launch.py probability:=true rviz:=true mapping_time:=3 path:=path:="/home/$USER/Documents"
Map File Example
the map file looks like:
Dependencies
Webots ROS2 package
Documentation
If you’re interested in understanding the details, please read my post here
Issues
Please report issues if you found bugs or raise a Pull Request.
Package Dependencies
| Deps | Name |
|---|---|
| rclpy | |
| geometry_msgs | |
| sensor_msgs | |
| python-numpy | |
| webots_ros2 | |
| ament_copyright | |
| ament_flake8 | |
| ament_pep257 |