 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/airs-cuhk/airspeed.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-07-23 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| openarm_description | 1.0.0 |
README
AIRSPEED: An Open Source Data Production Platform for Embodied Artificial Intelligence
Welcome to the AIRSPEED GitHub repository!
Introduction
Embodied Artificial Intelligence (EAI) data acquisition is widely recognized as one of the key focuses in the development of embodied intelligence today. A critical reason is that Scaling Laws are still considered effective in the field of embodied intelligence — the better the performance of the model, the higher the demand for training data. However, data acquisition encounters difficulties in practice:
- The high cost of collecting a large amount of high-quality human demonstration and robot perception data is difficult to bear.
- It is difficult to collect data under a rich variety of training scenarios, tasks, and robot model categories.
- In the process of data collection, there are no corresponding standards or theories to guide whether the collected data has improved the quality of the dataset, whether it has increased the richness of the dataset, and by how much.
To address the above issues, we propose the open-source embodied intelligence data production platform AIRSPEED. AIRSPEED has the following features:
- Hardware-software decoupling — Reduces software costs through an open-source platform. Any device that publishes standard ROS2 messages is compatible; the data pipeline is configured entirely through YAML files without source code edits.
- Multiple devices supporting — Supports a variety of data acquisition technologies (VR controllers, cameras, robotic arms) through a uniform ROS2 topic contract, ensuring a rich variety of scenarios, tasks, and models.
- Dataset quality assurance — Boundary validation rejects malformed data (NaN/Inf) at ingest time. Post-collection format conversion (Parquet, Zarr, LeRobot v3) enables seamless integration with ML training pipelines.
- Extensible adaptor architecture — Each interface defines a topic convention. The bundled adaptors are reference implementations; new devices are added by creating a new adaptor folder following the same contract.
Architecture
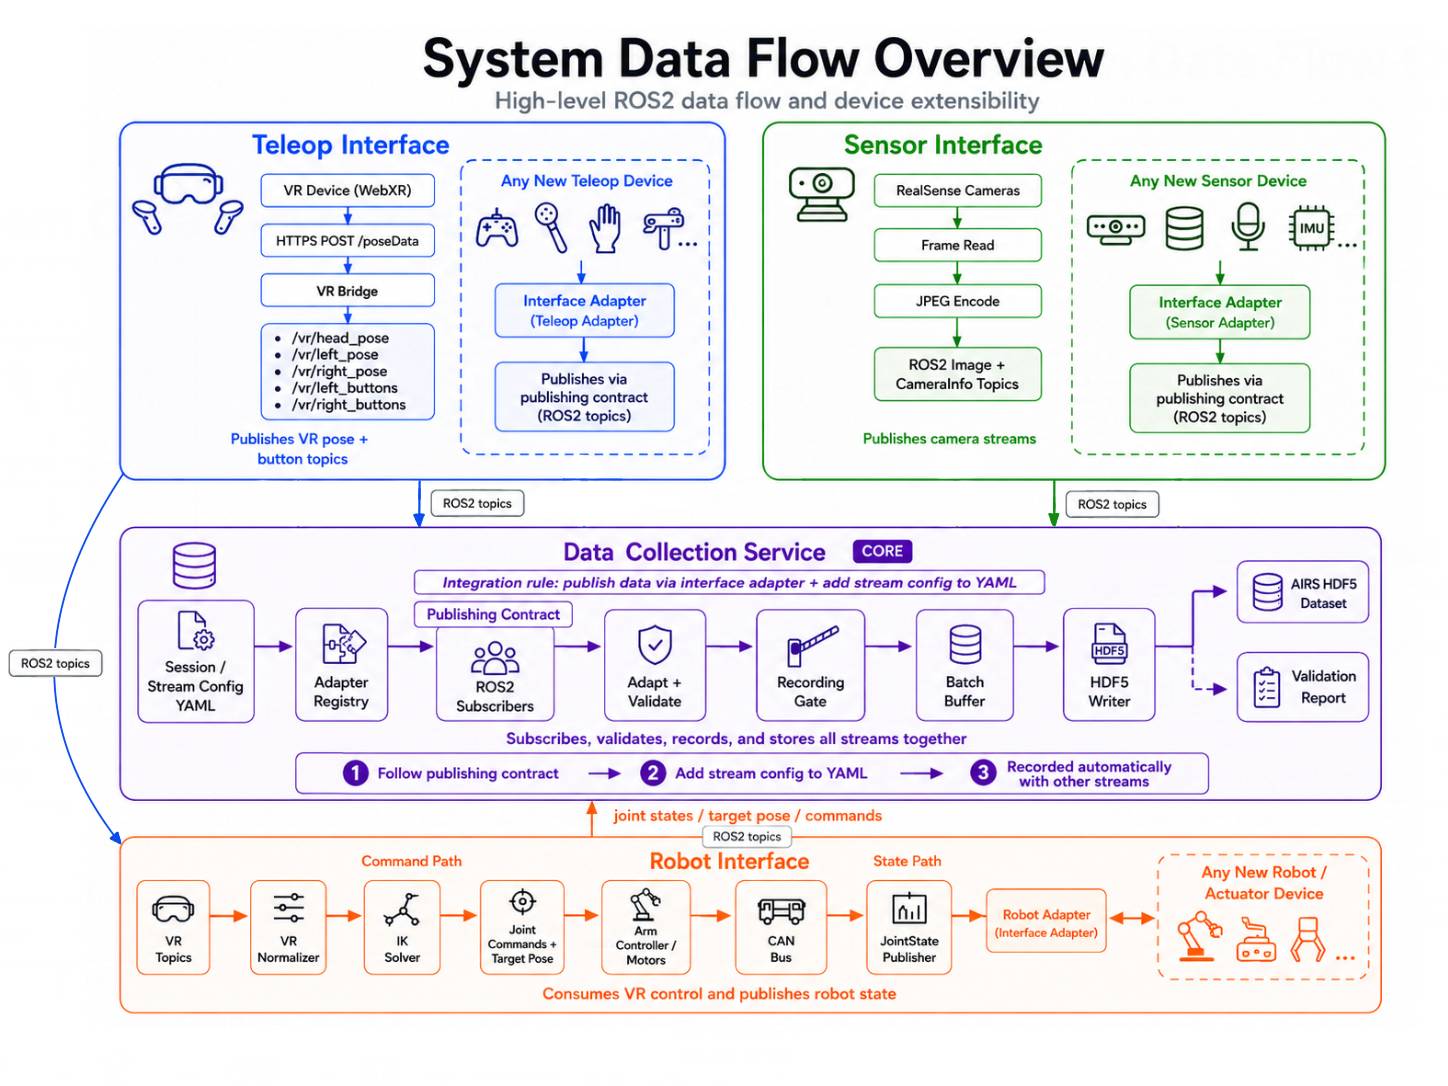
AIRSPEED v1.3 consists of three interfaces and one core service:
- The Teleoperation Interface receives data from any operator input device
(VR controller, joystick, foot pedal, etc.) and publishes standardized
PoseStampedandsensor_msgs/Joymessages to ROS2 topics. - The Robot Interface converts teleoperation commands into control parameters for any robot arm and receives joint state feedback. Includes a JAX-based inverse kinematics solver and CAN bus motor control.
- The Sensor Interface receives data from any camera or environmental
sensor and publishes
Image,CameraInfo, andImumessages. - The Data Collection Service subscribes to declared ROS2 topics, validates every message against per-stream YAML contracts, and writes AIRS-standard HDF5 episode files. A post-storage conversion pipeline outputs Parquet, Zarr, or LeRobot v3 for ML training.
Each interface defines a ROS2 topic convention in its README. To add a new device, develop a ROS2 publisher that emits the declared message types on the declared topics — the bundled adaptors are reference implementations. The data collection service has no baked-in knowledge of specific hardware.
Note: The current release (v1.3) includes Teleoperation Interface, Robot Interface, Sensor Interface, and Data Collection Service. Data generation from simulation environments and automated dataset construction are planned for future releases.
Prerequisites
-
ROS2 Humble installed at
/opt/ros/humble. -
Python 3.10. ROS2 Humble’s Python bindings are compiled against the
system Python 3.10, so the run scripts must see a 3.10 interpreter. Use the
airspeedConda environment created below, or/usr/bin/python3.10.
Quick Start
git clone https://github.com/airs-cuhk/airspeed.git
cd airspeed
Environment Setup
Each sub-project has a pyproject.toml with its dependencies. Install with your
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/airs-cuhk/airspeed.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-07-23 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| openarm_description | 1.0.0 |
README
AIRSPEED: An Open Source Data Production Platform for Embodied Artificial Intelligence
Welcome to the AIRSPEED GitHub repository!
Introduction
Embodied Artificial Intelligence (EAI) data acquisition is widely recognized as one of the key focuses in the development of embodied intelligence today. A critical reason is that Scaling Laws are still considered effective in the field of embodied intelligence — the better the performance of the model, the higher the demand for training data. However, data acquisition encounters difficulties in practice:
- The high cost of collecting a large amount of high-quality human demonstration and robot perception data is difficult to bear.
- It is difficult to collect data under a rich variety of training scenarios, tasks, and robot model categories.
- In the process of data collection, there are no corresponding standards or theories to guide whether the collected data has improved the quality of the dataset, whether it has increased the richness of the dataset, and by how much.
To address the above issues, we propose the open-source embodied intelligence data production platform AIRSPEED. AIRSPEED has the following features:
- Hardware-software decoupling — Reduces software costs through an open-source platform. Any device that publishes standard ROS2 messages is compatible; the data pipeline is configured entirely through YAML files without source code edits.
- Multiple devices supporting — Supports a variety of data acquisition technologies (VR controllers, cameras, robotic arms) through a uniform ROS2 topic contract, ensuring a rich variety of scenarios, tasks, and models.
- Dataset quality assurance — Boundary validation rejects malformed data (NaN/Inf) at ingest time. Post-collection format conversion (Parquet, Zarr, LeRobot v3) enables seamless integration with ML training pipelines.
- Extensible adaptor architecture — Each interface defines a topic convention. The bundled adaptors are reference implementations; new devices are added by creating a new adaptor folder following the same contract.
Architecture
AIRSPEED v1.3 consists of three interfaces and one core service:
- The Teleoperation Interface receives data from any operator input device
(VR controller, joystick, foot pedal, etc.) and publishes standardized
PoseStampedandsensor_msgs/Joymessages to ROS2 topics. - The Robot Interface converts teleoperation commands into control parameters for any robot arm and receives joint state feedback. Includes a JAX-based inverse kinematics solver and CAN bus motor control.
- The Sensor Interface receives data from any camera or environmental
sensor and publishes
Image,CameraInfo, andImumessages. - The Data Collection Service subscribes to declared ROS2 topics, validates every message against per-stream YAML contracts, and writes AIRS-standard HDF5 episode files. A post-storage conversion pipeline outputs Parquet, Zarr, or LeRobot v3 for ML training.
Each interface defines a ROS2 topic convention in its README. To add a new device, develop a ROS2 publisher that emits the declared message types on the declared topics — the bundled adaptors are reference implementations. The data collection service has no baked-in knowledge of specific hardware.
Note: The current release (v1.3) includes Teleoperation Interface, Robot Interface, Sensor Interface, and Data Collection Service. Data generation from simulation environments and automated dataset construction are planned for future releases.
Prerequisites
-
ROS2 Humble installed at
/opt/ros/humble. -
Python 3.10. ROS2 Humble’s Python bindings are compiled against the
system Python 3.10, so the run scripts must see a 3.10 interpreter. Use the
airspeedConda environment created below, or/usr/bin/python3.10.
Quick Start
git clone https://github.com/airs-cuhk/airspeed.git
cd airspeed
Environment Setup
Each sub-project has a pyproject.toml with its dependencies. Install with your
File truncated at 100 lines see the full file