 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/irvlutd/autox-semmap.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-01 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| aws_robomaker_small_house_world | 1.0.0 |
| explore_lite | 2.1.4 |
| multirobot_map_merge | 2.1.4 |
| fetch_gazebo | 0.9.2 |
| fetch_gazebo_demo | 0.9.2 |
| fetch_simulation | 0.9.2 |
| fetchit_challenge | 0.9.2 |
| fetch_calibration | 0.9.1 |
| fetch_depth_layer | 0.9.1 |
| fetch_description | 0.9.1 |
| fetch_ikfast_plugin | 0.9.1 |
| fetch_maps | 0.9.1 |
| fetch_moveit_config | 0.9.1 |
| fetch_navigation | 0.9.1 |
| fetch_ros | 0.9.1 |
| fetch_teleop | 0.9.1 |
README
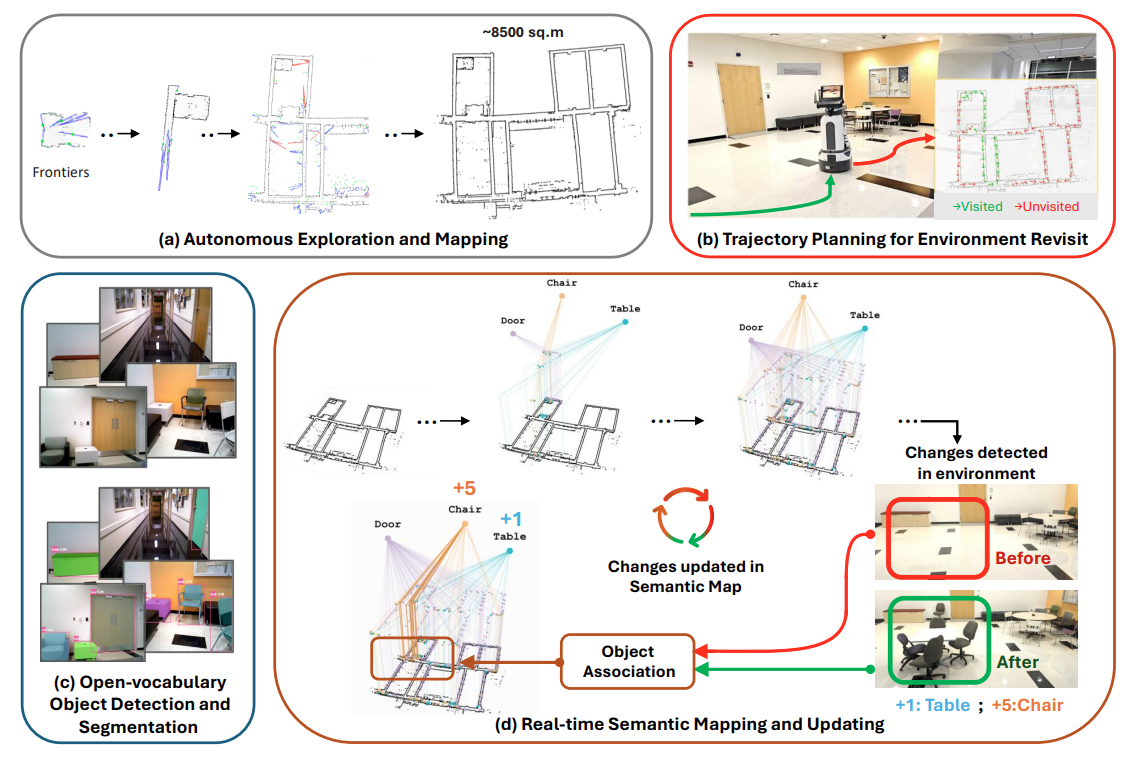
Build Once, Monitor Continuously: Persistent Semantic Mapping via Autonomous Exploration and Open-Vocabulary Object Updates
IROS 2026 WORLDS Workshop
Sai Haneesh Allu, Itay Kadosh, Tyler Summers, Yu Xiang
<div align=”center””>
| arXiv ** | ** Project WebPage ** | ** Video |
</div>
Citation
Please cite this work if it helps in your research
@misc{allu2026buildoncemonitorcontinuously,
      title={Build Once, Monitor Continuously: Persistent Semantic Mapping via Autonomous Exploration and Open-Vocabulary Object Updates},
      author={Sai Haneesh Allu and Itay Kadosh and Tyler Summers and Yu Xiang},
      year={2026},
      eprint={2409.15493},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2409.15493},
}
For any questions regarding this work, contact Sai Haneesh Allu. For any issues regarding this code, please raise an issue.
Index
- Installation
- Initialization
- Mapping and Exploration
- Environment Traversal planning
- Semantic Map Construction and Update
- Running on a real robot system
- Real World Demo
Installation
The following subsections provide detailed installation guidelines related to workspace setup, dependencies and other requirements to test this work effectively. Additionally, a docker has been provided with instructions. Credits to Iminolee.
A. Install ROS and Gazebo
This code is tested on ros noetic version. Detailed installation instructions are found here. To install ROS Noetic, execute the following commands in your terminal:
sudo sh -c 'echo "deb http://packages.ros.org/ros/ubuntu $(lsb_release -sc) main" > /etc/apt/sources.list.d/ros-latest.list'

sudo apt install -y curl

curl -s https://raw.githubusercontent.com/ros/rosdistro/master/ros.asc | sudo apt-key add -

sudo apt update

sudo apt install -y ros-noetic-desktop-full

echo "source /opt/ros/noetic/setup.bash" >> ~/.bashrc

source ~/.bashrc
For compatibility with ROS Noetic, Gazebo 11 is recommended. Detailed installation instructions are found here.
sudo sh -c 'echo "deb http://packages.osrfoundation.org/gazebo/ubuntu-stable `lsb_release -cs` main" > /etc/apt/sources.list.d/gazebo-stable.list'

wget https://packages.osrfoundation.org/gazebo.key -O - | sudo apt-key add -

sudo apt-get update

sudo apt-get install -y gazebo11
B. Create Conda Environment
We strongly recommend using a virtual environment for this work, preferably Anaconda or Miniconda. Create a new environment as follows:
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/irvlutd/autox-semmap.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-01 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| aws_robomaker_small_house_world | 1.0.0 |
| explore_lite | 2.1.4 |
| multirobot_map_merge | 2.1.4 |
| fetch_gazebo | 0.9.2 |
| fetch_gazebo_demo | 0.9.2 |
| fetch_simulation | 0.9.2 |
| fetchit_challenge | 0.9.2 |
| fetch_calibration | 0.9.1 |
| fetch_depth_layer | 0.9.1 |
| fetch_description | 0.9.1 |
| fetch_ikfast_plugin | 0.9.1 |
| fetch_maps | 0.9.1 |
| fetch_moveit_config | 0.9.1 |
| fetch_navigation | 0.9.1 |
| fetch_ros | 0.9.1 |
| fetch_teleop | 0.9.1 |
README
Build Once, Monitor Continuously: Persistent Semantic Mapping via Autonomous Exploration and Open-Vocabulary Object Updates
IROS 2026 WORLDS Workshop
Sai Haneesh Allu, Itay Kadosh, Tyler Summers, Yu Xiang
<div align=”center””>
| arXiv ** | ** Project WebPage ** | ** Video |
</div>
Citation
Please cite this work if it helps in your research
@misc{allu2026buildoncemonitorcontinuously,
      title={Build Once, Monitor Continuously: Persistent Semantic Mapping via Autonomous Exploration and Open-Vocabulary Object Updates},
      author={Sai Haneesh Allu and Itay Kadosh and Tyler Summers and Yu Xiang},
      year={2026},
      eprint={2409.15493},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2409.15493},
}
For any questions regarding this work, contact Sai Haneesh Allu. For any issues regarding this code, please raise an issue.
Index
- Installation
- Initialization
- Mapping and Exploration
- Environment Traversal planning
- Semantic Map Construction and Update
- Running on a real robot system
- Real World Demo
Installation
The following subsections provide detailed installation guidelines related to workspace setup, dependencies and other requirements to test this work effectively. Additionally, a docker has been provided with instructions. Credits to Iminolee.
A. Install ROS and Gazebo
This code is tested on ros noetic version. Detailed installation instructions are found here. To install ROS Noetic, execute the following commands in your terminal:
sudo sh -c 'echo "deb http://packages.ros.org/ros/ubuntu $(lsb_release -sc) main" > /etc/apt/sources.list.d/ros-latest.list'

sudo apt install -y curl

curl -s https://raw.githubusercontent.com/ros/rosdistro/master/ros.asc | sudo apt-key add -

sudo apt update

sudo apt install -y ros-noetic-desktop-full

echo "source /opt/ros/noetic/setup.bash" >> ~/.bashrc

source ~/.bashrc
For compatibility with ROS Noetic, Gazebo 11 is recommended. Detailed installation instructions are found here.
sudo sh -c 'echo "deb http://packages.osrfoundation.org/gazebo/ubuntu-stable `lsb_release -cs` main" > /etc/apt/sources.list.d/gazebo-stable.list'

wget https://packages.osrfoundation.org/gazebo.key -O - | sudo apt-key add -

sudo apt-get update

sudo apt-get install -y gazebo11
B. Create Conda Environment
We strongly recommend using a virtual environment for this work, preferably Anaconda or Miniconda. Create a new environment as follows:
File truncated at 100 lines see the full file