 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/nvidia-isaac-ros/isaac_ros_image_segmentation.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| isaac_ros_peoplesemseg_models_install | 5.0.0 |
| isaac_ros_segformer | 5.0.0 |
| isaac_ros_segment_anything | 5.0.0 |
| isaac_ros_segment_anything2 | 5.0.0 |
| isaac_ros_segment_anything2_interfaces | 5.0.0 |
| isaac_ros_unet | 5.0.0 |
| isaac_ros_unet_kernels | 5.0.0 |
README
Isaac ROS Image Segmentation
NVIDIA-accelerated, deep learned semantic image segmentation
Overview
Isaac ROS Image Segmentation contains ROS packages for semantic image segmentation.
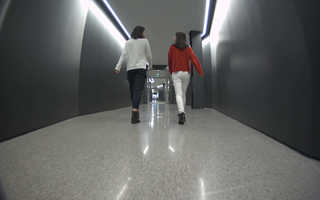
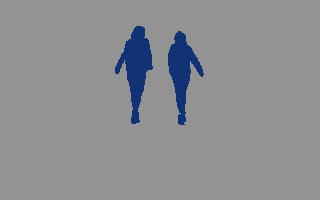
These packages provide methods for classification of an input image at the pixel level by running GPU-accelerated inference on a DNN model. Each pixel of the input image is predicted to belong to a set of defined classes. The output prediction can be used by perception functions to understand where each class is spatially in a 2D image or fuse with a corresponding depth location in a 3D scene.
| Package | Model Architecture | Description |
|---|---|---|
| Isaac ROS U-NET | U-NET | Convolutional network popular for biomedical imaging segmentation models |
| Isaac ROS Segformer | Segformer | Transformer-based network that works well for objects of varying scale |
| Isaac ROS Segment Anything | Segment Anything | Segments any object in an image when given a prompt as to which one |
| Isaac ROS Segment Anything2 | Segment Anything2 | Segments and tracks any object in a video stream when given a prompt as to which one |
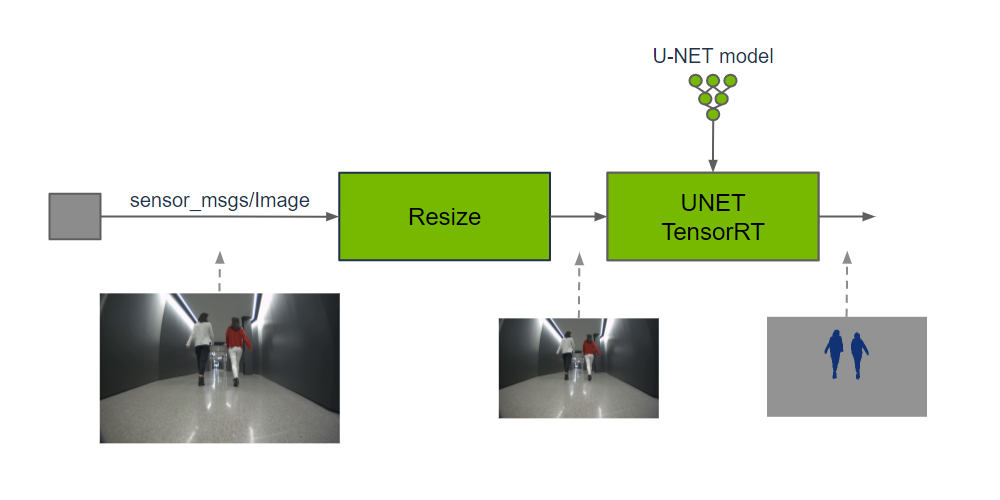
Input images may need to be cropped and resized to maintain the aspect ratio and match the input resolution expected by the DNN model; image resolution may be reduced to improve DNN inference performance, which typically scales directly with the number of pixels in the image.
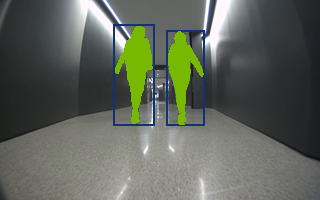
Image segmentation provides more information and uses more compute than object detection to produce classifications per pixel, whereas object detection classifies a simpler bounding box rectangle in image coordinates. Object detection is used to know if, and where spatially in a 2D image, the object exists. On the other hand, image segmentation is used to know which pixels belong to the class. One application is using the segmentation result, and fusing it with the corresponding depth information in order to know an object location in a 3D scene.
ROS 2 Native rosidl::Buffer Acceleration
This package uses rosidl::Buffer, a feature built into ROS 2 Lyrical, to
avoid unnecessary copies of large payloads between CPU and accelerator
memory. The CUDA buffer backend builds on this native ROS 2 feature to provide
CUDA memory storage and transport. Most applications can use standard ROS
messages and conversion packages without depending directly on a buffer
backend. See rosidl::Buffer and Buffer Backends for details.
Performance
| Sample Graph |
Input Size |
AGX Thor T5000 |
AGX Thor T4000 |
AGX Orin |
Orin Nano Super 8GB |
DGX Spark |
x86_64 w/ RTX 5090 |
x86_64 w/ RTX 5070 |
|---|---|---|---|---|---|---|---|---|
|
SAM Image Segmentation Graph Full SAM |
720p |
5.14 fps |
2.22 fps |
2.22 fps |
– |
2.22 fps |
25.0 fps |
8.40 fps |
|
SAM Image Segmentation Graph Mobile SAM |
720p |
20.8 fps |
14.6 fps |
8.40 fps |
4.80 fps |
14.6 fps |
109 fps 10 ms @ 30Hz |
57.9 fps 18 ms @ 30Hz |
|
TensorRT Graph PeopleSemSegNet |
544p |
478 fps 3.8 ms @ 30Hz |
352 fps 4.4 ms @ 30Hz |
315 fps 4.7 ms @ 30Hz |
156 fps 8.0 ms @ 30Hz |
298 fps 2.9 ms @ 30Hz |
1160 fps 1.1 ms @ 30Hz |
935 fps 1.6 ms @ 30Hz |
Documentation
Please visit the Isaac ROS Documentation to learn how to use this repository.
Packages
-
isaac_ros_segformer -
isaac_ros_segment_anything -
isaac_ros_segment_anything2 isaac_ros_segment_anything2_interfaces-
isaac_ros_unet
Latest
Update 2026-09-21: Migrated the image segmentation nodes from NITROS to rosidl::Buffer with the CUDA buffer backend, and fixed a per-frame GPU buffer leak in SAM2 live-camera pipelines
CONTRIBUTING
Isaac ROS Contribution Rules
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise, any Contribution intentionally submitted for inclusion in the Work by You to the Licensor shall be under the terms and conditions of this License, without any additional terms or conditions. Notwithstanding the above, nothing herein shall supersede or modify the terms of any separate license agreement you may have executed with Licensor regarding such Contributions.
Contributors must sign-off each commit by adding a Signed-off-by: ...
line to commit messages to certify that they have the right to submit
the code they are contributing to the project according to the
Developer Certificate of Origin (DCO).
Repository Summary
| Description | |
| Checkout URI | https://github.com/nvidia-isaac-ros/isaac_ros_image_segmentation.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| isaac_ros_peoplesemseg_models_install | 5.0.0 |
| isaac_ros_segformer | 5.0.0 |
| isaac_ros_segment_anything | 5.0.0 |
| isaac_ros_segment_anything2 | 5.0.0 |
| isaac_ros_segment_anything2_interfaces | 5.0.0 |
| isaac_ros_unet | 5.0.0 |
| isaac_ros_unet_kernels | 5.0.0 |
README
Isaac ROS Image Segmentation
NVIDIA-accelerated, deep learned semantic image segmentation
Overview
Isaac ROS Image Segmentation contains ROS packages for semantic image segmentation.
These packages provide methods for classification of an input image at the pixel level by running GPU-accelerated inference on a DNN model. Each pixel of the input image is predicted to belong to a set of defined classes. The output prediction can be used by perception functions to understand where each class is spatially in a 2D image or fuse with a corresponding depth location in a 3D scene.
| Package | Model Architecture | Description |
|---|---|---|
| Isaac ROS U-NET | U-NET | Convolutional network popular for biomedical imaging segmentation models |
| Isaac ROS Segformer | Segformer | Transformer-based network that works well for objects of varying scale |
| Isaac ROS Segment Anything | Segment Anything | Segments any object in an image when given a prompt as to which one |
| Isaac ROS Segment Anything2 | Segment Anything2 | Segments and tracks any object in a video stream when given a prompt as to which one |
Input images may need to be cropped and resized to maintain the aspect ratio and match the input resolution expected by the DNN model; image resolution may be reduced to improve DNN inference performance, which typically scales directly with the number of pixels in the image.
Image segmentation provides more information and uses more compute than object detection to produce classifications per pixel, whereas object detection classifies a simpler bounding box rectangle in image coordinates. Object detection is used to know if, and where spatially in a 2D image, the object exists. On the other hand, image segmentation is used to know which pixels belong to the class. One application is using the segmentation result, and fusing it with the corresponding depth information in order to know an object location in a 3D scene.
ROS 2 Native rosidl::Buffer Acceleration
This package uses rosidl::Buffer, a feature built into ROS 2 Lyrical, to
avoid unnecessary copies of large payloads between CPU and accelerator
memory. The CUDA buffer backend builds on this native ROS 2 feature to provide
CUDA memory storage and transport. Most applications can use standard ROS
messages and conversion packages without depending directly on a buffer
backend. See rosidl::Buffer and Buffer Backends for details.
Performance
| Sample Graph |
Input Size |
AGX Thor T5000 |
AGX Thor T4000 |
AGX Orin |
Orin Nano Super 8GB |
DGX Spark |
x86_64 w/ RTX 5090 |
x86_64 w/ RTX 5070 |
|---|---|---|---|---|---|---|---|---|
|
SAM Image Segmentation Graph Full SAM |
720p |
5.14 fps |
2.22 fps |
2.22 fps |
– |
2.22 fps |
25.0 fps |
8.40 fps |
|
SAM Image Segmentation Graph Mobile SAM |
720p |
20.8 fps |
14.6 fps |
8.40 fps |
4.80 fps |
14.6 fps |
109 fps 10 ms @ 30Hz |
57.9 fps 18 ms @ 30Hz |
|
TensorRT Graph PeopleSemSegNet |
544p |
478 fps 3.8 ms @ 30Hz |
352 fps 4.4 ms @ 30Hz |
315 fps 4.7 ms @ 30Hz |
156 fps 8.0 ms @ 30Hz |
298 fps 2.9 ms @ 30Hz |
1160 fps 1.1 ms @ 30Hz |
935 fps 1.6 ms @ 30Hz |
Documentation
Please visit the Isaac ROS Documentation to learn how to use this repository.
Packages
-
isaac_ros_segformer -
isaac_ros_segment_anything -
isaac_ros_segment_anything2 isaac_ros_segment_anything2_interfaces-
isaac_ros_unet
Latest
Update 2026-09-21: Migrated the image segmentation nodes from NITROS to rosidl::Buffer with the CUDA buffer backend, and fixed a per-frame GPU buffer leak in SAM2 live-camera pipelines
CONTRIBUTING
Isaac ROS Contribution Rules
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise, any Contribution intentionally submitted for inclusion in the Work by You to the Licensor shall be under the terms and conditions of this License, without any additional terms or conditions. Notwithstanding the above, nothing herein shall supersede or modify the terms of any separate license agreement you may have executed with Licensor regarding such Contributions.
Contributors must sign-off each commit by adding a Signed-off-by: ...
line to commit messages to certify that they have the right to submit
the code they are contributing to the project according to the
Developer Certificate of Origin (DCO).