 ROS Index

|
kalman_filter_localization repositorykalman_filter_localization_core kalman_filter_localization_msgs kalman_filter_localization |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/rsasaki0109/kalman_filter_localization.git |
| VCS Type | git |
| VCS Version | devel |
| Last Updated | 2026-10-24 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| kalman_filter_localization_core | 0.3.0 |
| kalman_filter_localization_msgs | 0.3.0 |
| kalman_filter_localization | 0.3.0 |
README
Kalman Filter Localization
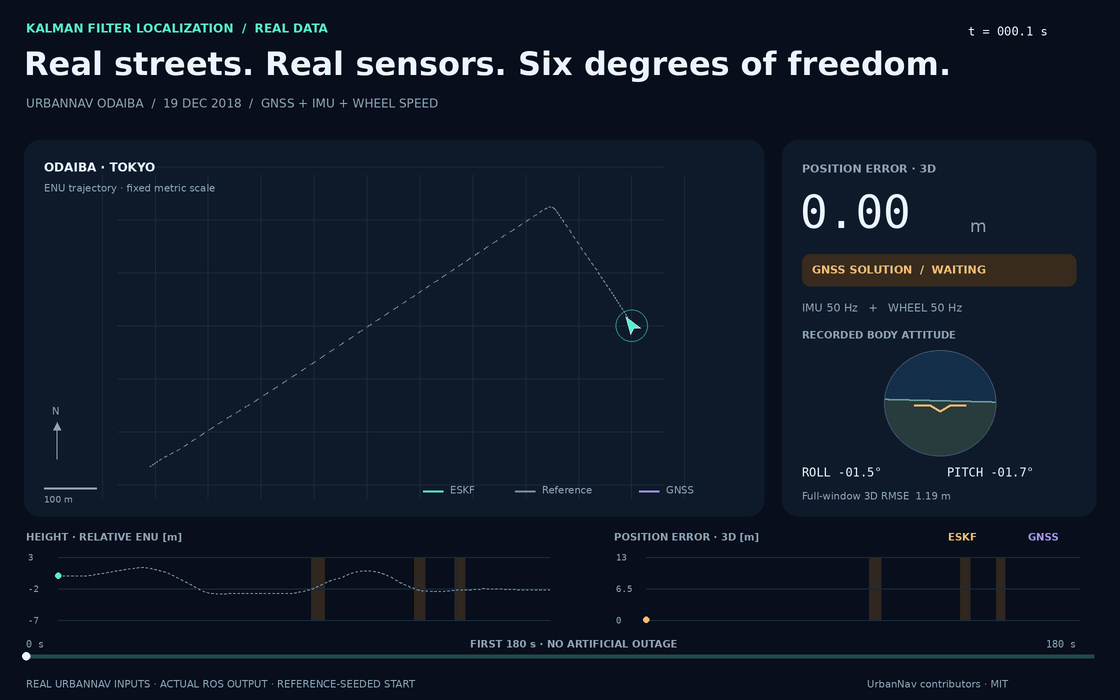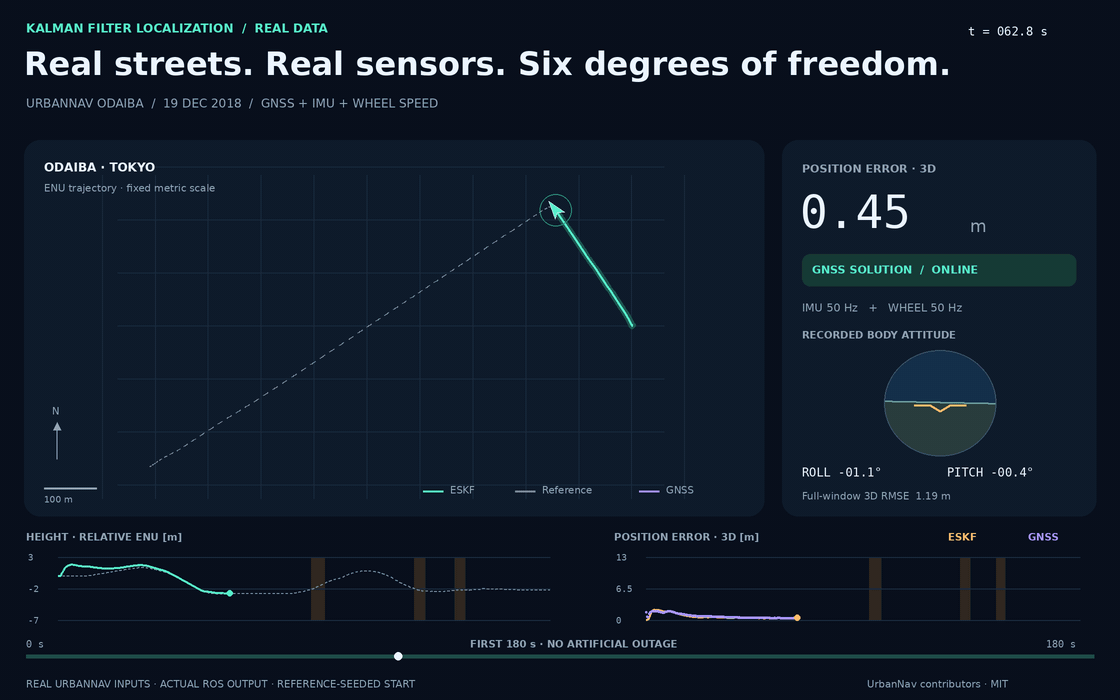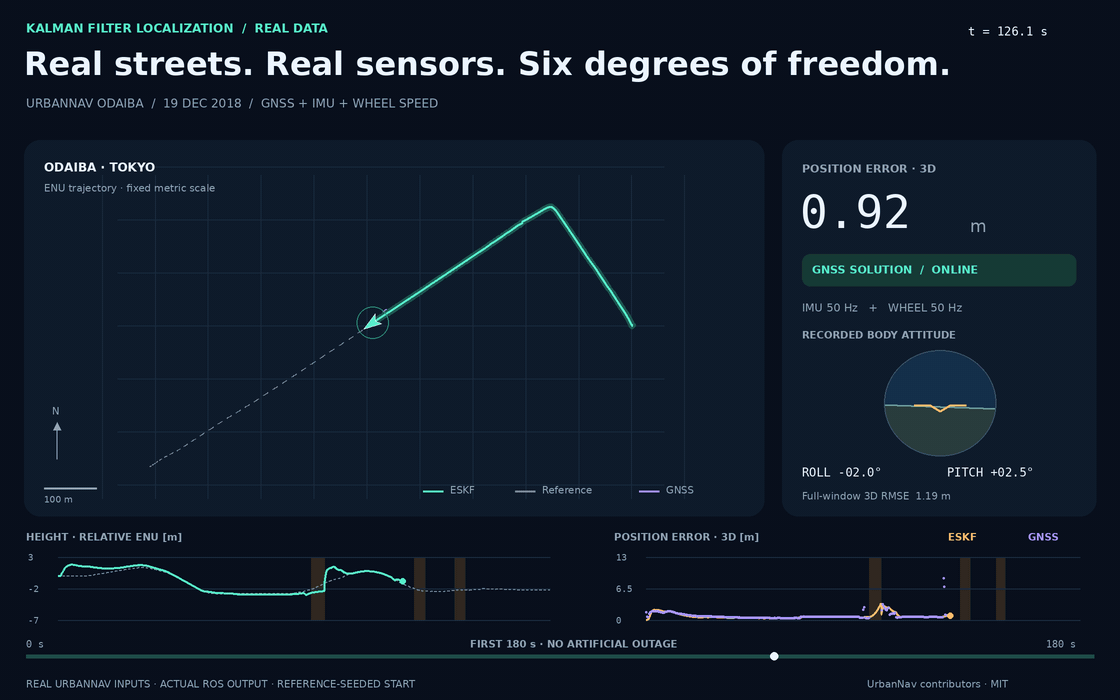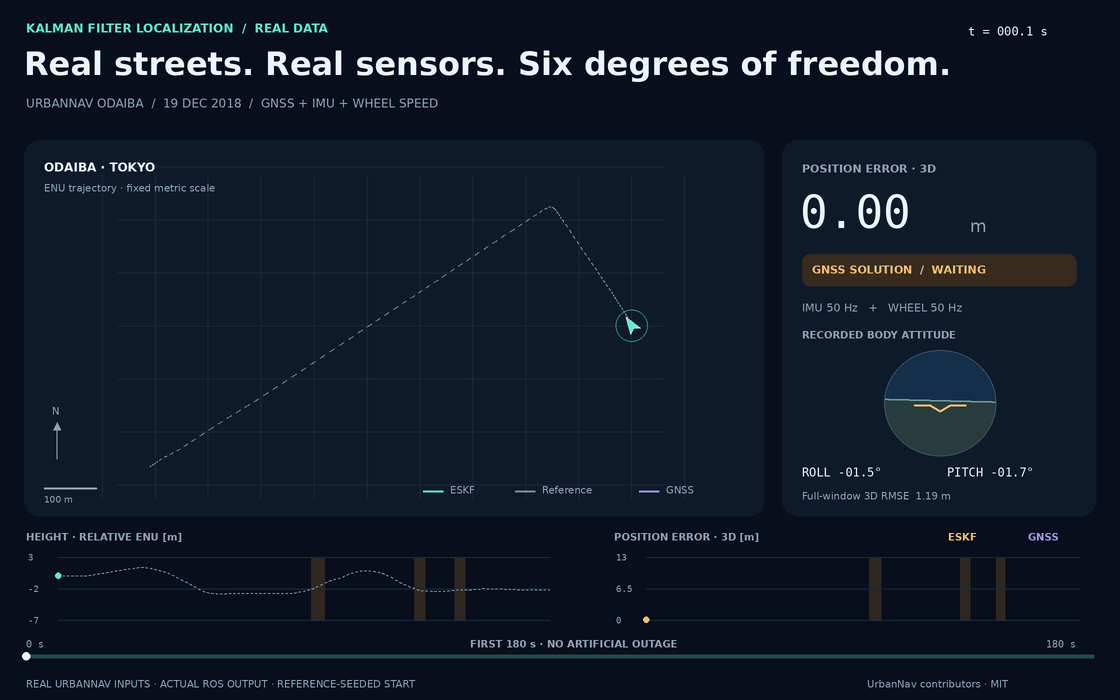
Real UrbanNav Odaiba data (MIT) · actual ROS 2 output · reference-seeded initialization. Reproduce the real-data demo · Full measured results and assumptions · Synthetic 6DoF demo
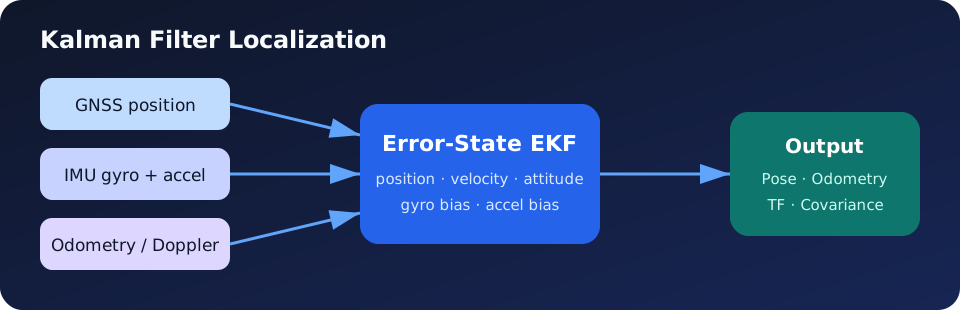
A 6DoF error-state EKF for ROS 2, fusing IMU, absolute pose and velocity observations, with GNSS and odometry input modes. It estimates position, velocity, attitude, and IMU biases.
Development target: a general 6DoF localizer for Autoware and Nav2. See the integration contracts and roadmap for current capabilities, TF ownership and remaining replacement requirements. Autoware/Nav2 launch and activation provides runnable entry points with topic/service remappings and startup instructions.
Features
- GNSS pose /
NavSatFix/ Doppler velocity - Gyroscope and accelerometer bias estimation
- GNSS NIS gating and Huber/Cauchy robust losses
- GNSS antenna lever arm and delayed-measurement rewind/replay
- Wheel speed, NHC, ZUPT, and ZIHR
- Continuous-time process noise and second-order discretization
- CSV evaluation and UrbanNav Tokyo ablation tools
Build and run
source /opt/ros/$ROS_DISTRO/setup.bash
colcon build --symlink-install
source install/setup.bash
ros2 launch kalman_filter_localization ekf.launch.py
Main topics:
| Direction | Topic | Type |
|---|---|---|
| input | /ekf_localization/initial_pose |
geometry_msgs/PoseStamped |
| input (optional, configured) | pose_measurement_topic |
geometry_msgs/PoseWithCovarianceStamped |
| input (optional, configured) | twist_measurement_topic |
geometry_msgs/TwistWithCovarianceStamped |
| input | /gnss_pose |
geometry_msgs/PoseStamped |
| input | /sensing/imu/imu_data |
sensor_msgs/Imu |
| input |
/wheel_speed (optional) |
geometry_msgs/TwistWithCovarianceStamped |
| output | /ekf_localization/current_pose |
geometry_msgs/PoseStamped |
| output | /ekf_localization/current_pose_with_covariance |
geometry_msgs/PoseWithCovarianceStamped |
| output | /ekf_localization/current_twist |
geometry_msgs/TwistStamped |
| output | /ekf_localization/current_twist_with_covariance |
geometry_msgs/TwistWithCovarianceStamped |
| output | /ekf_localization/current_odometry |
nav_msgs/Odometry |
Health and typed diagnostics are always published:
| Topic | Type | Purpose |
|---|---|---|
/ekf_localization/status |
kalman_filter_localization_msgs/EstimatorStatus |
health, mode, freshness, counters, covariance summary |
/ekf_localization/diagnostics |
diagnostic_msgs/DiagnosticArray |
standard ROS diagnostic status |
/ekf_localization/debug/measurement_quality_typed |
kalman_filter_localization_msgs/MeasurementQuality |
accepted/rejected measurement and NIS |
/ekf_localization/debug/observability_typed |
kalman_filter_localization_msgs/ObservabilityStatus |
stationary, turning/slip, NHC scale, bias learning |
/ekf_localization/debug/replay_timing_typed |
kalman_filter_localization_msgs/ReplayTiming |
sensor/arrival/filter/apply timing |
The legacy Float64MultiArray debug topics remain available when
publish_debug_topics is enabled. The typed interfaces are defined in the
separate kalman_filter_localization_msgs
package and are intended for monitoring tools and long-term API use. Detailed
field definitions and health-state transitions are in
docs/diagnostics.md.
An optional joint 6DoF pose input preserves correlated position/attitude covariance, transforms reference frames at the sensor timestamp, and supports delayed replay and six-dimensional NIS gating. The linear Twist input adds correlated 3D velocity observations with sensor-origin transport and replay. Pose freshness is monitored independently of IMU arrival. Twist axes can be selected for forward-speed-only inputs. See initialization and reset for full correlated initial covariance and the reset service.
See ekf.yaml for the default
parameters and param/profiles for
dataset-specific configurations.
Configuration diagnosis
Run kf_doctor before tuning a new bag. It discovers common GNSS/IMU/wheel/odometry
topics, checks sensor timestamps, frame IDs, covariance validity, IMU rate and
stationary-window statistics, then writes a machine-readable report and a
conservative profile skeleton:
ros2 run kalman_filter_localization kf_doctor \
  --bag input_bag \
  --output-report .data/doctor/report.json \
  --output-profile .data/doctor/profile.yaml
Fixed-lag smoothing oracle
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the BSD license 2.0, as dictated by that license.
|
|
kalman_filter_localization repositorykalman_filter_localization_core kalman_filter_localization_msgs kalman_filter_localization |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/rsasaki0109/kalman_filter_localization.git |
| VCS Type | git |
| VCS Version | devel |
| Last Updated | 2026-10-24 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| kalman_filter_localization_core | 0.3.0 |
| kalman_filter_localization_msgs | 0.3.0 |
| kalman_filter_localization | 0.3.0 |
README
Kalman Filter Localization
Real UrbanNav Odaiba data (MIT) · actual ROS 2 output · reference-seeded initialization. Reproduce the real-data demo · Full measured results and assumptions · Synthetic 6DoF demo
A 6DoF error-state EKF for ROS 2, fusing IMU, absolute pose and velocity observations, with GNSS and odometry input modes. It estimates position, velocity, attitude, and IMU biases.
Development target: a general 6DoF localizer for Autoware and Nav2. See the integration contracts and roadmap for current capabilities, TF ownership and remaining replacement requirements. Autoware/Nav2 launch and activation provides runnable entry points with topic/service remappings and startup instructions.
Features
- GNSS pose /
NavSatFix/ Doppler velocity - Gyroscope and accelerometer bias estimation
- GNSS NIS gating and Huber/Cauchy robust losses
- GNSS antenna lever arm and delayed-measurement rewind/replay
- Wheel speed, NHC, ZUPT, and ZIHR
- Continuous-time process noise and second-order discretization
- CSV evaluation and UrbanNav Tokyo ablation tools
Build and run
source /opt/ros/$ROS_DISTRO/setup.bash
colcon build --symlink-install
source install/setup.bash
ros2 launch kalman_filter_localization ekf.launch.py
Main topics:
| Direction | Topic | Type |
|---|---|---|
| input | /ekf_localization/initial_pose |
geometry_msgs/PoseStamped |
| input (optional, configured) | pose_measurement_topic |
geometry_msgs/PoseWithCovarianceStamped |
| input (optional, configured) | twist_measurement_topic |
geometry_msgs/TwistWithCovarianceStamped |
| input | /gnss_pose |
geometry_msgs/PoseStamped |
| input | /sensing/imu/imu_data |
sensor_msgs/Imu |
| input |
/wheel_speed (optional) |
geometry_msgs/TwistWithCovarianceStamped |
| output | /ekf_localization/current_pose |
geometry_msgs/PoseStamped |
| output | /ekf_localization/current_pose_with_covariance |
geometry_msgs/PoseWithCovarianceStamped |
| output | /ekf_localization/current_twist |
geometry_msgs/TwistStamped |
| output | /ekf_localization/current_twist_with_covariance |
geometry_msgs/TwistWithCovarianceStamped |
| output | /ekf_localization/current_odometry |
nav_msgs/Odometry |
Health and typed diagnostics are always published:
| Topic | Type | Purpose |
|---|---|---|
/ekf_localization/status |
kalman_filter_localization_msgs/EstimatorStatus |
health, mode, freshness, counters, covariance summary |
/ekf_localization/diagnostics |
diagnostic_msgs/DiagnosticArray |
standard ROS diagnostic status |
/ekf_localization/debug/measurement_quality_typed |
kalman_filter_localization_msgs/MeasurementQuality |
accepted/rejected measurement and NIS |
/ekf_localization/debug/observability_typed |
kalman_filter_localization_msgs/ObservabilityStatus |
stationary, turning/slip, NHC scale, bias learning |
/ekf_localization/debug/replay_timing_typed |
kalman_filter_localization_msgs/ReplayTiming |
sensor/arrival/filter/apply timing |
The legacy Float64MultiArray debug topics remain available when
publish_debug_topics is enabled. The typed interfaces are defined in the
separate kalman_filter_localization_msgs
package and are intended for monitoring tools and long-term API use. Detailed
field definitions and health-state transitions are in
docs/diagnostics.md.
An optional joint 6DoF pose input preserves correlated position/attitude covariance, transforms reference frames at the sensor timestamp, and supports delayed replay and six-dimensional NIS gating. The linear Twist input adds correlated 3D velocity observations with sensor-origin transport and replay. Pose freshness is monitored independently of IMU arrival. Twist axes can be selected for forward-speed-only inputs. See initialization and reset for full correlated initial covariance and the reset service.
See ekf.yaml for the default
parameters and param/profiles for
dataset-specific configurations.
Configuration diagnosis
Run kf_doctor before tuning a new bag. It discovers common GNSS/IMU/wheel/odometry
topics, checks sensor timestamps, frame IDs, covariance validity, IMU rate and
stationary-window statistics, then writes a machine-readable report and a
conservative profile skeleton:
ros2 run kalman_filter_localization kf_doctor \
  --bag input_bag \
  --output-report .data/doctor/report.json \
  --output-profile .data/doctor/profile.yaml
Fixed-lag smoothing oracle
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the BSD license 2.0, as dictated by that license.