 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA


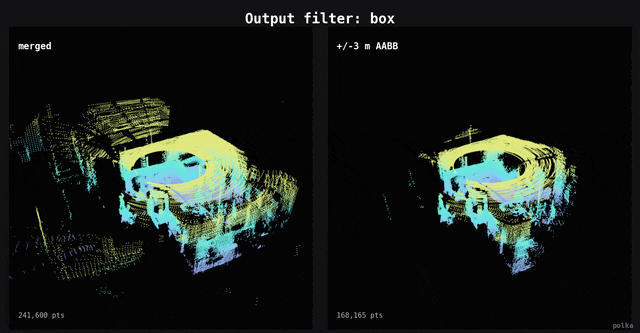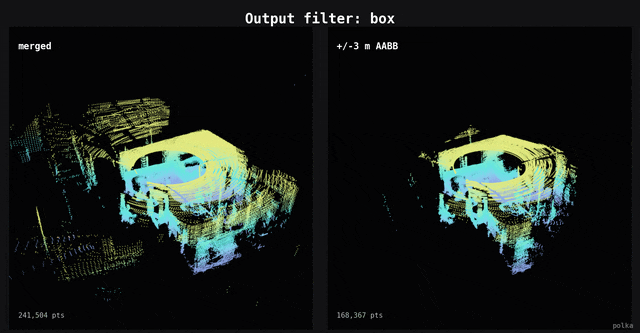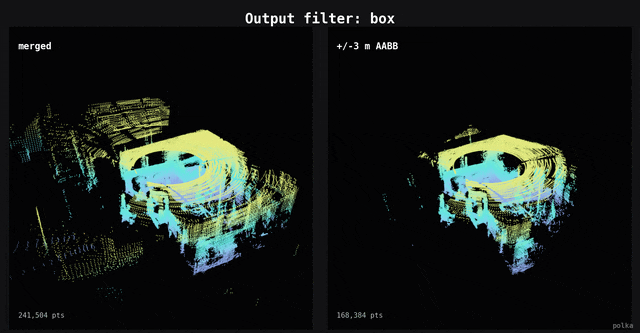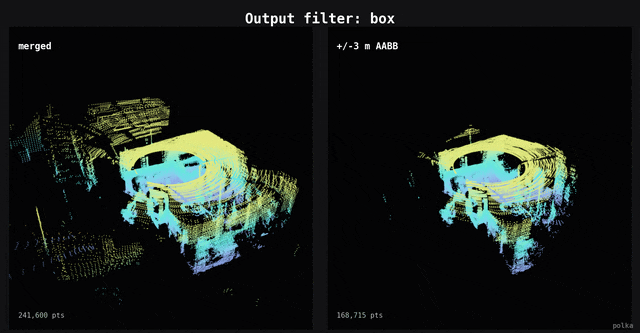
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | kilted |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | lyrical |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/Pana1v/polka.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-23 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| polka | 0.6.1 |
README
POLKA
Multi-LiDAR fusion node for ROS 2. Merges any mix of PointCloud2 and LaserScan sources into one cloud, one scan, or both, with per-source and output filters, IMU/odometry deskew, and CUDA when an NVIDIA GPU is present. It replaces a relay, filter, transform, merge and downsample chain.
Documentation: polka-ros.github.io
Install
From apt, with CUDA built in (amd64; needs only the NVIDIA driver, falls back to CPU without a GPU):
sudo curl -fsSL https://polka-ros.github.io/polka.gpg -o /usr/share/keyrings/polka.gpg
echo "deb [arch=amd64 signed-by=/usr/share/keyrings/polka.gpg] https://polka-ros.github.io $(. /etc/os-release && echo $VERSION_CODENAME) main" \
  | sudo tee /etc/apt/sources.list.d/polka.list
sudo apt update && sudo apt install ros-${ROS_DISTRO:?source your ROS setup.bash first}-polka
From source, using the branch named after your distro:
git clone -b humble https://github.com/Pana1v/polka.git ~/ros2_ws/src/polka
cd ~/ros2_ws && colcon build --packages-select polka   # CUDA engine is built when nvcc is found
Driver versions, distro branches and details: Install.
Quick start
cp config/example_params.yaml config/my_robot.yaml   # set your topics and output_frame_id
ros2 launch polka polka.launch.py config_file:=config/my_robot.yaml
Then see Configuration.
License
Apache-2.0. The per-point deskew model is inspired by rko_lio (arXiv:2509.06593). Maintainers: MAINTAINING.md.