 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README


ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
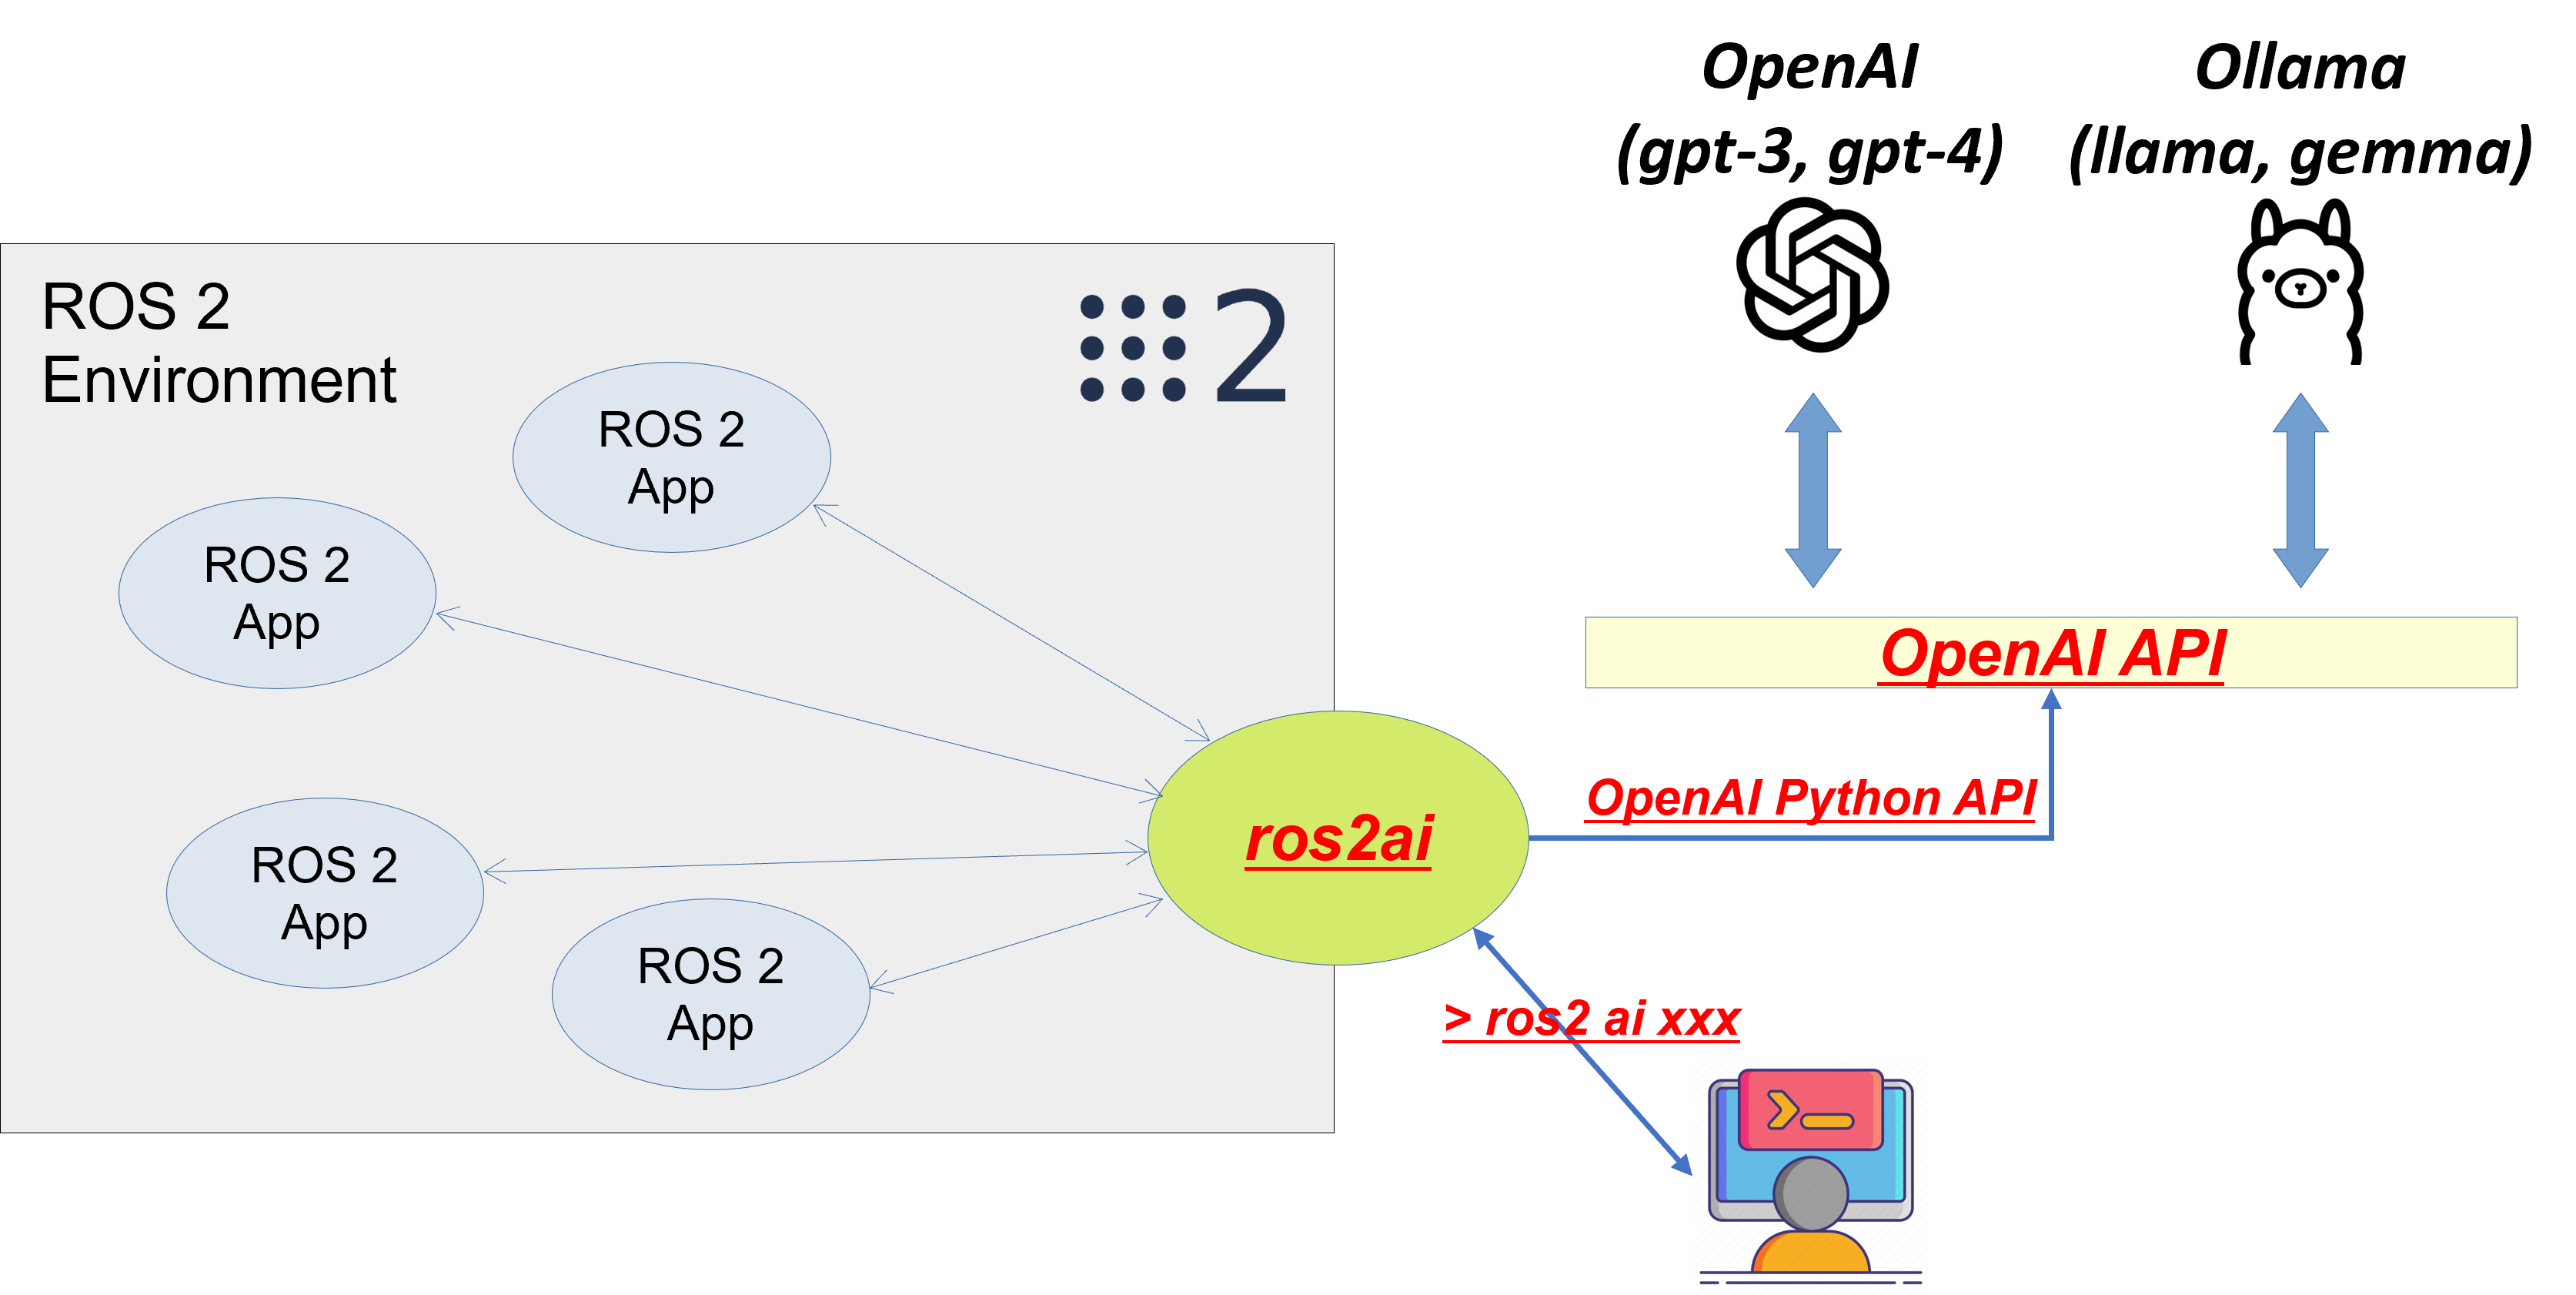
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥

(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.
Repository Summary
| Description | |
| Checkout URI | https://github.com/fujitatomoya/ros2ai.git |
| VCS Type | git |
| VCS Version | rolling |
| Last Updated | 2026-11-12 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| ros2ai | 1.0.0 |
README
ros2ai 🤖
ros2ai is a next-generation ROS 2 command line interface extension with OpenAI, Anthropic and Ollama.
see overview slide deck for more information.
Motivation
- (Just for fun 😝)
- Thin wrapper for ros2cli and ros2documentation.
- Getting answers against the questions directly without browsing, clicking and typing many times.
- Easy to use for everyone, especially for ROS 2 beginners and students who do not really know ros2cli.
- Multiple language support.
- Multiple LLMs support (with OpenAI Python API, any OpenAI compatible endpoint such as Anthropic and Ollama)
Demo 🖥️
See how it works 🔥
(Full quality video: ros2ai_demo.mp4)
Supported ROS Distribution
| Distribution | Supported | Note |
|---|---|---|
| Rolling Ridley | ✅ | Development / Mainstream Branch |
| Lyrical Luth | ✅ | |
| Kilted Kaiju | ✅ | |
| Jazzy Jalisco | ✅ | |
| Humble Hawksbill | ✅ |
Installation
Binary
ros2ai is released for every supported distribution, replace <distro> with rolling, lyrical, kilted, jazzy or humble.
apt install ros-<distro>-ros2ai
Docker Container
see available images for tomoyafujita/ros2ai@dockerhub
docker run -it --rm --net=host -e ROS2AI_API_KEY=$ROS2AI_API_KEY -e ROS2AI_ENDPOINT=$ROS2AI_ENDPOINT -e ROS2AI_MODEL_NAME=$ROS2AI_MODEL_NAME tomoyafujita/ros2ai:rolling
[!NOTE]
ROS2AI_API_KEYenvironmental variable is not required if using Ollama. And it is expecting that Ollama runs on the host system mostly, so that container is bound to the host network interface.
Required Package
-
rolling/lyrical/kilted/jazzy
pip install openai validators --break-system-packages --ignore-installed
[!NOTE] see PEP 668 – Marking Python base environments as “externally managed” why
--break-system-packagesis required.
humble
pip install openai validators --ignore-installed
Build
To use the latest development version, build it in the colcon workspace.
source /opt/ros/rolling/setup.bash
mkdir -p colcon_ws/src
cd colcon_ws/src
git clone https://github.com/fujitatomoya/ros2ai.git
cd ..
colcon build --symlink-install --packages-select ros2ai
Usage
Prerequisites
As described in overview diagram, ros2ai uses only OpenAI Python API but backend implementation can be replaced with any LLM service that provides the compatible API with OpenAI, such as Anthropic and Ollama.
User need to choose which of them is used by ros2ai as following configuration, otherwise it falls back to use OpenAI.
-
ros2airequires OpenAI API key
File truncated at 100 lines see the full file
CONTRIBUTING
Any contribution that you make to this repository will be under the Apache 2 License, as dictated by that license:
5. Submission of Contributions. Unless You explicitly state otherwise,
   any Contribution intentionally submitted for inclusion in the Work
   by You to the Licensor shall be under the terms and conditions of
   this License, without any additional terms or conditions.
   Notwithstanding the above, nothing herein shall supersede or modify
   the terms of any separate license agreement you may have executed
   with Licensor regarding such Contributions.