 ROS Index

|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
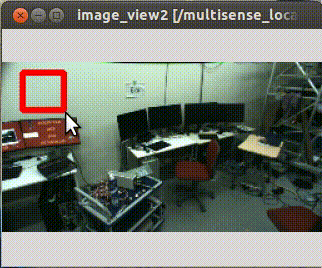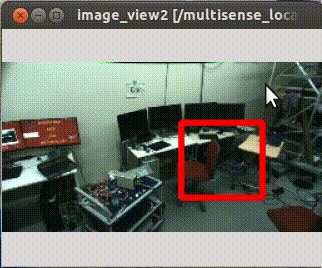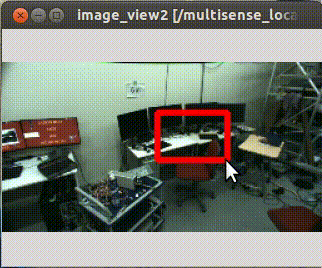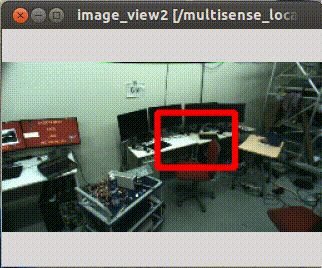
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
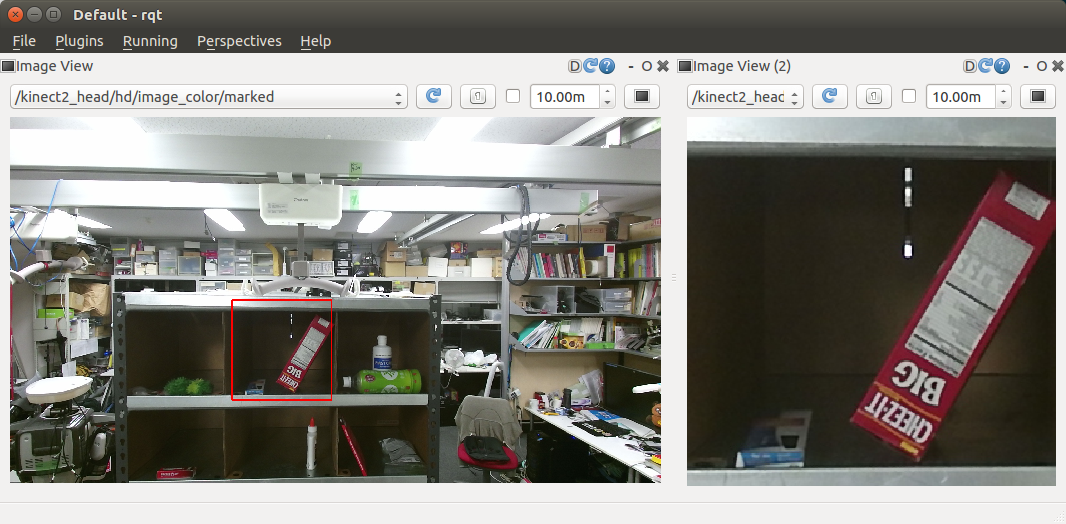
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
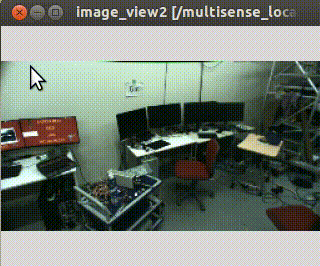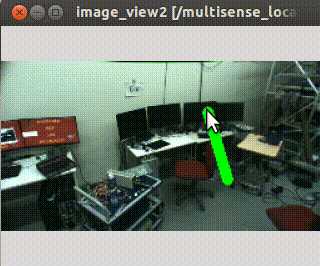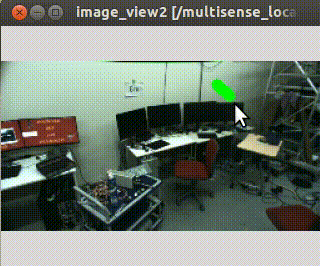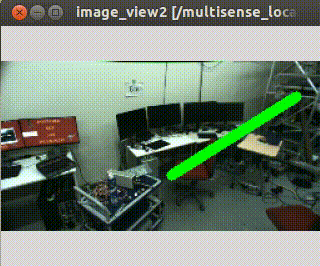
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
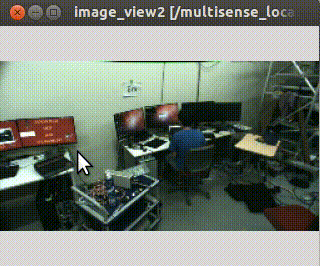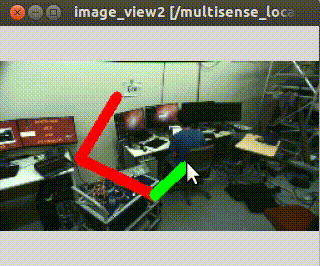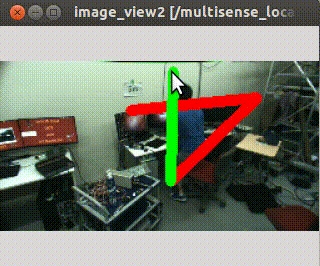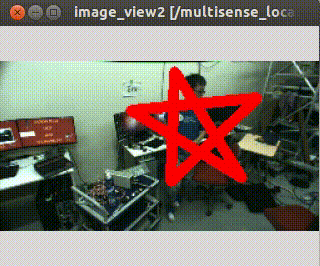
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
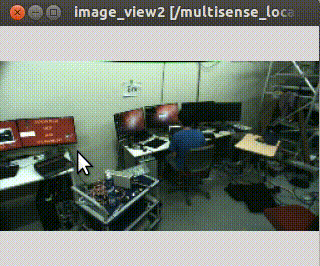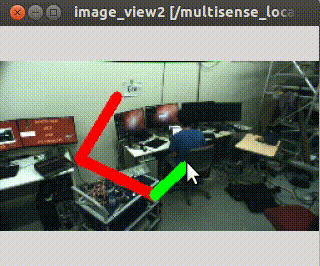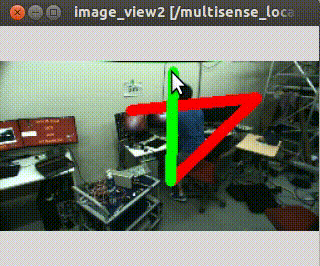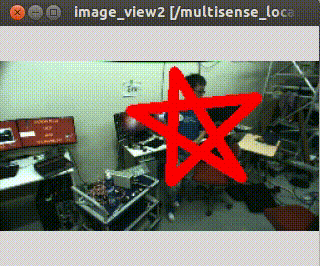
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.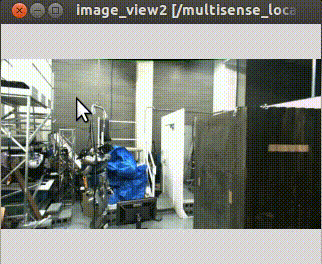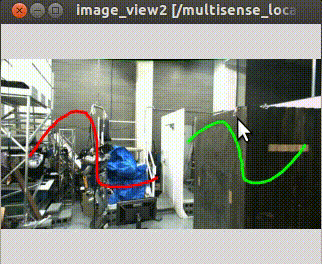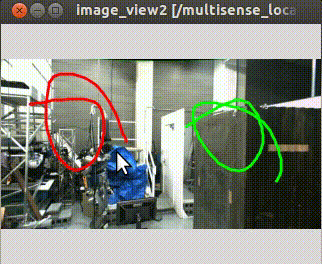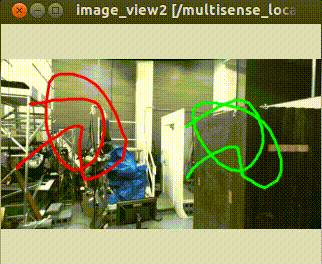
The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.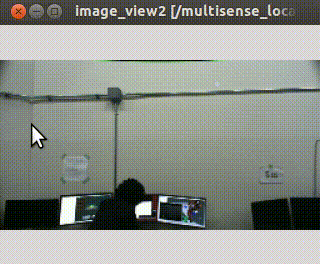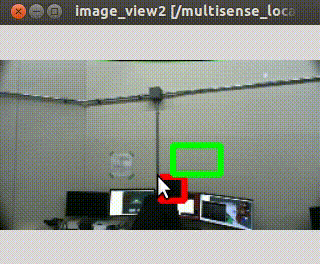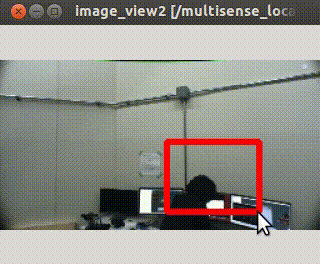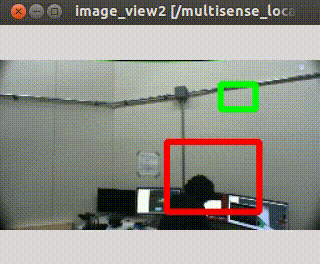
The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
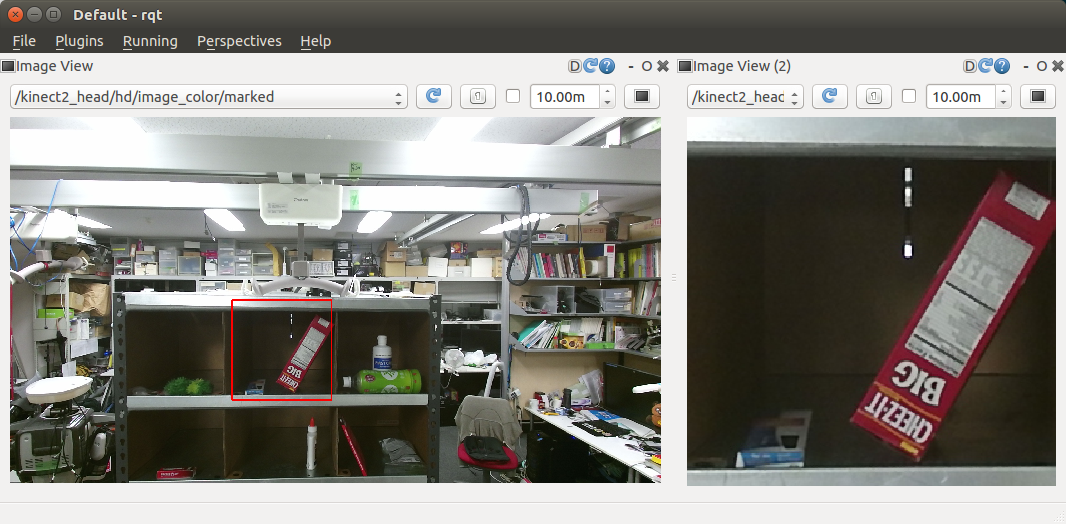
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
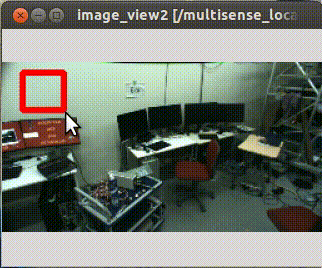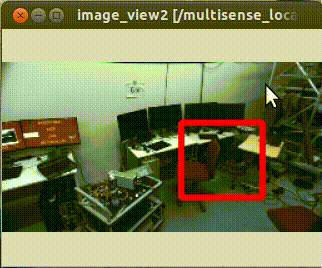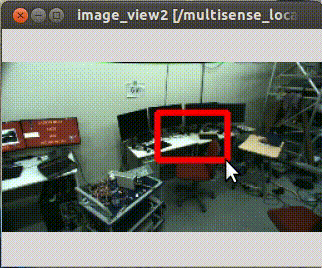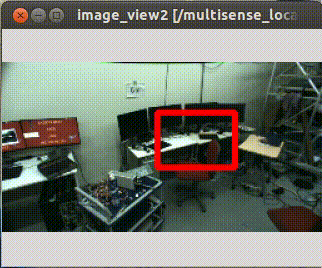
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
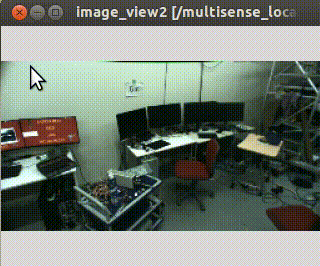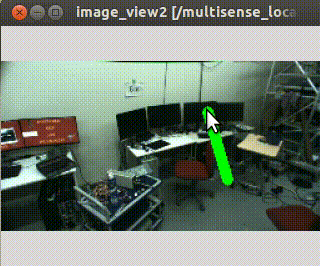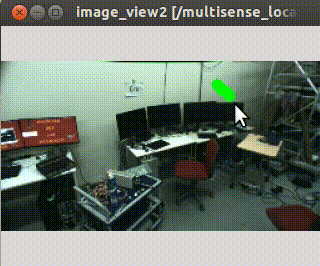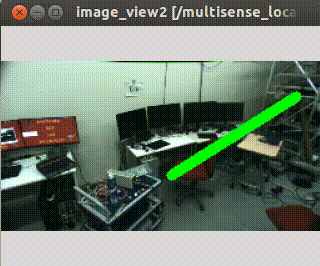
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.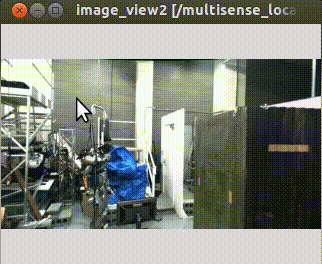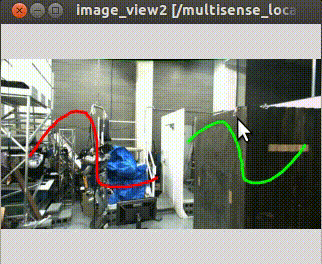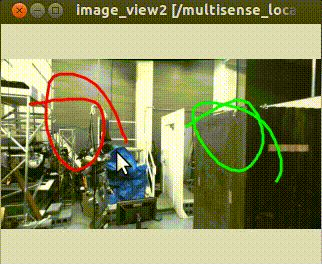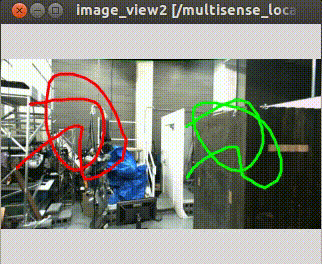
The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.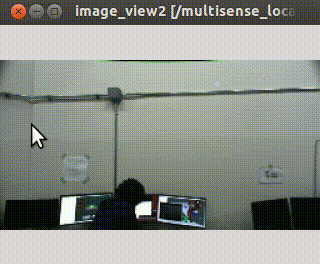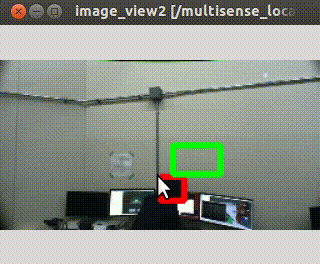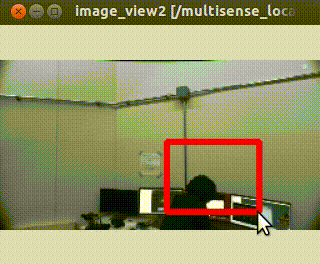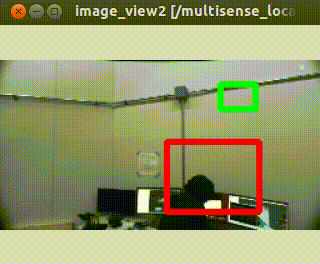
The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | 3.0.5 |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_common |
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch
Messages
Services
Plugins
Recent questions tagged image_view2 at Robotics Stack Exchange
|
|
image_view2 package from jsk_common repoaudio_video_recorder jsk_common dynamic_tf_publisher jsk_data jsk_ros1_ros2_compat image_view2 jsk_rosbag_tools jsk_tools jsk_topic_tools |
ROS Distro
|
Package Summary
| Version | 3.0.5 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_common.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-10 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
image_view2
image_view2 is an extended image_view.
Features
- Draw markers on image view
- Interact with user direction
Interaction Modes
image_view2 support several mode to interact with user.
You can set interaction mode by ~interaction_mode parameter or
change mode by service interfaces.
-
Rectangle mode (
~interaction_mode:=rectangle)In rectangle mode, user can select region-of-interest by dragging mouse pointer.
Selected regions are published to
image/screenrectangle(geometry_msgs/PolygonStamped) topic.If user clicks on the view instead of dragging pointer, clicked position is published to
image/screenpoint(geometry_msgs/PointStamped) topic. -
Line mode (
~interaction_mode:=line)In line mode, user can select a line by dragging mouse pointer.
Selected line are published to
image/line(geometry_msgs/PolygonStamped) topic. -
Polygon mode (
~interaction_mode:=poly)In polygon mode, user can select a series of closed lines. User can add line by left-click and close the lines by right-click.
Selected polygon are published to
image/poly(geometry_msgs/PolygonStamped) topic. -
Grabcut mode (
~interaction_mode:=grabcut)In grabcut mode, user can select two curves. By typing
Esckey, you can clear selected curves.The selected first red curve is published to
image/foreground(sensor_msgs/Image) and the second green one is publiehd toimage/background(sensor_msgs/Image). This mode is originally implemented to select forground and background pixels for grabcut. -
Grabcut Rectangle mode (
~interaction_mode:=grabcut_rect)In grabcut rectangle mode, user can select two rectangles. By typing
Esckey, you can clear selected rectangles.The selected first red rectangle is published to
image/foreground_rect(geometry_msgs/PolygonStamped) and the second green one is publiehd toimage/background_rect(geometry_msgs/PolygonStamped). This mode is originally implemented to select forground and background regions for grabcut.
ROS API
Publising Topics
-
image/marked(sensor_msgs/Image)Image with marks drawed.
-
image/screenrectangle_image(sensor_msgs/Image)Cropped image with user selection at Rectangle mode.
Subscribing Topics
-
image(sensor_msgs/Image)Input image
-
camera_info(sensor_msgs/CameraInfo)CameraInfo of the image. camera info is required to compute projection matrix when drawing markers.
-
image_marker(image_view2/ImageMarker2)Marker topic.
-
image/event(image_view2/MouseEvent)Event interface. image_view2 can handle mouse events without gui interaction. This topic is used to emulate event handling via ros topics
File truncated at 100 lines see the full file
Changelog for package image_view2
3.0.5 (2026-11-10)
- Merge pull request #1841 from k-okada/rosdistro-55117-review rosdistro#55117 review: add LICENSE to each package, use SPDX license identifiers
- Merge pull request #1840 from k-okada/rhel-ambiguous-shebang Fix RHEL rpm build (ambiguous python shebang) of image_view2 and uv venv
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and "Apache License 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55117 review: "BSD is ambiguous. The headers show the 3-clause variant, so BSD-3-Clause (SPDX) is preferred."). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- add LICENSE to each package (BSD-3-Clause, jsk_tools: Apache-2.0) The ROS2 release review of jsk_common in ros/rosdistro#55117 says (https://github.com/ros/rosdistro/pull/55117#issuecomment-6757665510): > - [ ] At least one of the following must be present > - [ ] Top level license file: None. There is no LICENSE/COPYING at > the repo root (tree @ cbbd0ab). > - [ ] Per package license files: None. No package directory has a > license file. The license text only appears in source-file headers > (e.g. deprecated_relay.h#L1-L33, BSD-3-Clause, "JSK Lab"). Since jsk_tools is Apache-2.0 and the others are BSD-3-Clause, add a license file to each package instead of one at the top level. The BSD ones use the same text as the source headers, "Copyright (c) <year>-, JSK Lab" where <year> is when the package.xml was added, and jsk_tools has the Apache License 2.0 text from apache.org. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- image_view2: do not install ROS1 test scripts on ROS2 (RHEL ambiguous shebang) test/publish_*.py have a "#!/usr/bin/env python" shebang and are installed executable, which makes brp-mangle-shebangs fail the RHEL rpm build. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.4 (2026-11-04)
- Merge pull request #1838 from k-okada/no-ament-target-dependencies Fix ROS2 buildfarm binary jobs of 3.0.3: lyrical (ament_target_dependencies, message_filters), jsk_rosbag_tools samples/
- [image_view2, audio_video_recorder] build on lyrical: no ament_target_dependencies, message_filters *.hpp The lyrical binary jobs fail with "Unknown CMake command ament_target_dependencies": ament_cmake 2.8 (lyrical) dropped it. Link the exported targets with target_link_libraries() instead; pcl_conversions (before lyrical) and jsk_ros1_ros2_compat export include directories only, so add their *_INCLUDE_DIRS. lyrical's message_filters also has *.hpp headers only, so audio_video_recorder includes those on ROS2 (jazzy has both). Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.3 (2026-11-03)
-
Merge pull request #1835 from k-okada/ros-version-fallback-ament Fix ROS2 buildfarm binary jobs: ROS_VERSION without ros_environment, boost for jsk_topic_tools
-
Guess ROS_VERSION from AMENT_PREFIX_PATH when unset, depend on ros_environment The ROS2 binary jobs of the buildfarm failed at find_package(catkin): they install only the build dependencies, none of which pulls in ros_environment, so $ENV{ROS_VERSION} is empty and the fallback at the top of CMakeLists.txt chose ROS1.
- package.xml: add a ROS2 buildtool_depend on ros_environment, which sets ROS_VERSION.
- CMakeLists.txt: when ROS_VERSION is still unset, guess it from AMENT_PREFIX_PATH (bloom's ROS2 debian/rules passes it to cmake, setup.sh and colcon set the environment variable, catkin never does) instead of always assuming ROS1, and warn about it. jsk_tools had no fallback at all and gets the same block. Applies to jsk_ros1_ros2_compat, jsk_tools, jsk_topic_tools, jsk_common, jsk_data, jsk_rosbag_tools, dynamic_tf_publisher, audio_video_recorder and image_view2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge pull request #1833 from k-okada/release-3.0.2 3.0.2
-
Contributors: Kei Okada
3.0.2 (2026-11-02)
3.0.0 (2026-10-29)
-
Merge pull request #1826 from k-okada/ros2-support Add ROS2 support to jsk_ros1_ros2_compat, dynamic_tf_publisher, jsk_topic_tools, jsk_tools, audio_video_recorder, jsk_data, image_view2, jsk_rosbag_tools
-
[image_view2] add ROS2 support
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- sample/sample_rectangle_mouse_event.launch
-
- gui [default: true]
- test/rectangle_mouse_event.launch