 ROS Index

|
depth_anything_v2_ros2 package from depth_anything_v2_ros2 repodepth_anything_v2_ros2 |
ROS Distro
|
Package Summary
| Version | 1.1.0 |
| License | Apache-2.0 |
| Build type | AMENT_PYTHON |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/grupo-avispa/depth_anything_v2_ros2.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-07-27 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Óscar Pons Fernández
Authors
- Óscar Pons Fernández
depth_anything_v2_ros2



Overview
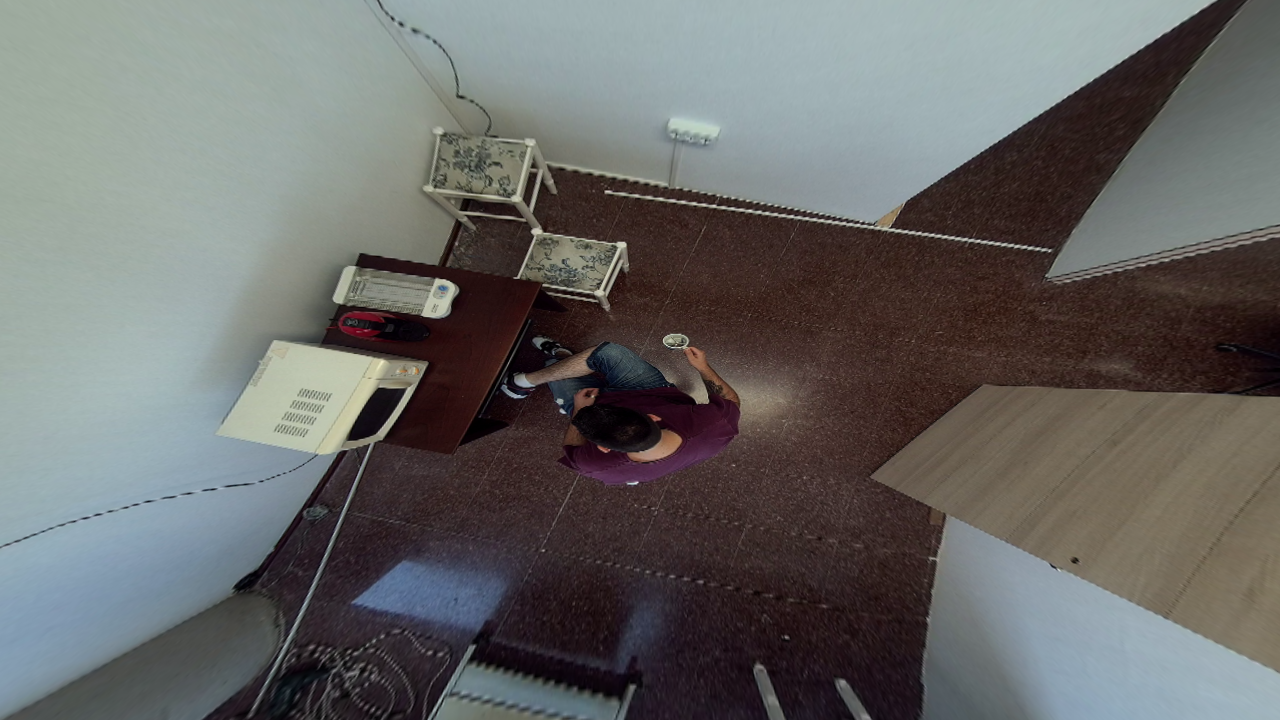
This package is a ROS2 wrapper for the depth_anything_v2 library. It provides a ROS2 node that subscribes to a camera topic and publishes the depth map of the scene.
| RGB | Depth |
|---|---|
 |
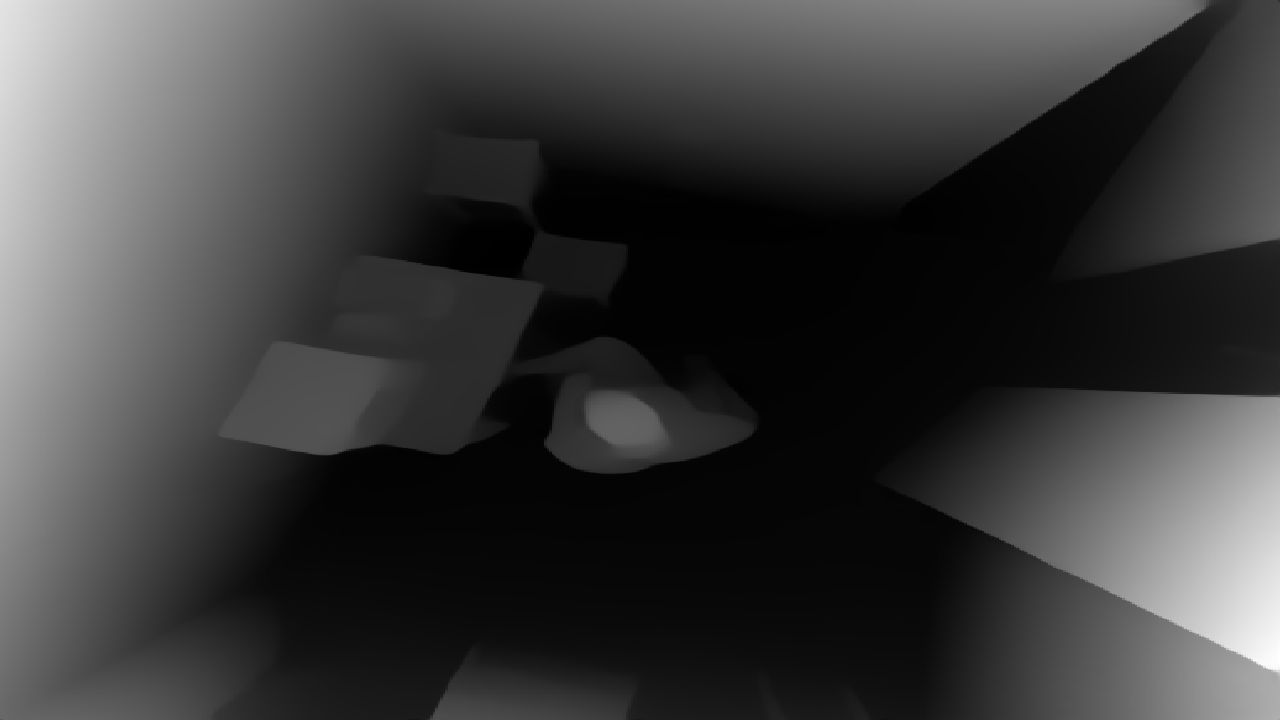 |
The depth_anything_v2_ros2 package has been tested under [ROS2] jazzy on [Ubuntu] 22.04. This is research code, expect that it changes often and any fitness for a particular purpose is disclaimed.
Installation
Building from Source
Dependencies
- Robot Operating System (ROS) 2 (middleware for robotics),
- depth_anything_v2 (library for depth estimation),
- torch (deep learning framework),
- nav2_common (used by the launch file to rewrite the parameters YAML).
torch, torchvision, opencv-python and numpy are installed via pip (see Building); the rest are regular ROS 2 dependencies resolved by rosdep.
Building
To build from source, clone the latest version from the main repository into your colcon workspace and install the python dependencies by running the following commands:
cd colcon_workspace/src
git clone --recurse-submodules https://github.com/grupo-avispa/depth_anything_v2_ros2.git -b main
pip3 install -r requirements.txt
Before building, make sure to download the depth_anything_v2 model weights and place them in the models directory.
[!IMPORTANT] This node uses the metric depth model (
depth_anything_v2.metric_depth), so you must download a metric checkpoint, not a relative one. A relative checkpoint loaded into the metric architecture produces mis-scaled, non-metric depth (objects appear too far away and bounding boxes become oversized). For indoor scenes use the Hypersim model; for outdoor scenes use the VKITTI model.
You can download the metric checkpoints here. For example, the indoor (Hypersim) small model:
cd colcon_workspace/src/depth_anything_v2_ros2/models
wget https://huggingface.co/depth-anything/Depth-Anything-V2-Metric-Hypersim-Small/resolve/main/depth_anything_v2_metric_hypersim_vits.pth
Remember to set max_depth to the value the checkpoint was trained with (20 m for Hypersim/indoor, 80 m for VKITTI/outdoor).
Then, install the ROS2 dependencies using rosdep and build the package using:
cd colcon_workspace
rosdep install -i --from-path src --rosdistro jazzy -y
colcon build --symlink-install
Updating the depth_anything_v2 submodule
The depth_anything_v2 submodule is pinned to a fixed commit (there are no upstream tags/releases to pin to instead), so git submodule update always checks out that exact commit and builds stay reproducible. To deliberately move to a newer upstream commit:
cd colcon_workspace/src/depth_anything_v2_ros2/depth_anything_v2
git fetch
git checkout <new-commit-sha>
cd ..
git add depth_anything_v2
git commit -m "build: update depth_anything_v2 submodule to <new-commit-sha>"
Rebuild and re-run the test suite afterwards, since upstream changes to dpt.py or the dinov2 backbone can break the DepthEstimator import.
Usage
With some RGB image source running, run the depth_anything_v2_ros2 node with:
ros2 launch depth_anything_v2_ros2 default.launch.py
depth_anything is a managed (lifecycle) node. With the default autostart:=true launch argument it configures (loads the model) and activates (creates the topics) itself on startup. To drive it manually instead, launch with autostart:=false and use:
ros2 lifecycle set /depth_anything configure
ros2 lifecycle set /depth_anything activate
A failed configure (e.g. an invalid encoder or a missing model_file) is reported as a clean lifecycle transition failure instead of crashing the process.
Nodes
depth_anything
This is a managed (lifecycle) node. It subscribes to a camera topic and publishes the depth map of the scene, alongside the matching CameraInfo so downstream nodes (e.g. depth_image_proc for point clouds) can pair both topics.
Subscribed Topics
-
camera/color/image_raw([sensor_msgs/Image])The RGB image topic.
-
camera/color/camera_info([sensor_msgs/CameraInfo])Camera info matching
image_topic, republished alongside the depth image.
Published Topics
-
depth([sensor_msgs/Image])
File truncated at 100 lines see the full file
CHANGELOG
All notable changes to the depth_anything_v2_ros2 project will be documented in this file.
[1.1.0] - 25-07-2026
Added
- Added
depth_anything_v2_ros2/depth_estimator.pywith the pure depth estimation domain logic, extracted out of the ROS node so it can be unit tested without rclpy, a GPU or a checkpoint file:-
select_encoder_config()maps an encoder name to itsDepthAnythingV2architecture kwargs and raisesValueErroron an unsupported value. -
resolve_device()falls back to CPU when CUDA is requested but unavailable. -
postprocess_depth()clips a raw depth prediction to[0, max_depth]and casts it tofloat32. -
DepthEstimatorloads the model (raisingFileNotFoundError/ValueErroron a missing checkpoint or invalid encoder) and runs inference.
-
- Added
test/test_depth_estimator.pywith 8 pytest cases coveringselect_encoder_config(),resolve_device()andpostprocess_depth(). - Migrated
DepthAnythingROSfromrclpy.node.Nodetorclpy.lifecycle.LifecycleNode: the model is now loaded inon_configure(returningTransitionCallbackReturn.FAILUREon an invalid encoder or missing checkpoint instead of crashing with an opaqueAttributeError), and the subscribers/publishers are created inon_activateand torn down inon_deactivate/on_cleanup. - Added an
autostartlaunch argument (defaulttrue) inlaunch/default.launch.py, passed to thelaunch_ros.actions.LifecycleNodeaction so it configures and activatesdepth_anythingright after startup. - Added
camera_info_topic/depth_camera_info_topicparameters: the node now republishes the inputCameraInfoalongside the depth image (timestamped with the image header), so downstream nodes such asdepth_image_proccan pair both topics to build a point cloud. - Added a
MutuallyExclusiveCallbackGroupforimage_callbackand switchedmain()to aMultiThreadedExecutor, so a heavy inference no longer blocks lifecycle transitions and other callbacks. - Documented the
depth_anything_v2submodule update procedure inREADME.md.
Changed
-
package.xml: addedpython3-numpy,python3-opencvandnav2_common(already used by the launch file, previously undeclared) asexec_depend. -
requirements.txt: removedgradio,gradio_imagesliderandhuggingface_hub(unused, pulled in from the upstream Gradio demo). -
.github/workflows/build.yml: removedskip-tests: truesoament_flake8,ament_pep257,ament_copyrightand the new pytest suite actually run in CI. -
torch.load()now usesweights_only=Trueand validates thatmodel_fileexists before loading, instead of deserializing an unrestricted pickle and failing with a low-level traceback on a missing file. -
max_depthis now validated to be strictly positive inget_params(). - Extracted the repeated declare/get/log parameter pattern into a
_declare()helper. - Fixed the
image_callbackdocstring (it described "detections", copied from an unrelated node) and the misleading "Invert depth valies" comment. - Replaced
print(e)withself.get_logger().error(...)in theCvBridgeErrorhandler for the outgoing publish, so failures show up in the ROS logs. - Removed the duplicated
start_time = time.time()call and the unnecessaryself.current_imageinstance attribute (now a local variable). - Removed trailing whitespace flagged by
ament_flake8(W293).
[1.0.0] - previous releases
See the git history prior to this file for changes up to the metric depth support.
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged depth_anything_v2_ros2 at Robotics Stack Exchange
|
|
depth_anything_v2_ros2 package from depth_anything_v2_ros2 repodepth_anything_v2_ros2 |
ROS Distro
|
Package Summary
| Version | 1.1.0 |
| License | Apache-2.0 |
| Build type | AMENT_PYTHON |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/grupo-avispa/depth_anything_v2_ros2.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-07-27 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Óscar Pons Fernández
Authors
- Óscar Pons Fernández
depth_anything_v2_ros2
Overview
This package is a ROS2 wrapper for the depth_anything_v2 library. It provides a ROS2 node that subscribes to a camera topic and publishes the depth map of the scene.
| RGB | Depth |
|---|---|
|
|
The depth_anything_v2_ros2 package has been tested under [ROS2] jazzy on [Ubuntu] 22.04. This is research code, expect that it changes often and any fitness for a particular purpose is disclaimed.
Installation
Building from Source
Dependencies
- Robot Operating System (ROS) 2 (middleware for robotics),
- depth_anything_v2 (library for depth estimation),
- torch (deep learning framework),
- nav2_common (used by the launch file to rewrite the parameters YAML).
torch, torchvision, opencv-python and numpy are installed via pip (see Building); the rest are regular ROS 2 dependencies resolved by rosdep.
Building
To build from source, clone the latest version from the main repository into your colcon workspace and install the python dependencies by running the following commands:
cd colcon_workspace/src
git clone --recurse-submodules https://github.com/grupo-avispa/depth_anything_v2_ros2.git -b main
pip3 install -r requirements.txt
Before building, make sure to download the depth_anything_v2 model weights and place them in the models directory.
[!IMPORTANT] This node uses the metric depth model (
depth_anything_v2.metric_depth), so you must download a metric checkpoint, not a relative one. A relative checkpoint loaded into the metric architecture produces mis-scaled, non-metric depth (objects appear too far away and bounding boxes become oversized). For indoor scenes use the Hypersim model; for outdoor scenes use the VKITTI model.
You can download the metric checkpoints here. For example, the indoor (Hypersim) small model:
cd colcon_workspace/src/depth_anything_v2_ros2/models
wget https://huggingface.co/depth-anything/Depth-Anything-V2-Metric-Hypersim-Small/resolve/main/depth_anything_v2_metric_hypersim_vits.pth
Remember to set max_depth to the value the checkpoint was trained with (20 m for Hypersim/indoor, 80 m for VKITTI/outdoor).
Then, install the ROS2 dependencies using rosdep and build the package using:
cd colcon_workspace
rosdep install -i --from-path src --rosdistro jazzy -y
colcon build --symlink-install
Updating the depth_anything_v2 submodule
The depth_anything_v2 submodule is pinned to a fixed commit (there are no upstream tags/releases to pin to instead), so git submodule update always checks out that exact commit and builds stay reproducible. To deliberately move to a newer upstream commit:
cd colcon_workspace/src/depth_anything_v2_ros2/depth_anything_v2
git fetch
git checkout <new-commit-sha>
cd ..
git add depth_anything_v2
git commit -m "build: update depth_anything_v2 submodule to <new-commit-sha>"
Rebuild and re-run the test suite afterwards, since upstream changes to dpt.py or the dinov2 backbone can break the DepthEstimator import.
Usage
With some RGB image source running, run the depth_anything_v2_ros2 node with:
ros2 launch depth_anything_v2_ros2 default.launch.py
depth_anything is a managed (lifecycle) node. With the default autostart:=true launch argument it configures (loads the model) and activates (creates the topics) itself on startup. To drive it manually instead, launch with autostart:=false and use:
ros2 lifecycle set /depth_anything configure
ros2 lifecycle set /depth_anything activate
A failed configure (e.g. an invalid encoder or a missing model_file) is reported as a clean lifecycle transition failure instead of crashing the process.
Nodes
depth_anything
This is a managed (lifecycle) node. It subscribes to a camera topic and publishes the depth map of the scene, alongside the matching CameraInfo so downstream nodes (e.g. depth_image_proc for point clouds) can pair both topics.
Subscribed Topics
-
camera/color/image_raw([sensor_msgs/Image])The RGB image topic.
-
camera/color/camera_info([sensor_msgs/CameraInfo])Camera info matching
image_topic, republished alongside the depth image.
Published Topics
-
depth([sensor_msgs/Image])
File truncated at 100 lines see the full file
CHANGELOG
All notable changes to the depth_anything_v2_ros2 project will be documented in this file.
[1.1.0] - 25-07-2026
Added
- Added
depth_anything_v2_ros2/depth_estimator.pywith the pure depth estimation domain logic, extracted out of the ROS node so it can be unit tested without rclpy, a GPU or a checkpoint file:-
select_encoder_config()maps an encoder name to itsDepthAnythingV2architecture kwargs and raisesValueErroron an unsupported value. -
resolve_device()falls back to CPU when CUDA is requested but unavailable. -
postprocess_depth()clips a raw depth prediction to[0, max_depth]and casts it tofloat32. -
DepthEstimatorloads the model (raisingFileNotFoundError/ValueErroron a missing checkpoint or invalid encoder) and runs inference.
-
- Added
test/test_depth_estimator.pywith 8 pytest cases coveringselect_encoder_config(),resolve_device()andpostprocess_depth(). - Migrated
DepthAnythingROSfromrclpy.node.Nodetorclpy.lifecycle.LifecycleNode: the model is now loaded inon_configure(returningTransitionCallbackReturn.FAILUREon an invalid encoder or missing checkpoint instead of crashing with an opaqueAttributeError), and the subscribers/publishers are created inon_activateand torn down inon_deactivate/on_cleanup. - Added an
autostartlaunch argument (defaulttrue) inlaunch/default.launch.py, passed to thelaunch_ros.actions.LifecycleNodeaction so it configures and activatesdepth_anythingright after startup. - Added
camera_info_topic/depth_camera_info_topicparameters: the node now republishes the inputCameraInfoalongside the depth image (timestamped with the image header), so downstream nodes such asdepth_image_proccan pair both topics to build a point cloud. - Added a
MutuallyExclusiveCallbackGroupforimage_callbackand switchedmain()to aMultiThreadedExecutor, so a heavy inference no longer blocks lifecycle transitions and other callbacks. - Documented the
depth_anything_v2submodule update procedure inREADME.md.
Changed
-
package.xml: addedpython3-numpy,python3-opencvandnav2_common(already used by the launch file, previously undeclared) asexec_depend. -
requirements.txt: removedgradio,gradio_imagesliderandhuggingface_hub(unused, pulled in from the upstream Gradio demo). -
.github/workflows/build.yml: removedskip-tests: truesoament_flake8,ament_pep257,ament_copyrightand the new pytest suite actually run in CI. -
torch.load()now usesweights_only=Trueand validates thatmodel_fileexists before loading, instead of deserializing an unrestricted pickle and failing with a low-level traceback on a missing file. -
max_depthis now validated to be strictly positive inget_params(). - Extracted the repeated declare/get/log parameter pattern into a
_declare()helper. - Fixed the
image_callbackdocstring (it described "detections", copied from an unrelated node) and the misleading "Invert depth valies" comment. - Replaced
print(e)withself.get_logger().error(...)in theCvBridgeErrorhandler for the outgoing publish, so failures show up in the ROS logs. - Removed the duplicated
start_time = time.time()call and the unnecessaryself.current_imageinstance attribute (now a local variable). - Removed trailing whitespace flagged by
ament_flake8(W293).
[1.0.0] - previous releases
See the git history prior to this file for changes up to the metric depth support.