 ROS Index

Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
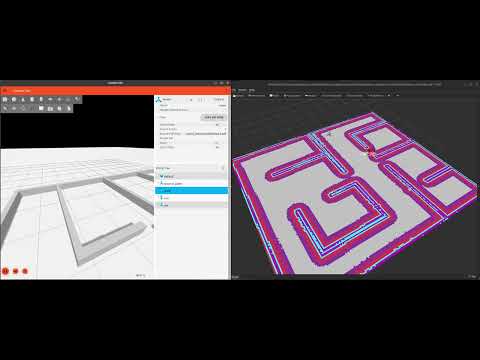
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | kilted |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | lyrical |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Francisco Martín Rico
EasyNav Omni Playground
EasyNav configuration for three- to six-wheel omnidirectional robots in Gazebo Harmonic. The default launch starts the 3w_v2 robot in maze2, together with EasyNav and RViz2.
Demo
The omni playground is made of three packages:
| Package | Contents |
|---|---|
easynav_playground_omni_description |
The robots’ models: URDF, meshes and ros2_control controllers. No Gazebo, no EasyNav |
easynav_playground_omni_worlds |
The Gazebo simulation: two mazes and their maps, the kinematics node, and the launcher that spawns the chosen robot with its controllers and the ROS–Gazebo bridge. No EasyNav |
easynav_playground_omni |
The EasyNav configuration and launcher |
Supported ROS 2 distributions
This playground needs Gazebo Harmonic or newer, so it runs on Jazzy and later distributions, but not on Humble, whose Gazebo is Fortress. EasyNav itself (core and plugins) does run on Humble: only this simulation does not.
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni
source install/setup.bash
Launch EasyNav
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml
The world launch argument selects both the Gazebo world and its matching EasyNav map. The available options are maze1 and maze2 (default):
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze1
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml world:=maze2
Other launch arguments, params_file, rviz_config, map_override_file and robot, can also be overridden.
The robot argument chooses the robot (3w, 3w_v2, 4w, 5w, 6w; see easynav_playground_omni_description), for example:
ros2 launch easynav_playground_omni easynav_navigation_gazebo_sim.launch.yaml robot:=5w world:=maze1
All robot models share EasyNav limits of 0.6 m/s linear and 0.5 rad/s angular velocity.
Package layout
| Directory | Contents |
|---|---|
launch/ |
EasyNav launch file, in YAML |
params/ |
EasyNav parameters, and the map of each world (map_overrides/<world>/map.yaml) |
rviz/ |
RViz2 configuration |
Authors and licensing
This package was developed by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos), and is licensed under Apache-2.0; see LICENSE. The simulator it uses is Yohan Prakoso’s: see easynav_playground_omni_worlds and easynav_playground_omni_description.
Changelog for package easynav_playground_omni
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: EasyNav launchers and parameters for the three- to six-wheel omnidirectional robots: a costmap with RPP configuration
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez