 ROS Index

Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
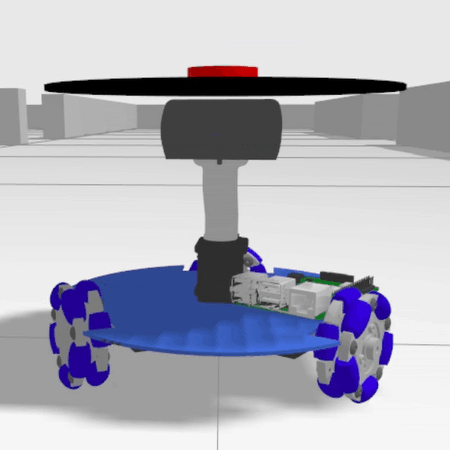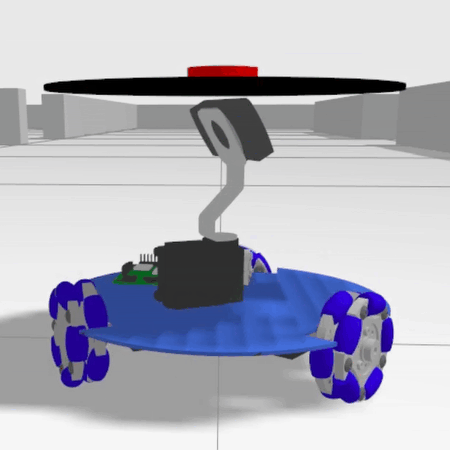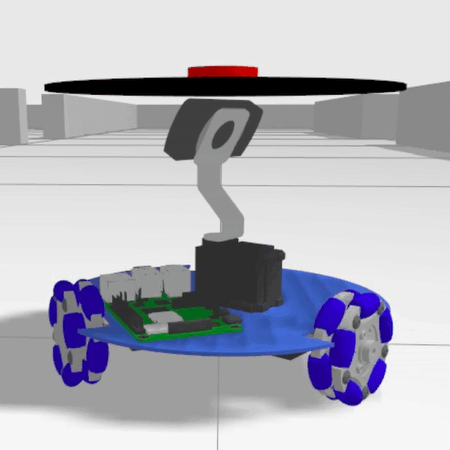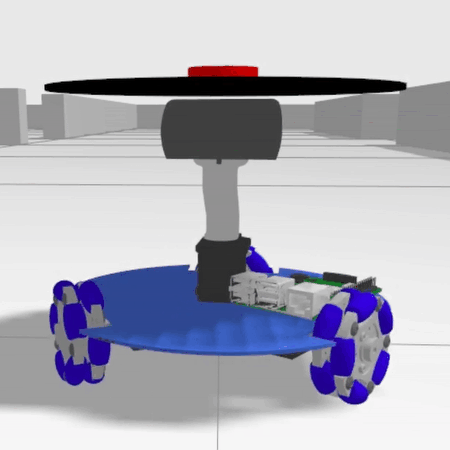
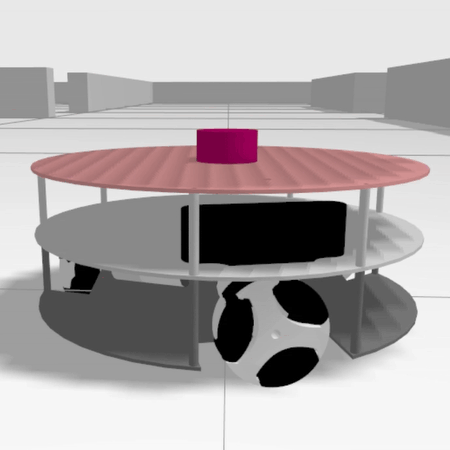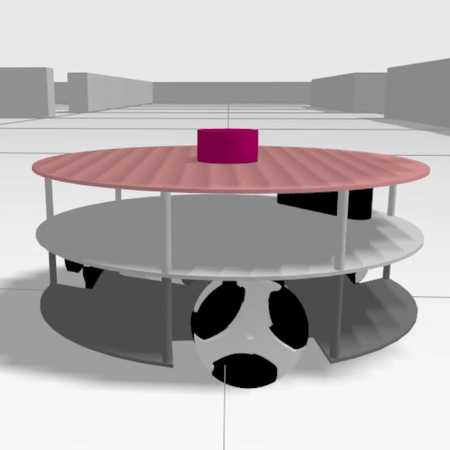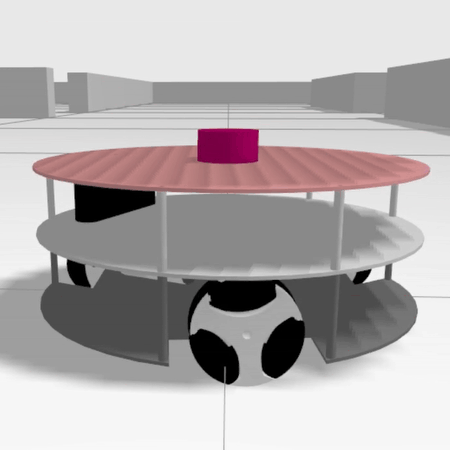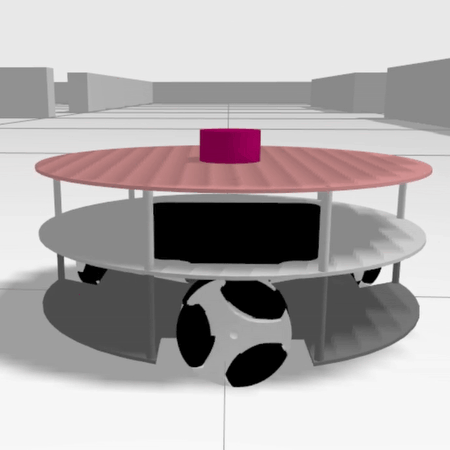
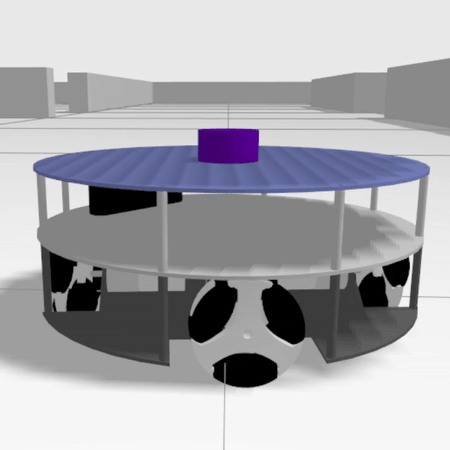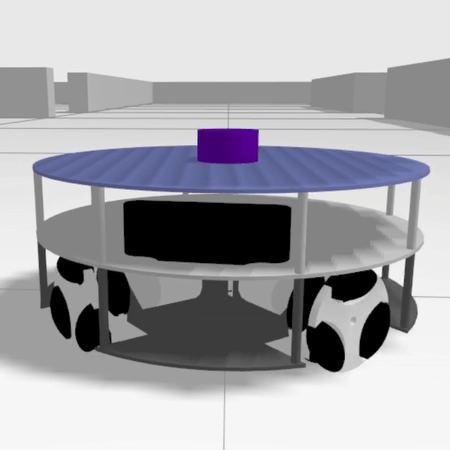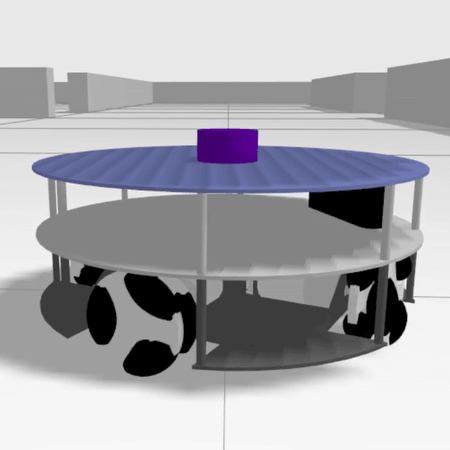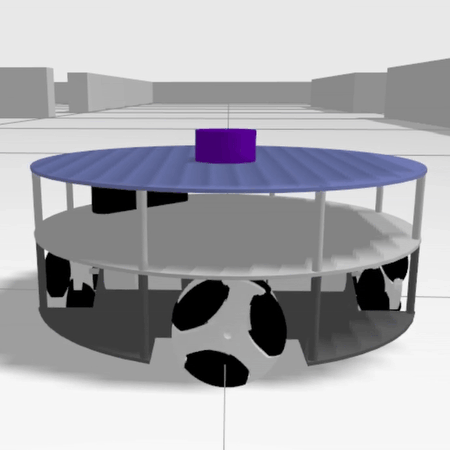
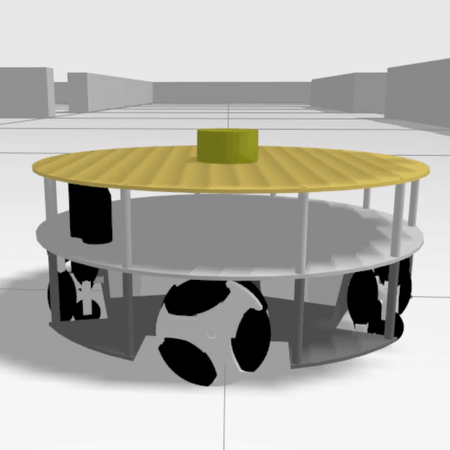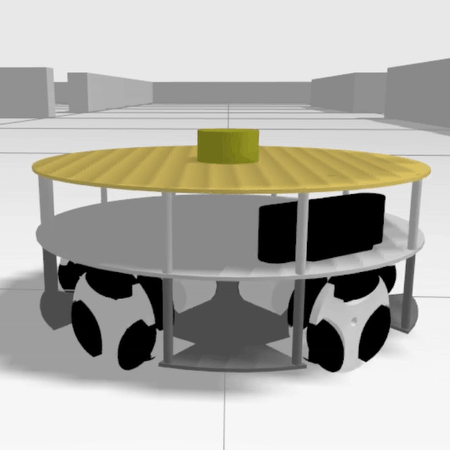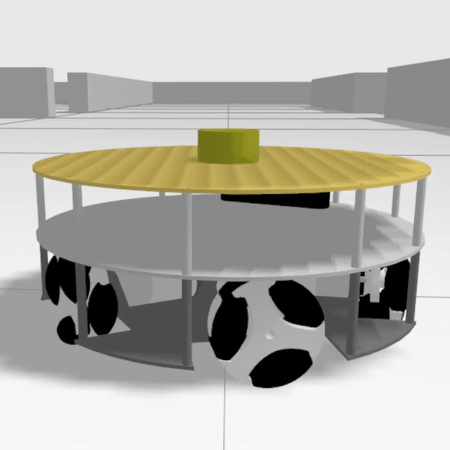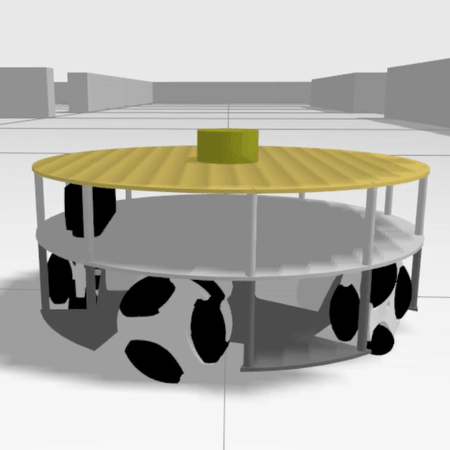
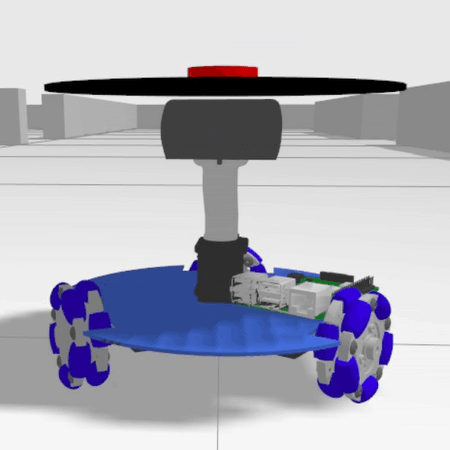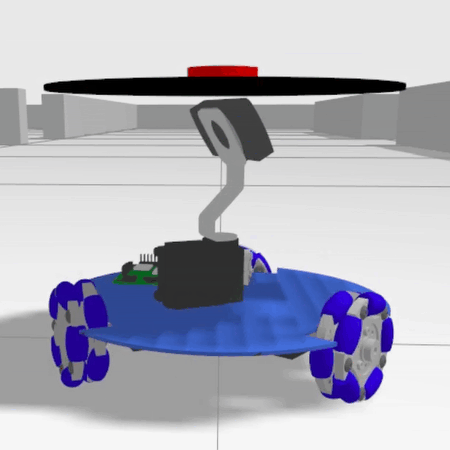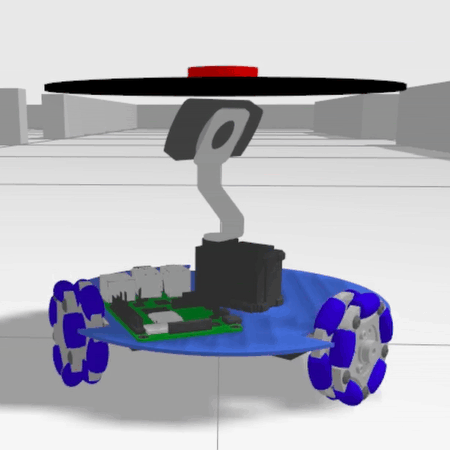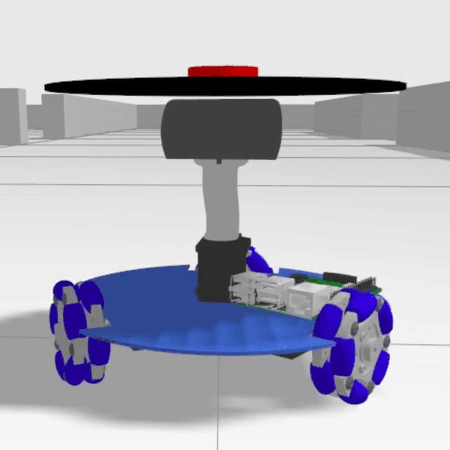
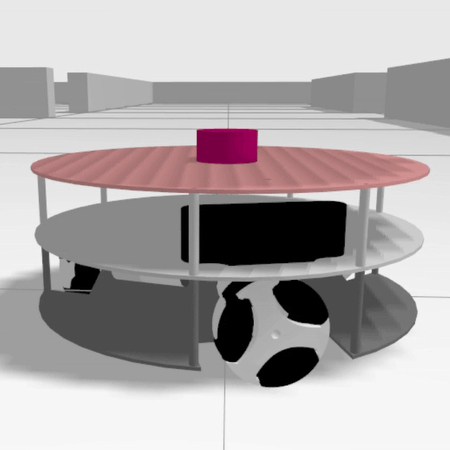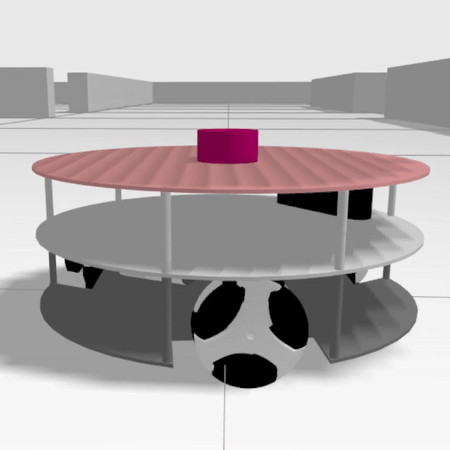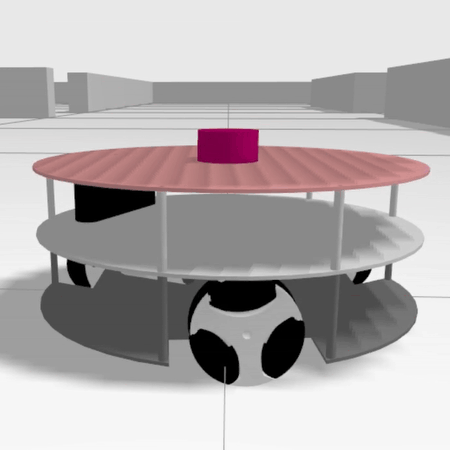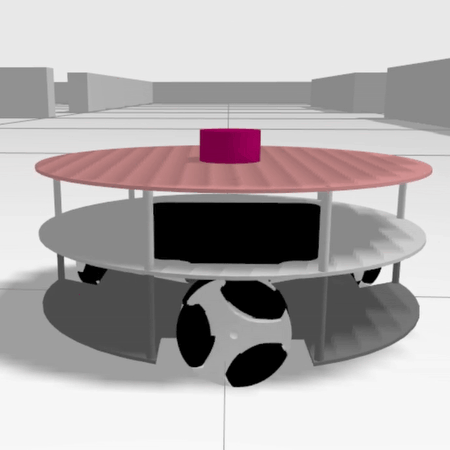
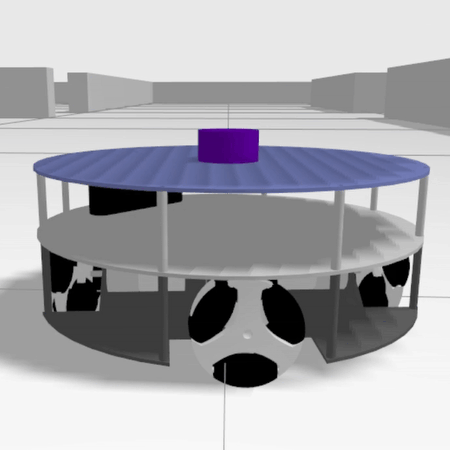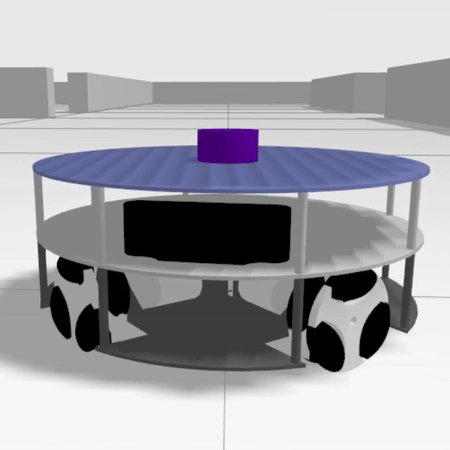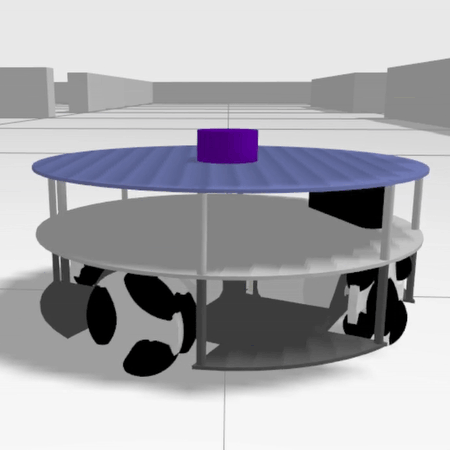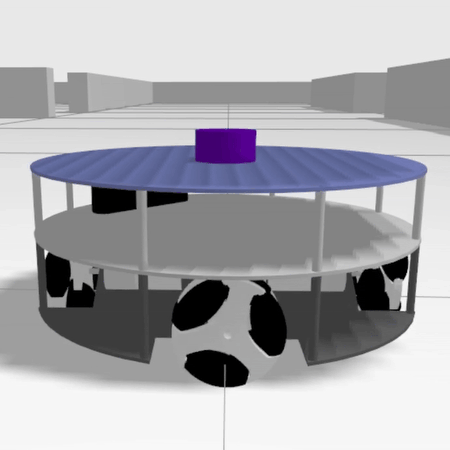
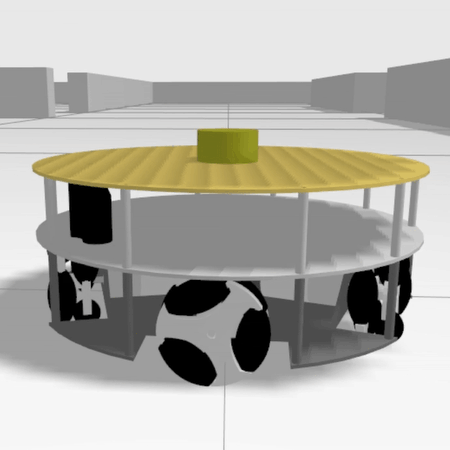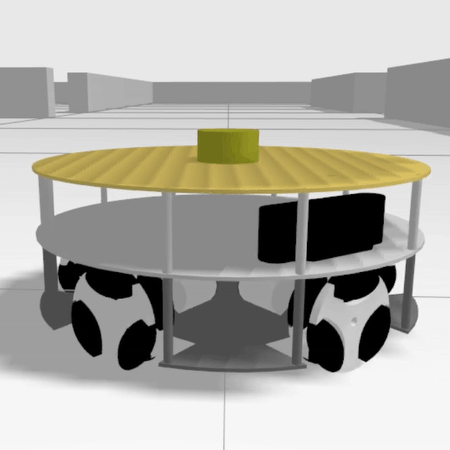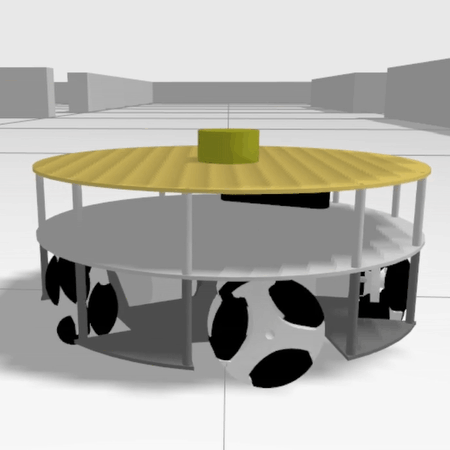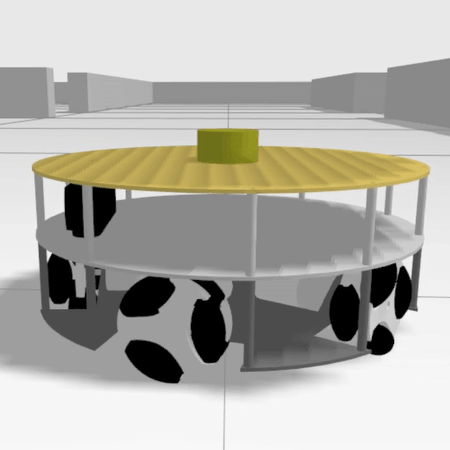
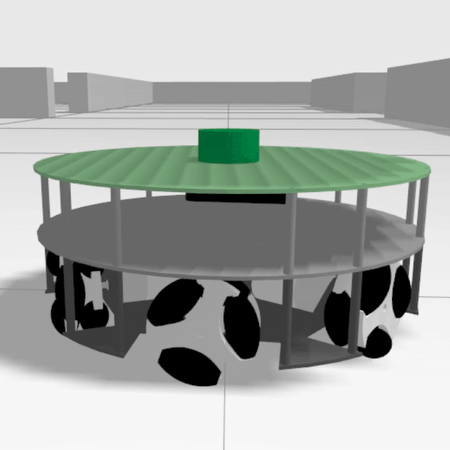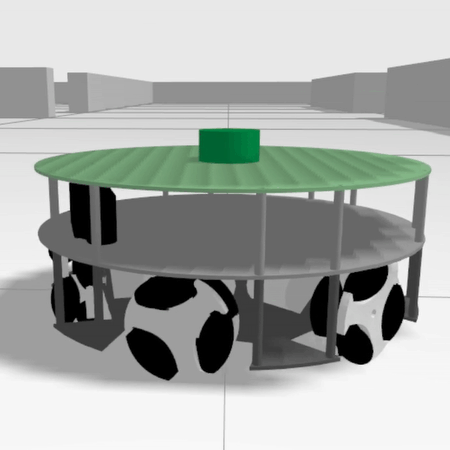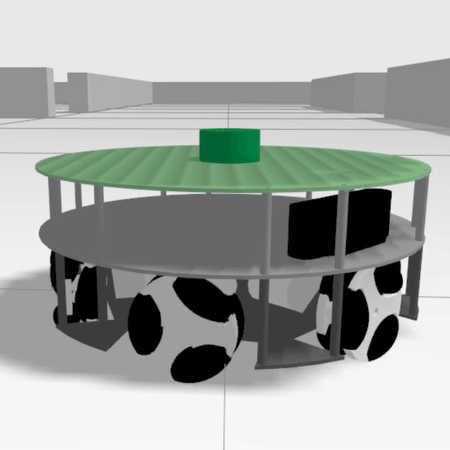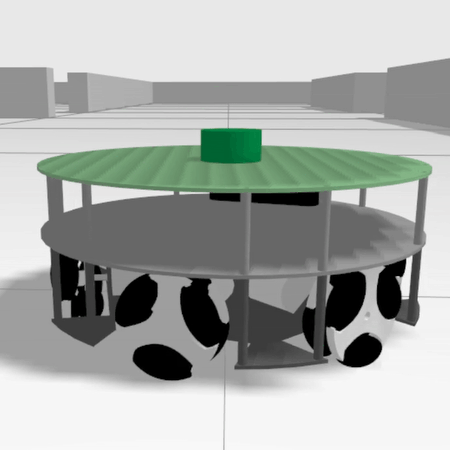
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
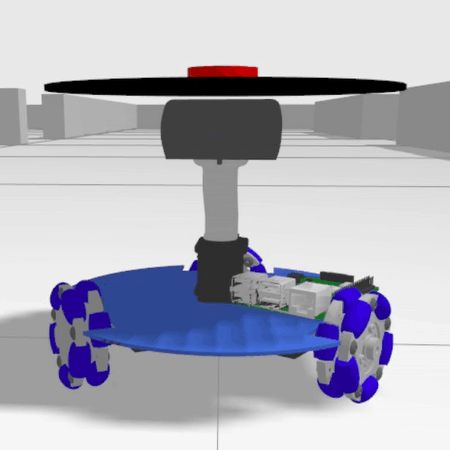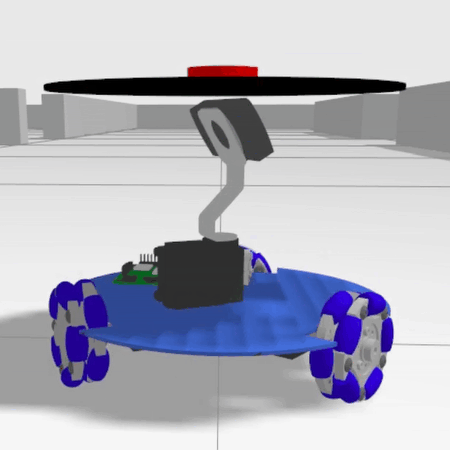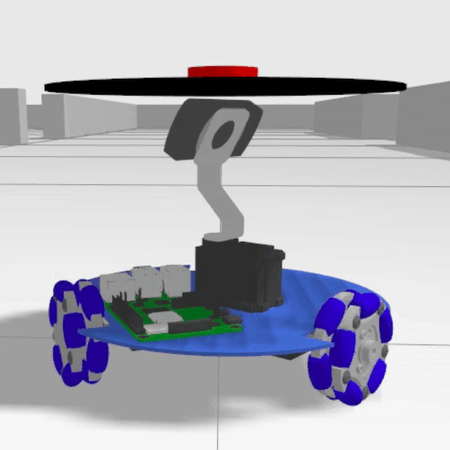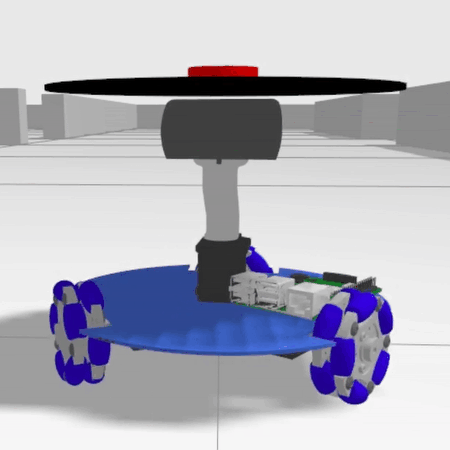 |
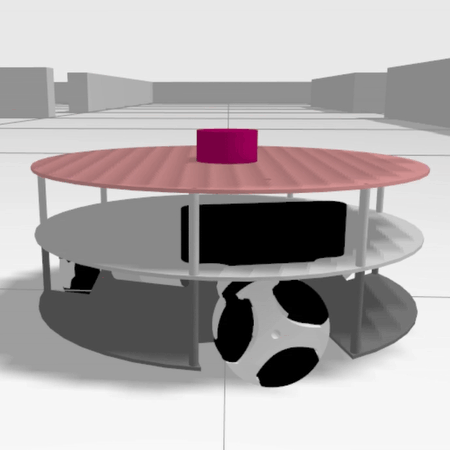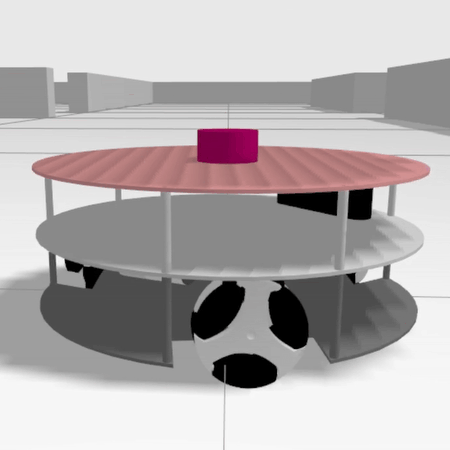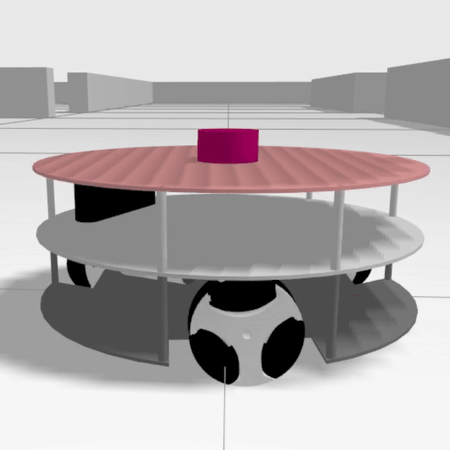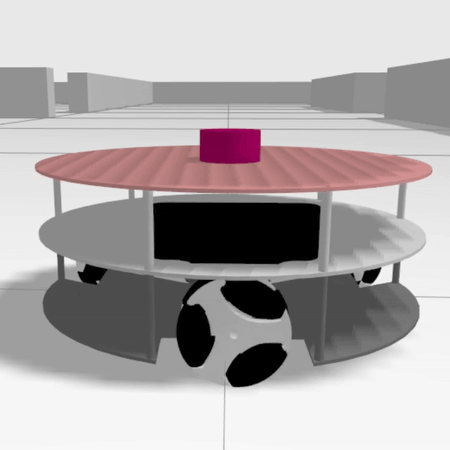 |
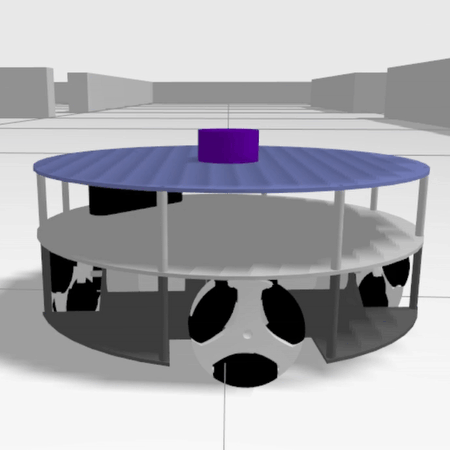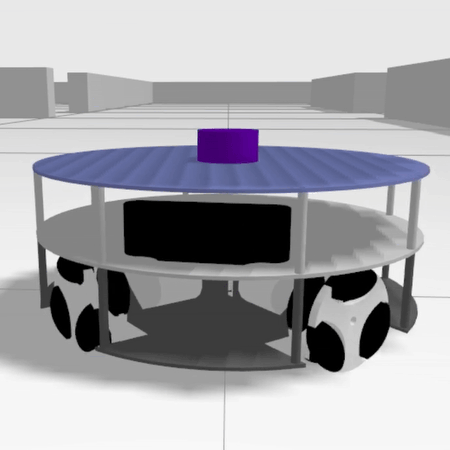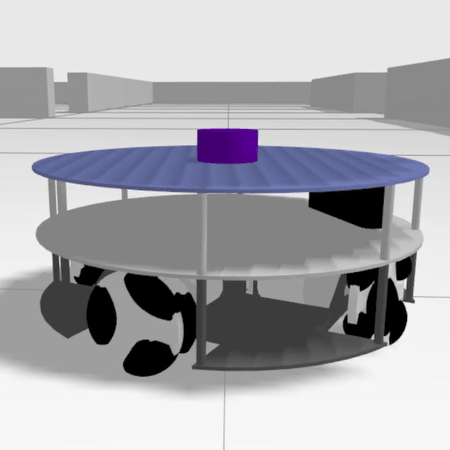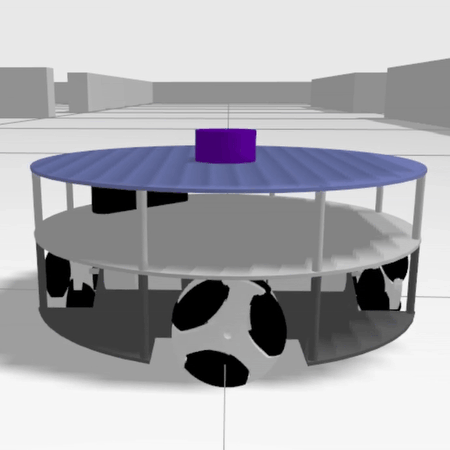 |
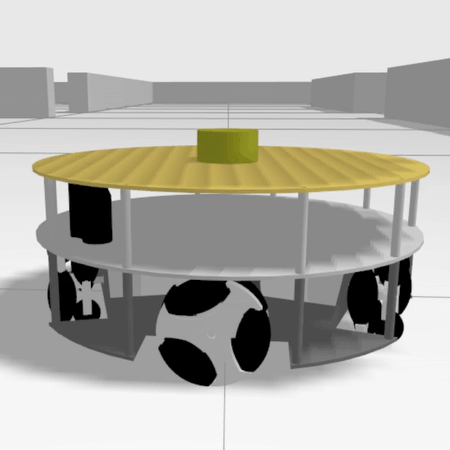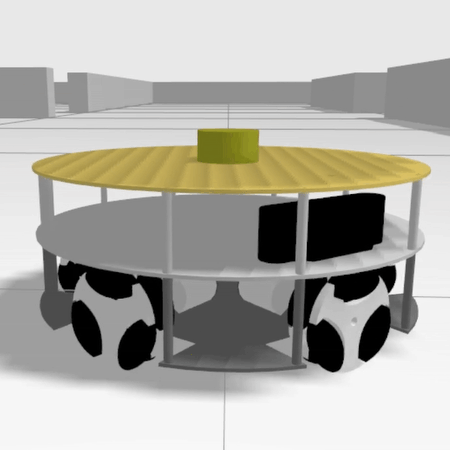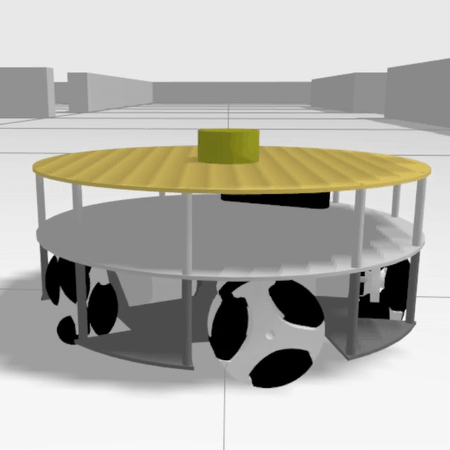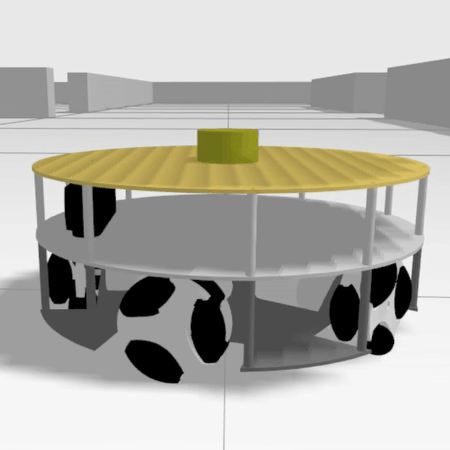 |
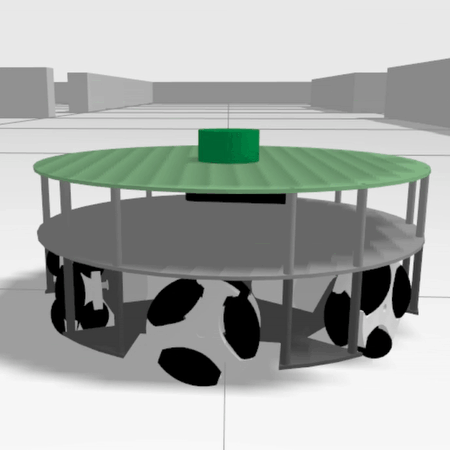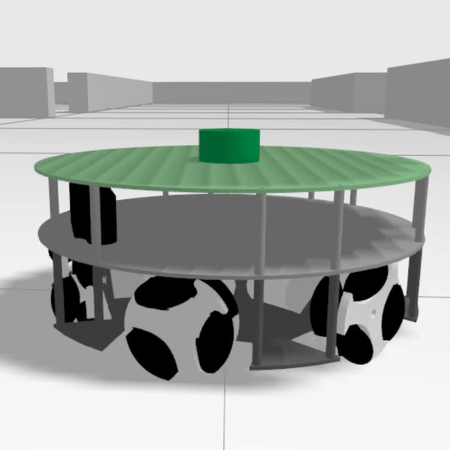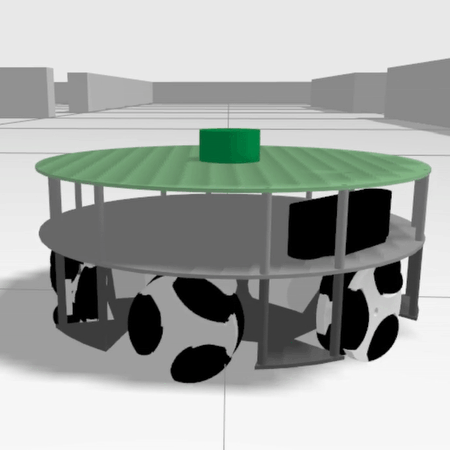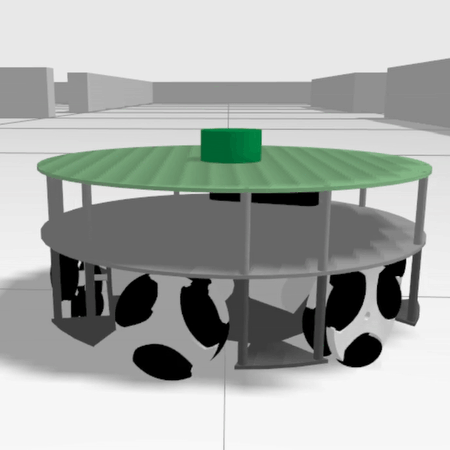 |
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni_description at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
|
|
|
|
|
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni_description at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | kilted |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
 |
 |
 |
 |
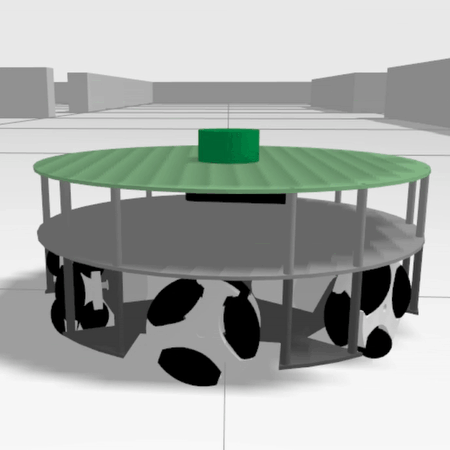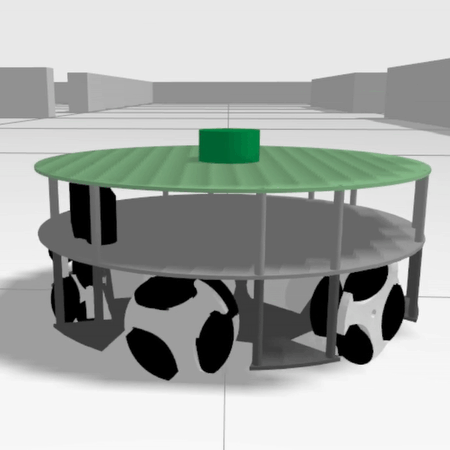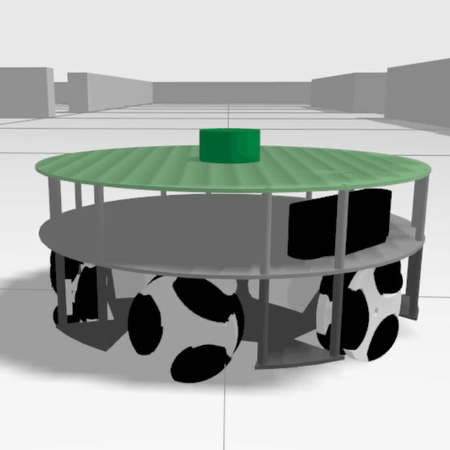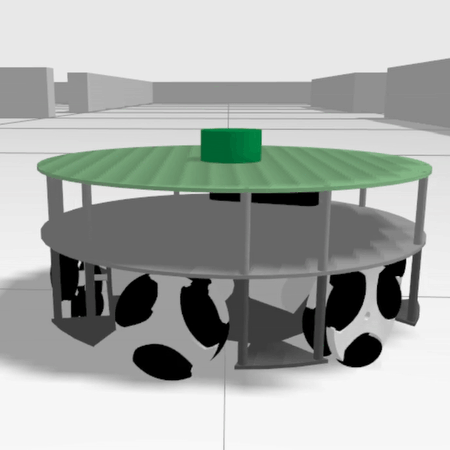 |
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni_description at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | lyrical |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
 |
 |
 |
 |
 |
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni_description at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
|
|
|
|
|
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |
Launch files
Messages
Services
Plugins
Recent questions tagged easynav_playground_omni_description at Robotics Stack Exchange
Package Summary
| Version | 0.5.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/easynav_playgrounds.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Francisco Martín Rico
Authors
- Yohan Prakoso
- Francisco Martín Rico
EasyNav Omni Playground: description
The three- to six-wheel omnidirectional robots used by the EasyNav playgrounds: URDF, meshes and ros2_control controllers. It depends neither on Gazebo nor on EasyNav: easynav_playground_omni_worlds simulates them, and easynav_playground_omni navigates with them.
Robots
3w |
3w_v2 (default) |
4w |
5w |
6w |
|---|---|---|---|---|
|
|
|
|
|
Build
From the ROS 2 workspace root:
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install --packages-up-to easynav_playground_omni_description
source install/setup.bash
To get the URDF of a robot (3w, 3w_v2, 4w, 5w, 6w):
xacro $(ros2 pkg prefix easynav_playground_omni_description)/share/easynav_playground_omni_description/urdf/3w_v2/main.urdf.xacro
Package layout
| Directory | Contents |
|---|---|
urdf/<robot>/ |
Each robot’s model (main.urdf.xacro) |
meshes/<robot>/ |
Its meshes |
config/controller_configs/ |
ros2_control controllers of each robot |
Authors and licensing
The robots are Yohan Prakoso’s: Copyright (c) 2025 Yohan Prakoso, under the MIT license; see LICENSE. Their paths were adapted to this package by Francisco Martín Rico at the Intelligent Robotics Lab (Universidad Rey Juan Carlos).
Changelog for package easynav_playground_omni_description
0.5.0 (2026-10-08)
- First release, in the easynav_playgrounds repository: the three- to six-wheel omnidirectional robots model (URDF, meshes and controllers), without Gazebo or EasyNav dependencies
- Contributors: Francisco Martín Rico, Juan Sebastián Cely Gutierrez
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| easynav_playground_omni_worlds |