 ROS Index

Package Summary
| Version | 0.0.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/space-ros/demos.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-10-02 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Robin BARAN
Authors
lunar_pole_exploration_rover
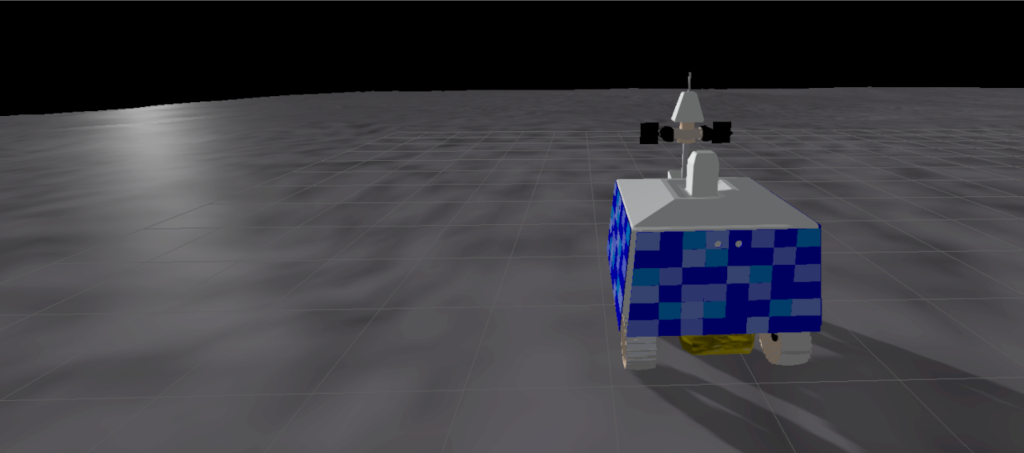
This package (and associated assets in the simulation repository) provides a Gazebo simulation of a lunar south pole exploration mission inspired by the real NASA VIPER mission.
The demo runs on ROS 2 Jazzy and Gazebo Harmonic.
It includes a realistic environment, the Mons Mouton, where the VIPER rover was planned to land, and a fully controllable rover model.
The key elements of the simulation is the integration of specifically developed Gazebo plugins. A solar panel plugin and associated battery and power consumption plugins aim to simulate the power generation challenge of the lunar south pole.
This package and associated plugins and models were developed by Robin Baran and Stevedan Ogochukwu Omodolor Omodia for the NASA Space ROS Sim Summer Sprint Challenge.
Challenge Name: NASA Space ROS Sim Summer Sprint Challenge
Team lead Freelancer name: @RBinson
Submission title: Lunar Pole Exploration Rover & Plugins
Table of contents
- Running the demo
- Contribution details
Running the demo
Building the docker
To build the docker image, go to the main folder of the lunar_pole_exploration_rover package and run:
./build.sh
The build process will take about 30 minutes, depending on the host computer.
Running the docker
After building the image, you can see the newly-built image by running:
docker image list
The output will look something like this:
REPOSITORY                             TAG                        IMAGE ID       CREATED        SIZE
osrf/lunar_pole_exploration_rover_demo latest                     629b13cf7b74   2 hours ago    7.8GB
openrobotics/moveit2                   latest                     6edb2edc9643   10 hours ago   15.5GB
nvidia/cudagl                          11.4.1-devel-ubuntu20.04   336416dfcbba   1 week ago     5.35GB
The new image is named osrf/lunar_pole_exploration_rover_demo:latest.
There is a run.sh script provided for convenience that will run the demo image in a container.
./run.sh
To enable hardware acceleration, use run_gpu.sh (requires a docker install not from snap)*
./run_gpu.sh
Once the container is running, launch the demo by typing the following command:
ros2 launch lunar_pole_exploration_rover lunar_pole_exploration_rover.launch.py
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged lunar_pole_exploration_rover at Robotics Stack Exchange
Package Summary
| Version | 0.0.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/space-ros/demos.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-10-02 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Robin BARAN
Authors
lunar_pole_exploration_rover
This package (and associated assets in the simulation repository) provides a Gazebo simulation of a lunar south pole exploration mission inspired by the real NASA VIPER mission.
The demo runs on ROS 2 Jazzy and Gazebo Harmonic.
It includes a realistic environment, the Mons Mouton, where the VIPER rover was planned to land, and a fully controllable rover model.
The key elements of the simulation is the integration of specifically developed Gazebo plugins. A solar panel plugin and associated battery and power consumption plugins aim to simulate the power generation challenge of the lunar south pole.
This package and associated plugins and models were developed by Robin Baran and Stevedan Ogochukwu Omodolor Omodia for the NASA Space ROS Sim Summer Sprint Challenge.
Challenge Name: NASA Space ROS Sim Summer Sprint Challenge
Team lead Freelancer name: @RBinson
Submission title: Lunar Pole Exploration Rover & Plugins
Table of contents
- Running the demo
- Contribution details
Running the demo
Building the docker
To build the docker image, go to the main folder of the lunar_pole_exploration_rover package and run:
./build.sh
The build process will take about 30 minutes, depending on the host computer.
Running the docker
After building the image, you can see the newly-built image by running:
docker image list
The output will look something like this:
REPOSITORY                             TAG                        IMAGE ID       CREATED        SIZE
osrf/lunar_pole_exploration_rover_demo latest                     629b13cf7b74   2 hours ago    7.8GB
openrobotics/moveit2                   latest                     6edb2edc9643   10 hours ago   15.5GB
nvidia/cudagl                          11.4.1-devel-ubuntu20.04   336416dfcbba   1 week ago     5.35GB
The new image is named osrf/lunar_pole_exploration_rover_demo:latest.
There is a run.sh script provided for convenience that will run the demo image in a container.
./run.sh
To enable hardware acceleration, use run_gpu.sh (requires a docker install not from snap)*
./run_gpu.sh
Once the container is running, launch the demo by typing the following command:
ros2 launch lunar_pole_exploration_rover lunar_pole_exploration_rover.launch.py
File truncated at 100 lines see the full file