 ROS Index

|
isaac_ros_nitros repositorycuapriltags_vendor cumotion_vendor cuvslam_vendor isaac_ros_nitros_bridge_ros2 |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/nvidia-isaac-ros/isaac_ros_nitros.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| cuapriltags_vendor | 5.0.0 |
| cumotion_vendor | 5.0.0 |
| cuvslam_vendor | 5.0.0 |
| isaac_ros_nitros_bridge_ros2 | 5.0.0 |
README
Isaac ROS NITROS
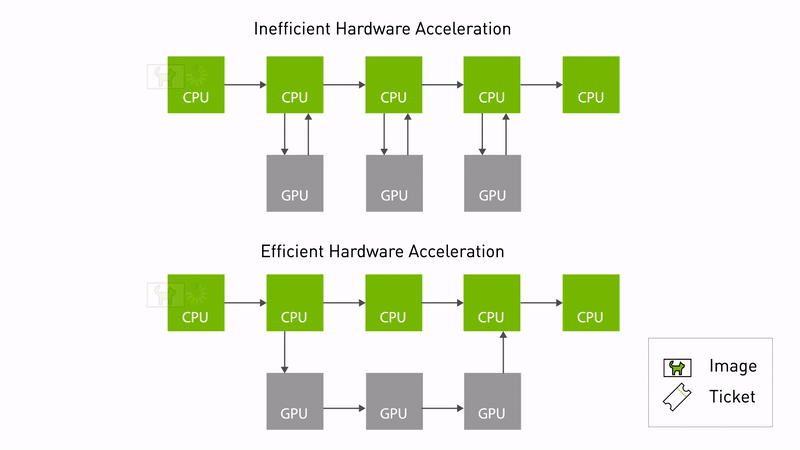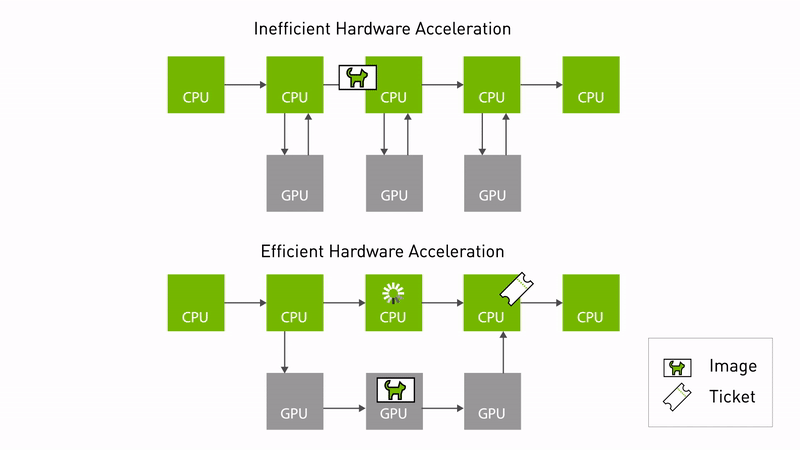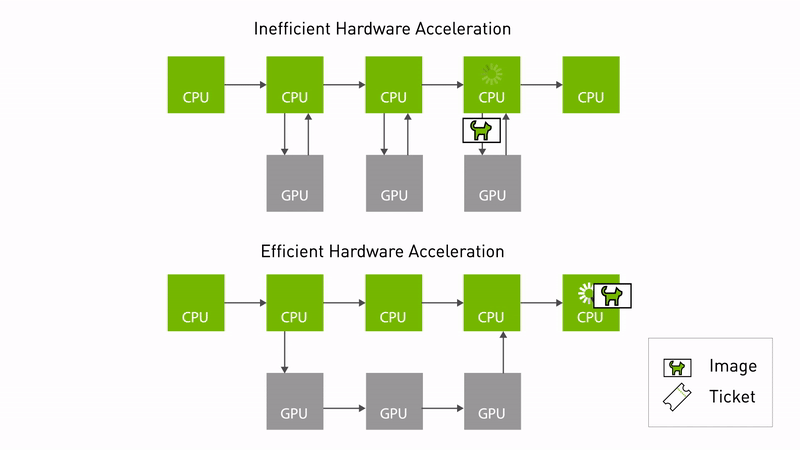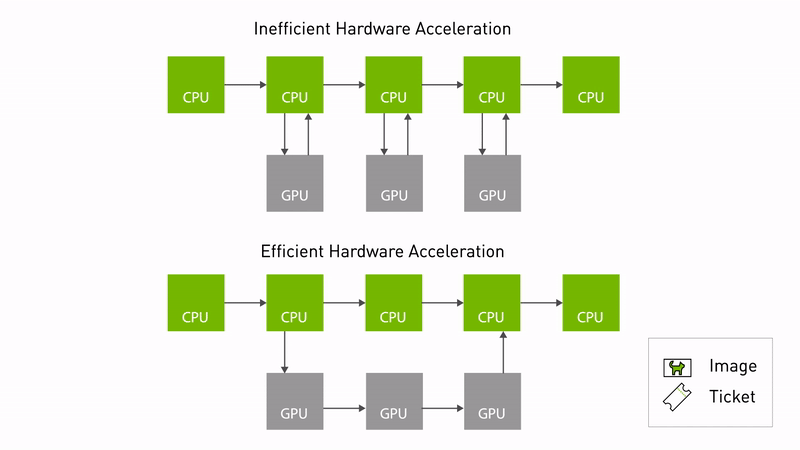
NVIDIA Isaac Transport for ROS package for hardware-acceleration friendly movement of messages.
Overview
NITROS is deprecated. Isaac ROS nodes now use ROS 2 messages with rosidl::Buffer fields and
the CUDA buffer backend, which are native ROS 2 Lyrical features. NITROS type adaptation and
negotiation, Managed NITROS, CUDA with NITROS, PyNITROS, and the NITROS Bridge APIs will be removed
in a future Isaac ROS release. Node-level compatibility is maintained, but applications that call
NITROS APIs directly require source-level migration. Refer to
From NITROS to rosidl::Buffer for the migration
guide, and rosidl::Buffer and Buffer Backends for the
replacement architecture.
Isaac ROS NITROS now contains the vendor packages that distribute NVIDIA’s precompiled SDKs to other Isaac ROS repositories, along with the remaining NITROS Bridge converter.
Documentation
Please visit the Isaac ROS Documentation to learn how to use this repository.
Packages
-
cuapriltags_vendor: Vendor package for the precompiled NVIDIA cuAprilTags SDK. -
cumotion_vendor: Vendor package for the precompiled NVIDIA cuMotion SDK. -
cuvslam_vendor: Vendor package for the precompiled NVIDIA cuVSLAM SDK. -
isaac_ros_nitros_bridge_ros2: Converter between NITROS bridge messages and ROS 2 messages.
Latest
Update 2026-09-21: Deprecated NITROS in favor of rosidl::Buffer and the CUDA buffer backend
CONTRIBUTING
|
|
isaac_ros_nitros repositorycuapriltags_vendor cumotion_vendor cuvslam_vendor isaac_ros_nitros_bridge_ros2 |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/nvidia-isaac-ros/isaac_ros_nitros.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-09-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| cuapriltags_vendor | 5.0.0 |
| cumotion_vendor | 5.0.0 |
| cuvslam_vendor | 5.0.0 |
| isaac_ros_nitros_bridge_ros2 | 5.0.0 |
README
Isaac ROS NITROS
NVIDIA Isaac Transport for ROS package for hardware-acceleration friendly movement of messages.
Overview
NITROS is deprecated. Isaac ROS nodes now use ROS 2 messages with rosidl::Buffer fields and
the CUDA buffer backend, which are native ROS 2 Lyrical features. NITROS type adaptation and
negotiation, Managed NITROS, CUDA with NITROS, PyNITROS, and the NITROS Bridge APIs will be removed
in a future Isaac ROS release. Node-level compatibility is maintained, but applications that call
NITROS APIs directly require source-level migration. Refer to
From NITROS to rosidl::Buffer for the migration
guide, and rosidl::Buffer and Buffer Backends for the
replacement architecture.
Isaac ROS NITROS now contains the vendor packages that distribute NVIDIA’s precompiled SDKs to other Isaac ROS repositories, along with the remaining NITROS Bridge converter.
Documentation
Please visit the Isaac ROS Documentation to learn how to use this repository.
Packages
-
cuapriltags_vendor: Vendor package for the precompiled NVIDIA cuAprilTags SDK. -
cumotion_vendor: Vendor package for the precompiled NVIDIA cuMotion SDK. -
cuvslam_vendor: Vendor package for the precompiled NVIDIA cuVSLAM SDK. -
isaac_ros_nitros_bridge_ros2: Converter between NITROS bridge messages and ROS 2 messages.
Latest
Update 2026-09-21: Deprecated NITROS in favor of rosidl::Buffer and the CUDA buffer backend