 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps



opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
 adding_images |
 discrete_fourier_transform |
 edge_detection |
 equalize_histogram |
 morphology |
 pyramids |
 smoothing |
 threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
 hsv_color_filter |
 hls_color_filter |
 lab_color_filter |
 rgb_color_filter |
 compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
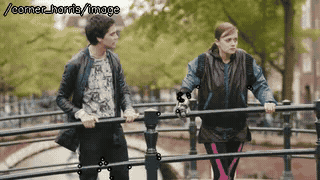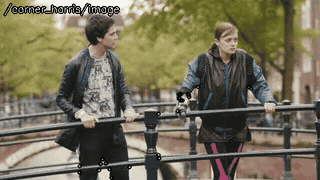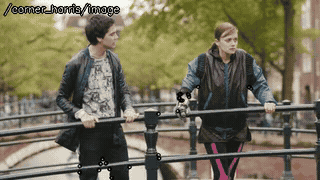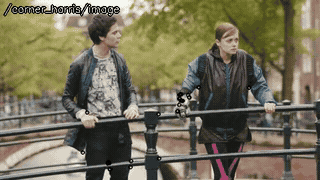 corner_harris |
 goodfeature_track |
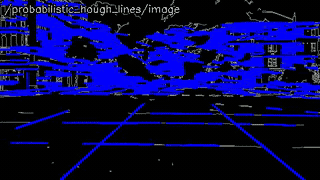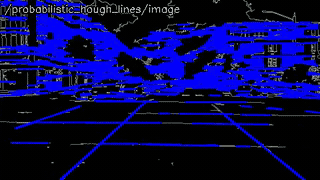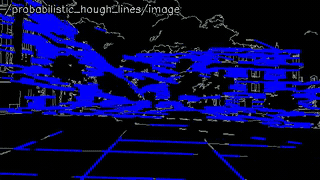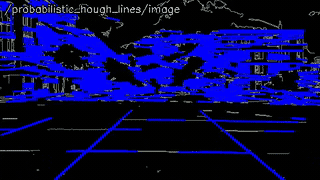 hough_lines |
 hough_circles |
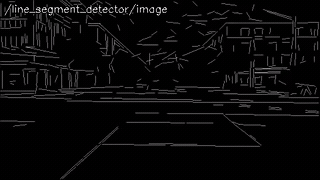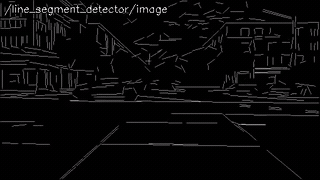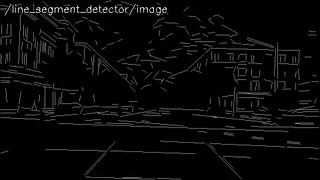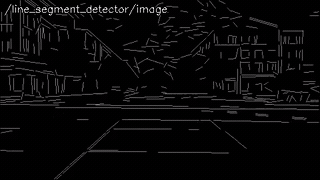 line_segment_detector |
 find_contours |
 general_contours |
 contour_moments |
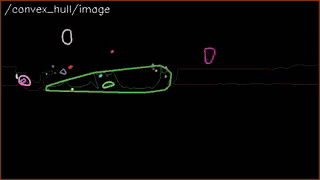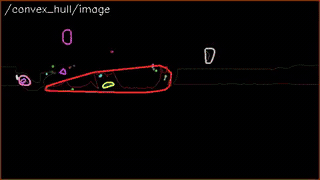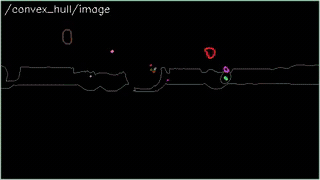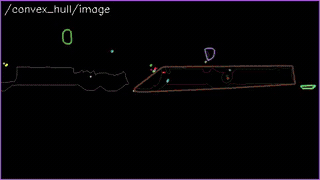 convex_hull |
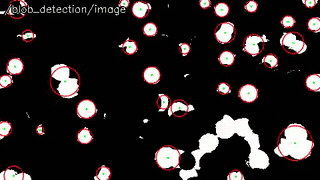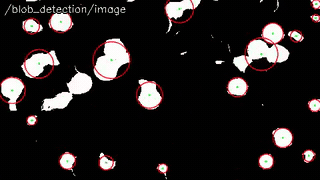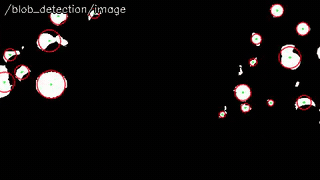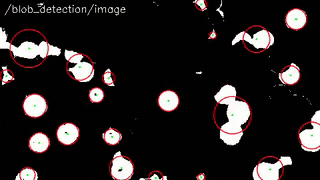 blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
 segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.
Repository Summary
| Description | |
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNKNOWN |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| opencv_apps | 3.0.0 |
README
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/README.md)
CONTRIBUTING
Contributing to opencv_apps
opencv_apps wraps OpenCV samples (from opencv/samples/cpp, samples/tapi, tutorials, or elsewhere) as ROS nodes.
One source file builds on both ROS1 (catkin) and ROS2 (colcon/ament). Please keep each node small and focused on
one OpenCV feature, and follow the layout below so the repository stays consistent.
Checklist for a new node <name> (class <Name>Nodelet)
Use threshold as the template; see also camshift (trackbars/mouse) and face_recognition (services).
-
Nodelet
src/nodelet/<name>_nodelet.cpp, written in the ROS2 API onopencv_apps::Nodelet(include/opencv_apps/nodelet.h):- parameters:
declare_parameter(name, default, paramDescriptor(desc, min, max)), updated in aparametersCallbackregistered withadd_on_set_parameters_callback; - I/O:
subscribeImage/subscribeCamerainsubscribe(),advertiseImage/advertisefor outputs; - end with
RCLCPP_COMPONENTS_REGISTER_NODE(opencv_apps::<Name>Nodelet). - On ROS1 the same file compiles through
ros1/include/opencv_apps/ros1_compat.h, which also serves the declared parameters as dynamic_reconfigure (startReconfigureServer,~set_parameters). Acfg/*.cfgis therefore not needed for new nodes; existing nodes keep theirs only for compatibility (if you add one, its defaults/ranges must match theparamDescriptor). - Guard OpenCV API differences with
CV_MAJOR_VERSION/CV_MINOR_VERSION(OpenCV 3.x/4.x are in CI).
- parameters:
-
CMakeLists.txt, both sections (keep changes scoped to the new node; do not restructure other targets):
- ROS2:
<name>:<Name>Nodeletin_nodeletsandsrc/nodelet/<name>_nodelet.cppin_nodelet_cppfiles; - ROS1:
opencv_apps_add_nodelet(<name> src/nodelet/<name>_nodelet.cpp). - opencv_contrib modules: gate both with
if(TARGET opencv_xxx)(seeopencv_optflow/simple_flow), and the tests too.
- ROS2:
-
nodelet_plugins.xml:
<class name="opencv_apps/<name>" type="opencv_apps::<Name>Nodelet" ...>. -
New messages:
msg/<Type>.msg(globbed on ROS2; add it to ROS1add_message_files) and a shimros1/include/opencv_apps/msg/<snake_type>.hpplikemsg/circle.hpp. -
Launch:
launch/<name>.launch(ROS1) andlaunch/<name>.launch.xml(ROS2) with the same arguments. -
Tests (required):
- ROS1:
test/test-<name>.test(rostest +hztest), registered intest/CMakeLists.txtwithadd_rostest(test-<name>.test ARGS gui:=false); - ROS2:
test/ros2/test_<name>.py(launch_testing, globbed automatically) usingcamera(),include(),description()andTopicsTestfromtest/ros2/opencv_apps_test.py.
- ROS1:
- README.md: add the node to the list.
Build and test
# ROS1
catkin_make
catkin_make run_tests   # all tests; results in build/test_results/opencv_apps/
# one test (catkin-generated target name, list them with `make -C build help | grep run_tests`):
catkin_make run_tests_opencv_apps_rostest_test-<name>__gui_false.test

# ROS2
colcon build --packages-select opencv_apps --cmake-args -DBUILD_TESTING=ON
colcon test --packages-select opencv_apps --ctest-args -R <name>
colcon test-result --verbose
CI (.github/workflows/ci.yml, .travis.sh) also runs clang-format, catkin_lint and clang-tidy; to check locally:
clang-format -i -style=file src/nodelet/<name>_nodelet.cpp   # repository .clang-format
ROS_DISTRO=melodic ROS_VERSION=1 catkin_lint --resolve-env --strict .   # use the catkin_lint version pinned in ci.yml
# clang-tidy (repository .clang-tidy): build with -DCMAKE_EXPORT_COMPILE_COMMANDS=ON, then
run-clang-tidy -p <build dir containing compile_commands.json>
Pull requests
Each PR must include:
- the test(s) above, passing on ROS1 and ROS2;
- a demo video (GIF or mp4) of the node output (e.g.
/<name>/image) in the PR description.