 ROS Index

Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles


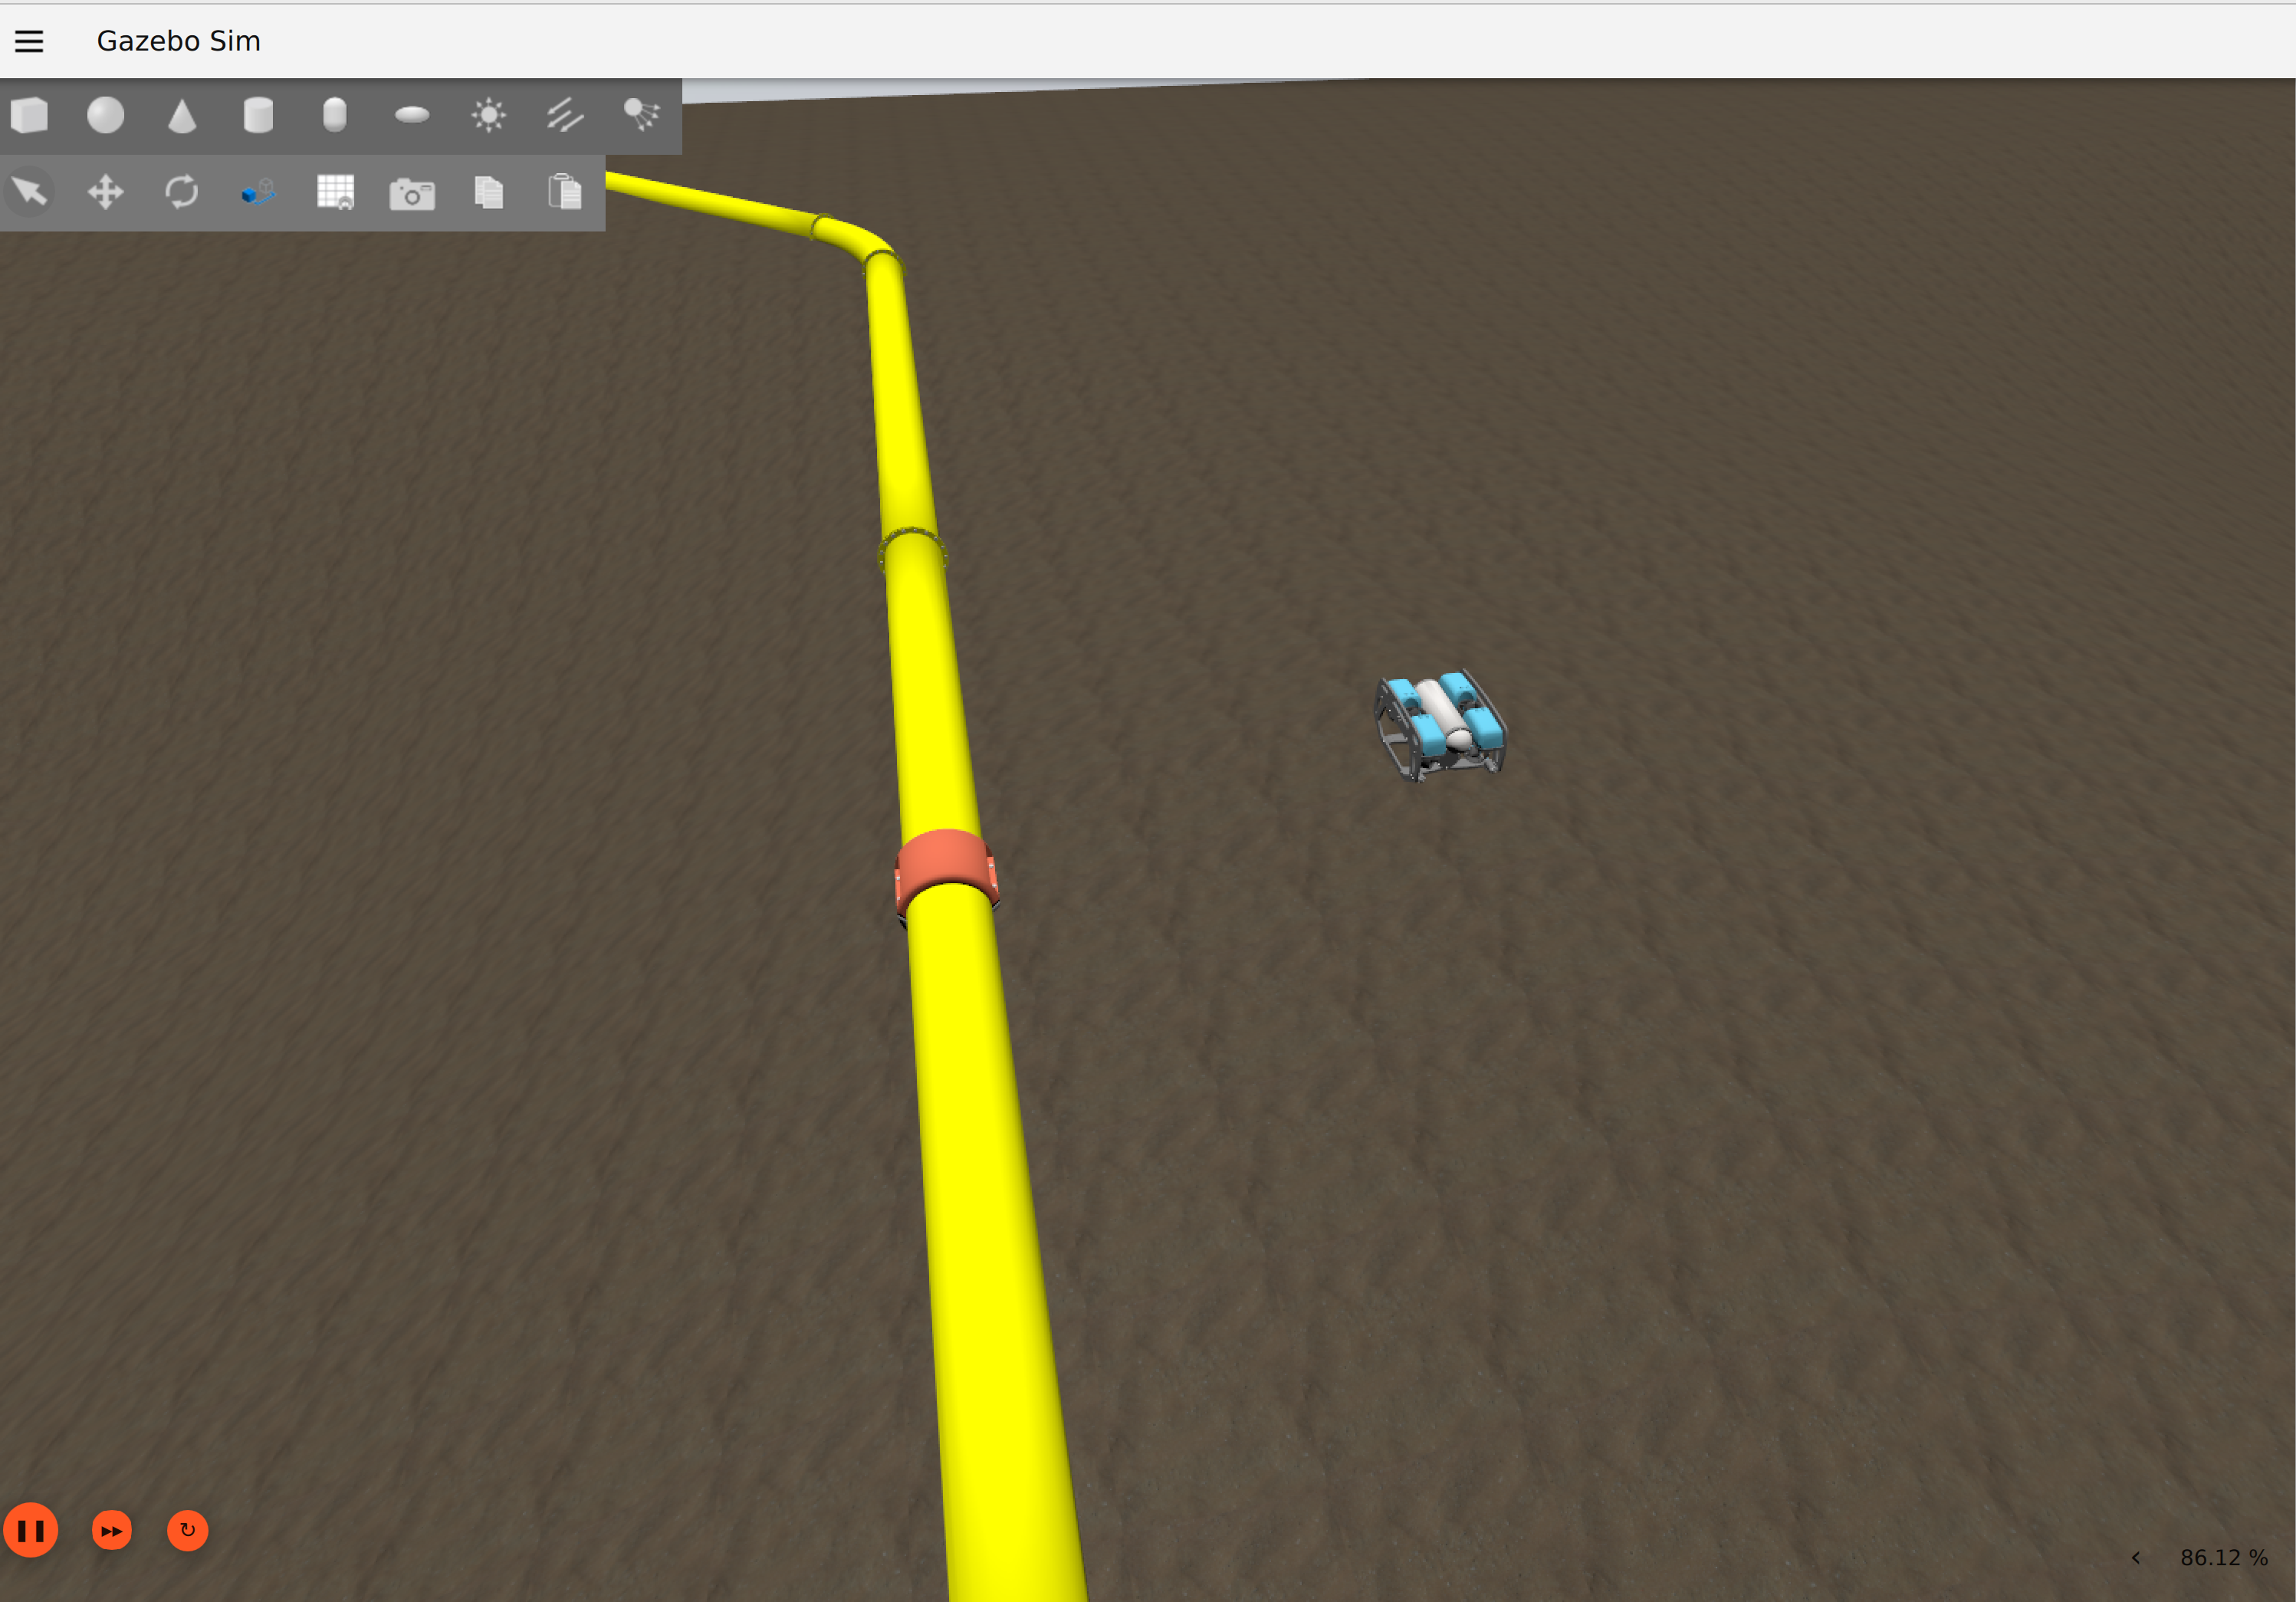
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:

Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file
CONTRIBUTING
Repository Summary
| Description | |
| Checkout URI | https://github.com/kas-lab/suave.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-11-15 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| suave | 0.0.0 |
| suave_base | 0.0.0 |
| suave_bringup | 0.0.0 |
| suave_cli | 0.0.0 |
| suave_bt | 0.0.0 |
| suave_metacontrol | 0.0.0 |
| suave_none | 0.0.0 |
| suave_random | 0.0.0 |
| suave_metrics | 0.0.0 |
| suave_missions | 0.0.0 |
| suave_monitor | 0.0.0 |
| suave_msgs | 0.0.0 |
| suave_requirements | 0.0.0 |
| suave_runner | 0.0.0 |
| suave_tools | 0.0.0 |
README
SUAVE: An Exemplar for Self-Adaptive Underwater Vehicles
SUAVE (Self-adaptive Underwater Autonomous Vehicle Exemplar) is a ROS 2 Humble exemplar for self-adaptive robotics. An autonomous underwater vehicle (AUV) searches for a pipeline on the seabed, then follows and inspects it, while its thrusters fail, the water visibility changes, and its battery drains.
SUAVE separates the managed subsystem, which implements the AUV’s mission, from the managing subsystem, which implements the adaptation logic. Any managing subsystem that uses SUAVE’s ROS 2 interfaces can be plugged in, so different adaptation approaches can be compared on the same missions and metrics.
Documentation: https://kas-lab.github.io/suave/
A video of SUAVE running (click the image to open it):
An overview of the system:
Quick start
With Docker installed:
git clone https://github.com/kas-lab/suave.git
cd suave
source env.sh
suave docker run
suave run
suave docker run pulls the headless image and starts a container named
suave, and suave run starts an experiment campaign in it. Results are
saved to ~/suave/results on the host. Add --gpu none to suave docker run
on machines without an NVIDIA GPU.
To try SUAVE in a browser-based desktop instead, or to install it without Docker, see Docker and Installation.
Documentation
| Page | Contents |
|---|---|
| Mission and uncertainties | What the AUV does, the uncertainties it faces, its KPIs and quality requirements |
| Installation | Local installation with Gazebo, ROS 2, ArduSub, and the SUAVE workspace |
| Docker | Headless and browser-based images |
| SUAVE CLI | The suave command for containers, builds, tests, and experiments |
| Run SUAVE | Campaigns, batches, failure diagnosis, and recovery |
| Processing results | Summaries, statistical tests, plots, and LaTeX tables |
| Metrics | Recorded mission metrics and reaction times |
| Architecture | Managed functionalities, monitors, and managing-subsystem interfaces |
| Extending SUAVE | Connecting a new managing subsystem or adding functionality |
| Implementations | Available managing subsystems |
| Troubleshooting | Common problems and dependency versions |
Managing subsystems
Built into this repository:
- None: no adaptation, a lower-bound baseline.
- Random: adapts at random intervals, a chance baseline.
- Metacontrol: ontology-based reasoning with MROS2.
- Behavior Tree: adaptation logic as a BehaviorTree.CPP tree.
Maintained separately:
See Implementations for details and Extending SUAVE to connect your own.
Repository layout
| Path | Contents |
|---|---|
suave |
Managed subsystem functionalities and simulation launch |
suave_monitor |
Thruster, water visibility, and battery monitors |
suave_missions |
Mission nodes and mission configuration |
suave_base |
Reusable launch of the managed system and metrics, for external managing subsystems |
suave_bringup |
Launch composition of missions with the built-in managing subsystems |
suave_metrics |
Mission metrics collection |
File truncated at 100 lines see the full file