 ROS Index

|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
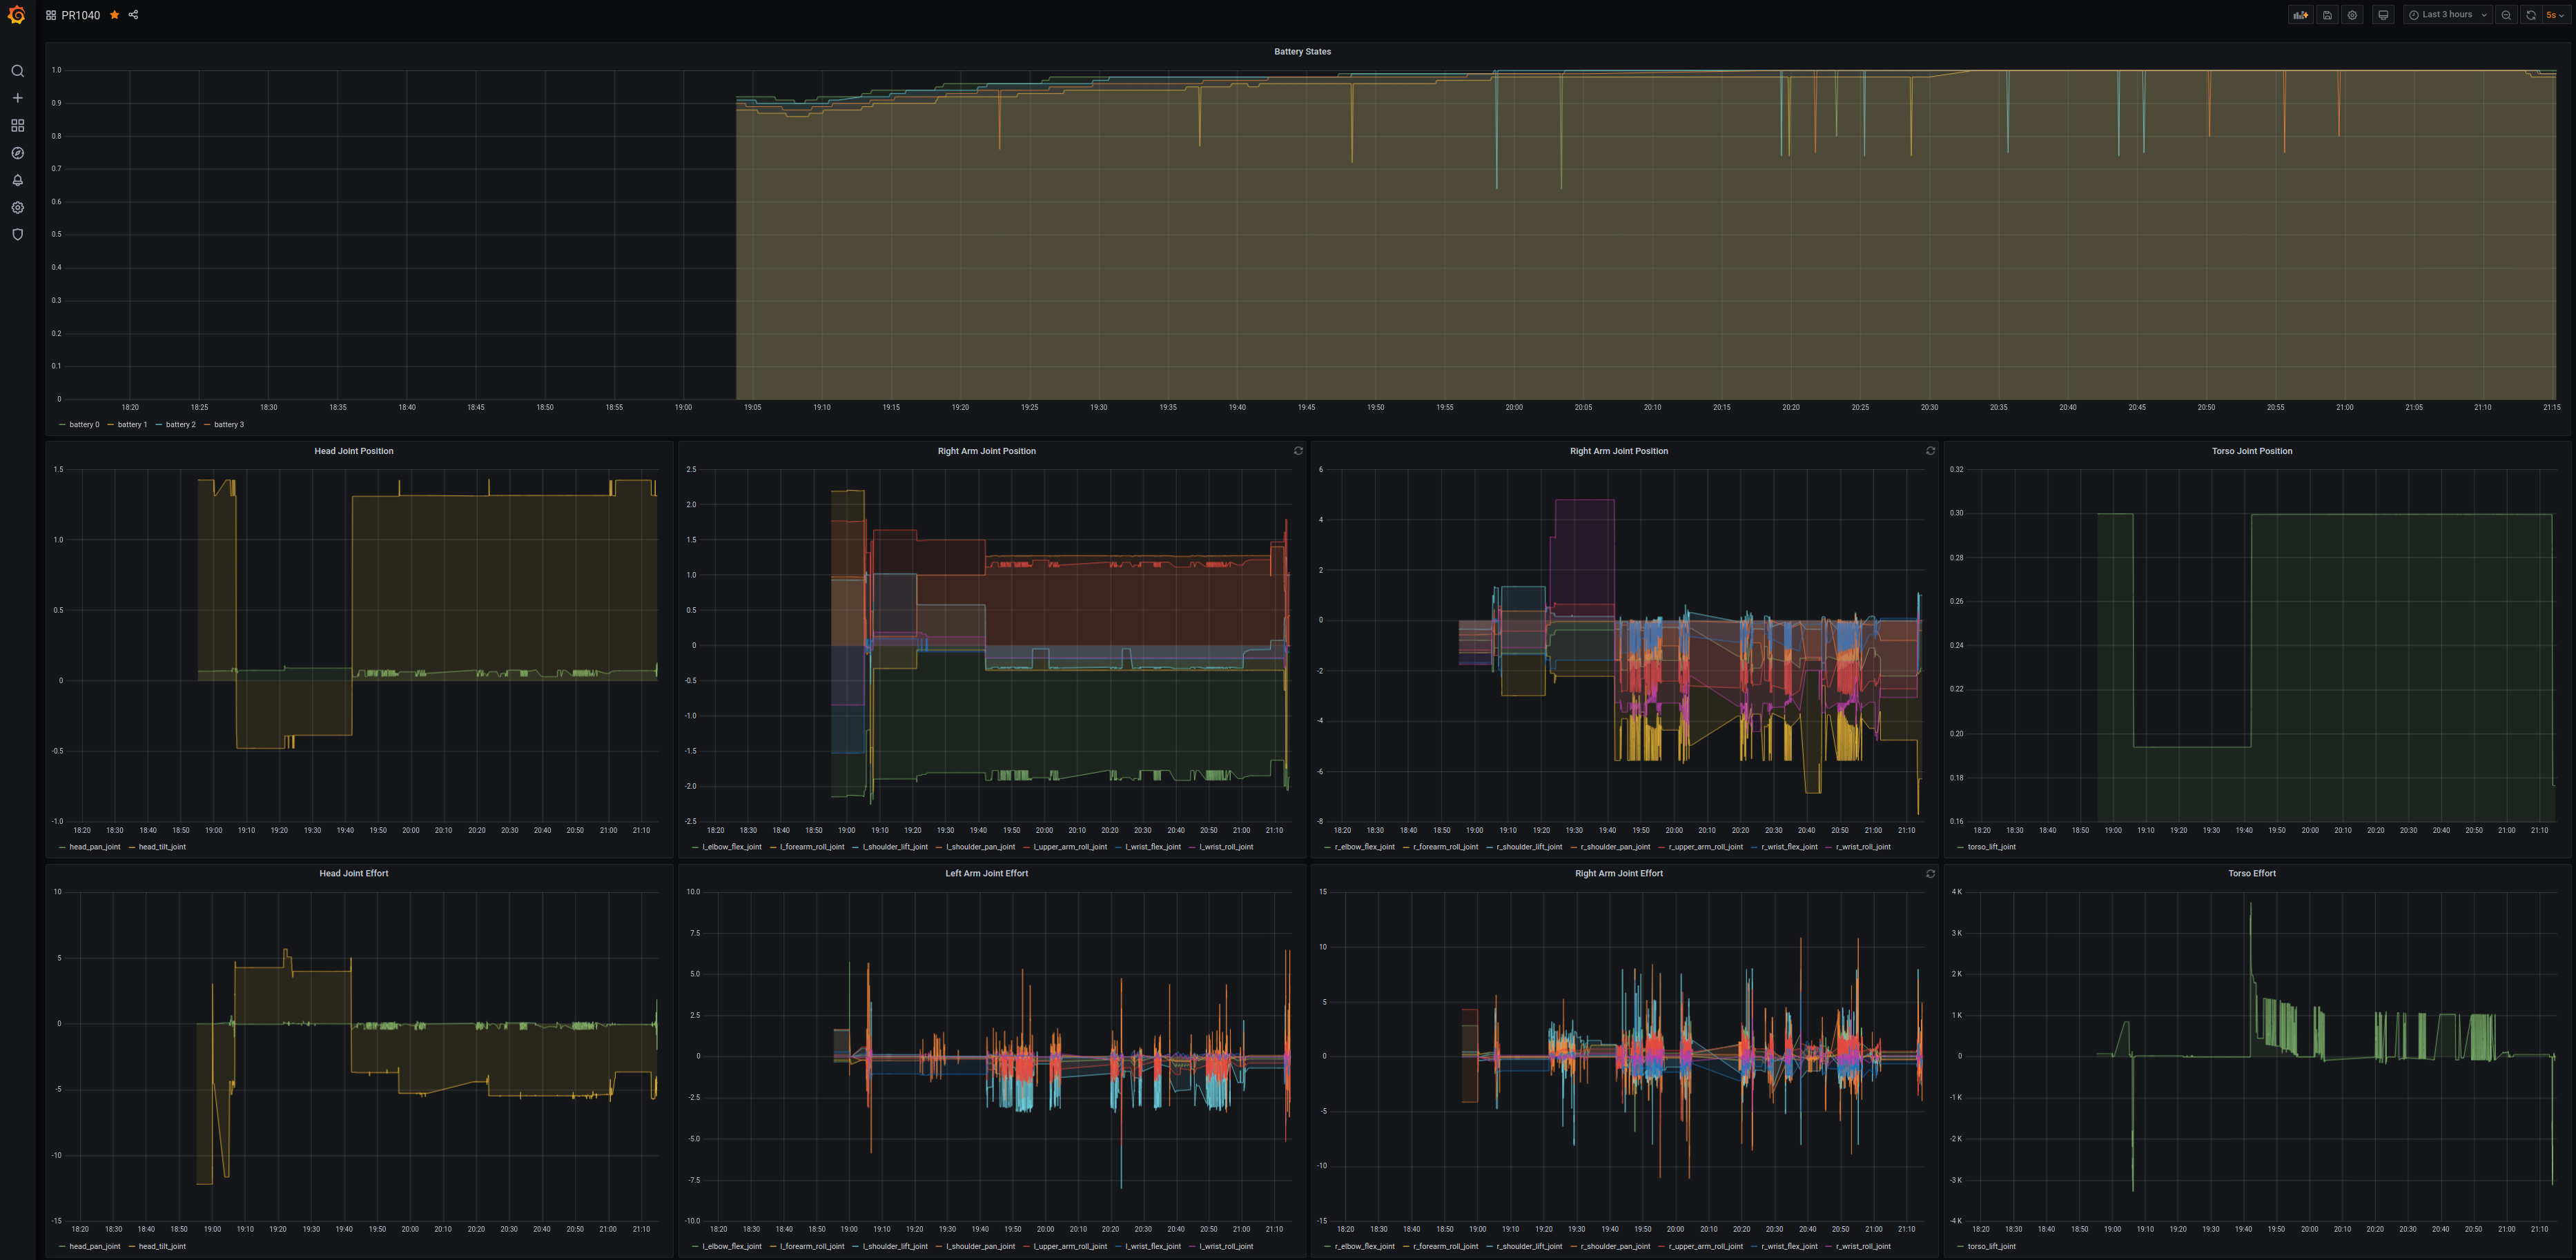
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]
Messages
Services
Plugins
Recent questions tagged influxdb_store at Robotics Stack Exchange
|
|
influxdb_store package from jsk_3rdparty repovoicevox chaplus_ros emotion_analyzer gdrive_ros google_chat_ros influxdb_store jsk_power_switching_tools respeaker_ros ros_speech_recognition rospatlite sesame_ros switchbot_ros |
ROS Distro
|
Package Summary
| Version | 3.0.1 |
| License | BSD-3-Clause |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/jsk-ros-pkg/jsk_3rdparty.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-11-13 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Shingo Kitagawa
Authors
- Shingo Kitagawa
influxdb_store
ROS package for influxdb store
Sample
roslaunch influxdb_store influxdb_logger.launch
Logger
joint_states_logger.py
Logger for sensor_msgs/JointStates
Subscribing topic
-
~input(sensor_msgs/JointStates)
Joint states topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
map_transform_logger.py
Logger for transfrom relative to map_frame
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
-
~map_frame_id(default:map)
Map frame id
-
~update_rate(default:0.5)
Update rate
battery_states_logger.py
Logger for pr2_msgs/BatteryServer2
Subscribing topic
-
~input(pr2_msgs/BatteryServer2)
Battery topic name
Parameters
-
~host(default:localhost)
Influxdb host address
-
~port(default:8086)
Influxdb port number
-
~database(default:test)
Influxdb database name
network_states_logger.py
Logger for network information published by jsk_network_tools/network_status.py
Subscribing topic
-
~input/receive(std_msgs/Float32)
receiving bps topic name
-
~input/transmit(std_msgs/Float32)
File truncated at 100 lines see the full file
Changelog for package influxdb_store
3.0.1 (2026-11-10)
- Merge pull request #583 from k-okada/rosdistro-55247-review rosdistro#55247 review: rename power_switching_tools_ros to jsk_power_switching_tools, fix licenses
- use SPDX license identifiers (BSD-3-Clause, Apache-2.0) in package.xml BSD -> BSD-3-Clause and Apache / "Apache License, Version 2.0" -> Apache-2.0 in all packages (ros/rosdistro#55247 review). The LICENSE files of all of them are BSD 3-Clause and Apache 2.0 respectively. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
- Contributors: Kei Okada
3.0.0 (2026-11-06)
-
Merge pull request #581 from k-okada/ros2-buildfarm-ros-environment Fix ROS2 buildfarm binary jobs: ros_environment, bundled flac, numpy wheel
-
[voicevox, chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, ros_speech_recognition, rospatlite, sesame_ros, switchbot_ros] depend on ros_environment for ROS2 buildfarm The buildfarm builds each package with only its own build dependencies, so without ros_environment $ROS_VERSION is empty and CMakeLists.txt takes the ROS1 branch (same as jsk_common#1835). voicevox also guesses ROS_VERSION from AMENT_PREFIX_PATH when it is unset. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into fix_hoya
-
Merge branch 'master' into voicevox-ros1-ros2
-
AMENT_IGNORE: do not add AMENT_IGNORE to packages already ported to ROS2 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros and switchbot_ros are already ROS2 packages on master, so this PR must not AMENT_IGNORE them. Also remove ros_speech_recognition/AMENT_IGNORE, as this PR ports it to ROS2. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Merge branch 'master' into ros2-speech-recognition-only
-
Merge pull request #575 from k-okada/ros2-support Add ROS2 (jazzy) support to chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, respeaker_ros, rospatlite, sesame_ros, switchbot_ros
-
AMENT_IGNORE packages ported to ROS2 in jsk-ros-pkg/jsk_3rdparty#575 chaplus_ros, emotion_analyzer, gdrive_ros, google_chat_ros, influxdb_store, power_switching_tools_ros, rospatlite, sesame_ros and switchbot_ros are ROS1 only here, so the ROS2 CI skips them until #575. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
[influxdb_store] add ROS2 support Single package.xml/CMakeLists.txt branched on $ROS_VERSION, same as chaplus_ros and jsk_common's ROS2-ported packages.
- CMakeLists.txt: the ROS2 block is prepended and the ROS1 original is wrapped in else()/endif() unchanged (no re-indentation). The influxdb_store python package is installed with ament_python_install_package(), and the installed ROS2 copies of the ported node scripts get a python3 shebang.
- joint_states_logger.py/network_states_logger.py: use jsk_ros1_ros2_compat's rospy_rclpy_compat (get_param, log*, create_subscription/timer, stamp_now), keeping the ROS1 structure as-is. jsk_ros1_ros2_compat is only released with jsk_common >= 3.0, so it is a ROS2-only dependency and the scripts fall back to forwarding ros_compat.xxx(node, ...) to rospy.xxx(...) when it is not importable.
- utils.timestamp_to_influxdb_time(): accept ROS2 builtin_interfaces Time via rospy_rclpy_compat.stamp_to_sec() (falls back to to_sec()).
- __init_.py: TransformLogger imports rospy, so import it only when available.
- Stay ROS1-only for now: base/map_transform_logger.py (TransformLogger uses the ROS1 tf2_ros buffer_server's ~tf2_frames service and rospy.TimerEvent), pr2/fetch_battery_states_logger.py (pr2_msgs/power_msgs), and the ROS1 launch files. pr2_msgs is now a ROS1-only dependency.
- The ROS2 scripts are installed with jsk_ros1_ros2_compat's jsk_ros1_ros2_compat_install_python() (python3 shebang), from jsk-ros-pkg/jsk_common#1832, as a ROS2-only buildtool_depend (>= 3.0.2) that stays off rosidl's build dependencies. joint_states_logger.py / network_states_logger.py: main with ros_compat.init_node()/spin() instead of the ROS_VERSION branch, no explicit private_name(). Uses jsk-ros-pkg/jsk_common#1831 (>= 3.0.2 on ROS2); the ROS1 fallback forwards the new functions to rospy. Co-Authored-By: Claude Opus 5.5 <<noreply@anthropic.com>>
-
Contributors: Kei Okada
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| catkin | |
| ament_cmake | |
| ros_environment | |
| ament_cmake_python | |
| python-setuptools | |
| jsk_ros1_ros2_compat | |
| pr2_msgs | |
| sensor_msgs | |
| std_msgs | |
| rclpy | |
| python-influxdb | |
| python-tz |
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| eus_teleop |
Launch files
- launch/fetch_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- launch/influxdb_logger.launch
-
- host
- port
- database
- launch_joint_states_logger [default: true]
- launch_map_transform_logger [default: true]
- launch_base_transform_logger [default: true]
- launch_network_states_logger [default: true]
- joint_states_topic [default: /joint_states]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg database)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg database)/wlan0/receive]
- launch/pr2_battery_logger.launch
-
- host
- port
- database
- battery_states_topic
- sample/baxter_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: baxter]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /robot/joint_states]
- base_frame_id [default: base]
- sample/fetch_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: fetch15]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery_state]
- map_frame_id [default: map]
- base_frame_id [default: base_link]
- network_states_transmit_topic [default: /$(arg robot_name)/wlan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wlan0/receive]
- sample/pr2_influxdb_logger.launch
-
- host [default: localhost]
- port [default: 8086]
- robot_name [default: pr1040]
- database [default: $(arg robot_name)]
- joint_states_topic [default: /joint_states]
- battery_states_topic [default: /battery/server2]
- map_frame_id [default: map]
- base_frame_id [default: base_footprint]
- network_states_transmit_topic [default: /$(arg robot_name)/wan0/transmit]
- network_states_receive_topic [default: /$(arg robot_name)/wan0/receive]