 ROS Index

Package Summary
| Version | 0.8.0 |
| License | Apache 2 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/autowarefoundation/autoware_tools.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-10-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Taiki Tanaka
- Tomoya Kimura
Authors
ParameterEstimation
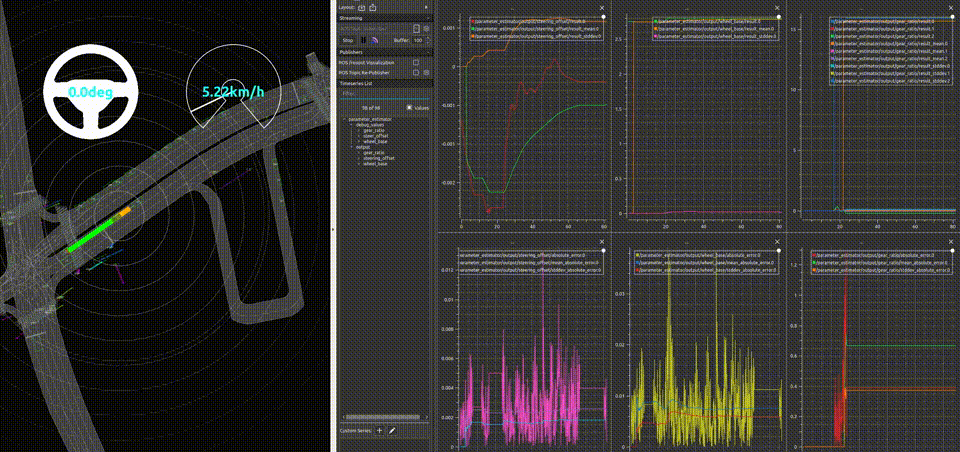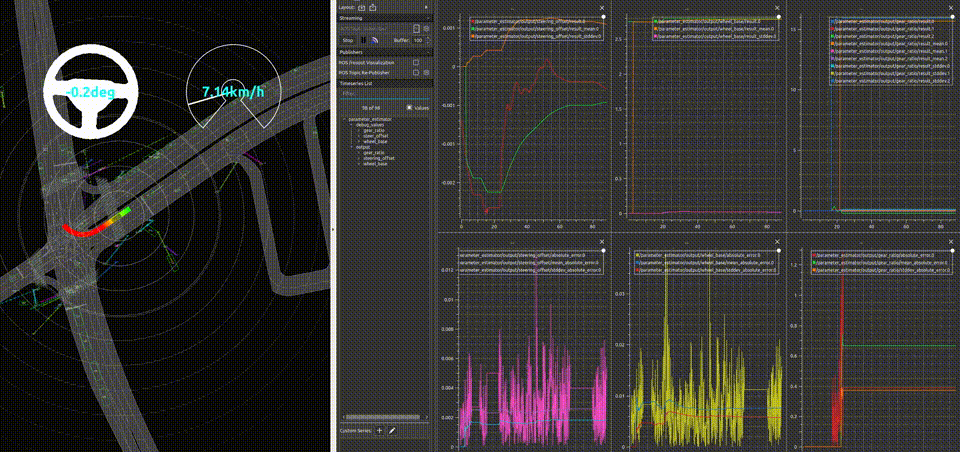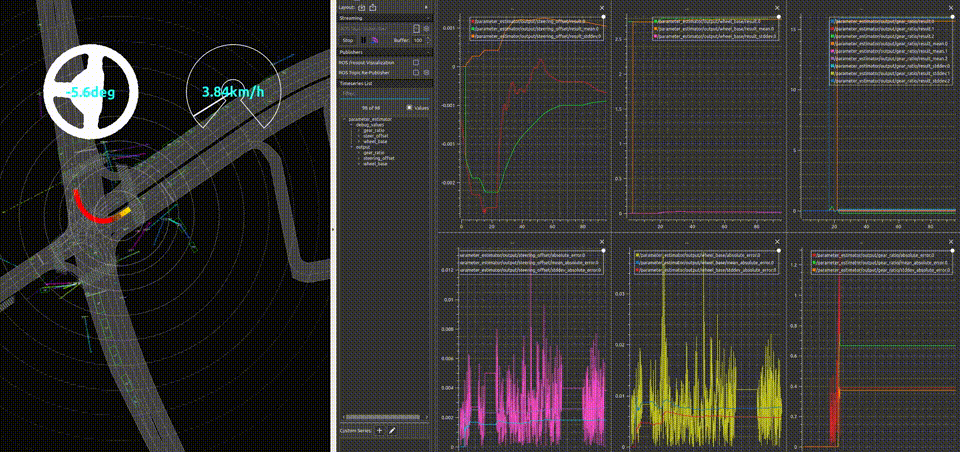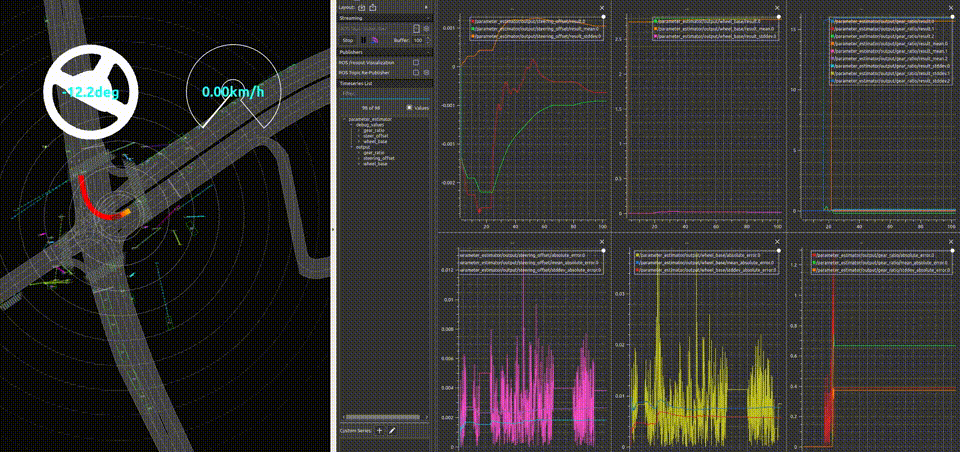
This parameter estimation node estimates a default parameters from inputs for steer offset,wheel base and gear ratio.
I/O
input
The following topics are used to estimate the parameters.
-
/sensing/imu/imu_data: used as vehicle angular velocity -
/vehicle/status/twist: used as vehicle velocity -
/vehicle/status/steering: used as vehicle steering angle (Only used in Steer Offset Estimator & Wheel Base Estimator) -
/calibration/vehicle/handle_status: used as vehicle handle angle (Only used in Gear Estimator) -
/vehicle/engage: used to check the driving operation status
output
The following topics are the output
/vehicle/status/gear_ratio/vehicle/status/steering_offset/vehicle/status/wheel_base
For users, the EstimationResult.msg output contains the following items:
- result: Estimated result.
- result_mean: Average value of result.
- result_stddev: Standard deviation value of the estimated parameter
- absolute_error: Absolute error of the estimated parameters
- mean_absolute_error: Mean absolute error of the estimated parameters
- stddev_absolute_error: Standard Deviation of absolute error of the estimated parameters
These values can be confirmed in plot_juggler
- To display in the plot juggler, you need to drag the result into the table, currently plot juggler cannot auto display the value
How to Run Parameter Estimator
Note: You need to build the Autoware beforehand.
The following command will start the parameter estimation node.
ros2 launch parameter_estimator parameter_estimator.launch.xml vehicle_model:=lexus
- The following arguments are using to select the estimator, default is true
- select_gear_ratio_estimator
- select_steer_offset_estimator
- select_wheel_base_estimator
- To deselect the specific estimator, you need to set estimator to false
- Example, the following command will only launch gear ratio estimator
ros2 launch parameter_estimator parameter_estimator.launch.xml vehicle_model:=lexus select_steer_offset_estimator:=false select_wheel_base_estimator:=false
If you want to launch with Rviz, use the following launch file. Currently unavailable
# Launch parameter Estimator with the Autoware
$ ros2 launch parameter_estimator parameter_estimator_with_simulation.launch.xml map_path:=.../kashiwanoha2/ vehicle_model:=jpntaxi sensor_model:=aip_xx1 rviz:=true
How to check the estimated parameters
The necessary information is plotted in the plot_juggler, which displays the following information from top to bottom.
- First row: Estimation results confirmation
- Second row: error for estimation
You need to adjust the value of (valid_min_) or (valid_max_). according to the standard deviation to determine the validity of the data.
Estimation results confirmation
Check the estimation results.
- result : parameter estimated at each step
- result_mean : Average of the parameters
- result_stddev : Standard deviation of the estimated parameters
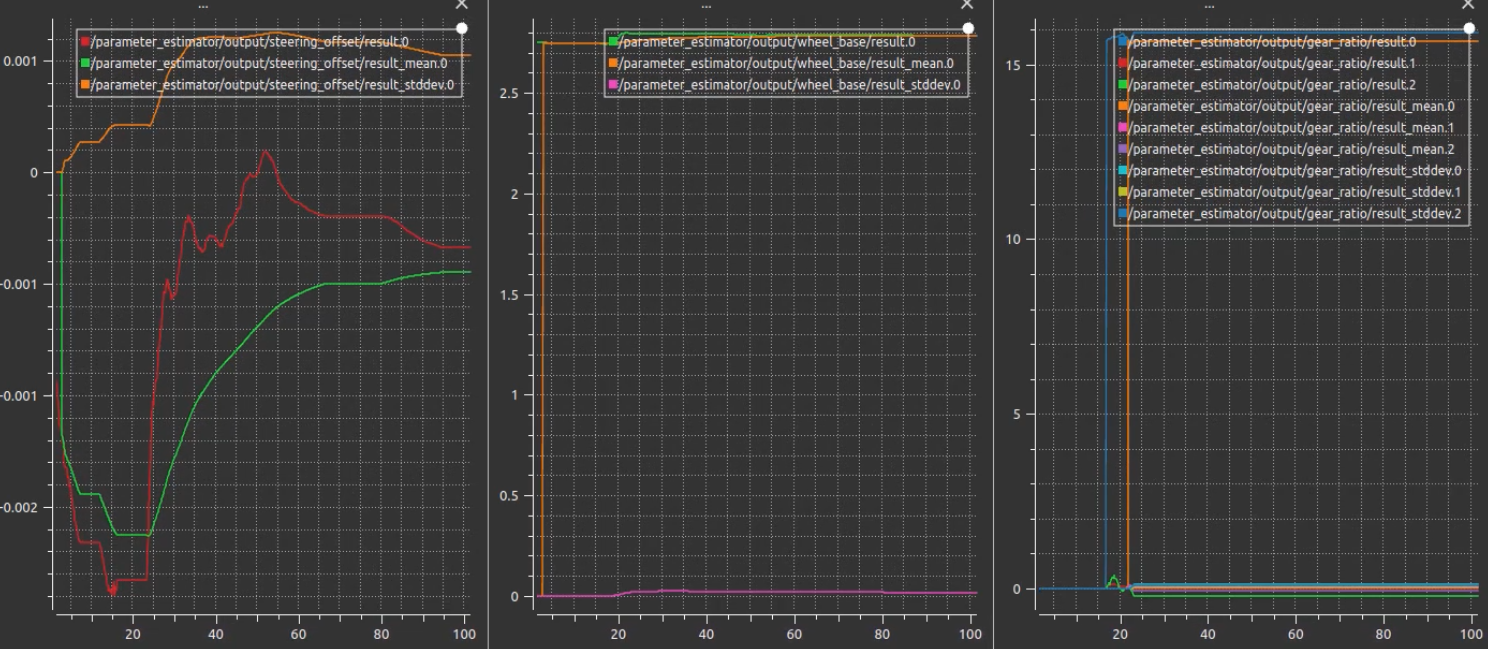
It is preferable to use the _mean for the calibration results.
The parameters estimation starts when enough data is stored. The output value is zero until it is ready.
Error for parameters estimation
Check the statistics of the errors in the input/output data after the parameter estimation.
- absolute_error : absolute error of measured and estimated of the parameters estimation
- mean_absolute_error : Mean of the absolute error calculated in each estimation step
File truncated at 100 lines see the full file
Changelog for package parameter_estimator
0.8.0 (2026-10-19)
-
fix(deviation_evaluator, parameter_estimator): migrate map launch to component_map.launch.xml (#466) autowarefoundation/autoware_launch#1980 renamed tier4_map_launch to autoware_map_launch and decomposed its map.launch.xml aggregator into per-node launch files, so there is no more single map.launch.xml; the exported map composition is now autoware_launch/launch/components/component_map.launch.xml. These launch files still included $(find-pkg-share tier4_map_launch)/launch/map.launch.xml, so the pre-commit "check package depends" hook kept re-adding the removed tier4_map_launch as an exec_depend even after #465 dropped it from package.xml -- leaving the dependency unresolvable and autoware.universe's build-and-test-packages-above-differential red. Switch both launch files to component_map.launch.xml (from autoware_launch, an existing exec_depend), which resolves the map paths from map_path and loads the map parameters internally from autoware_map_config. With the tier4_map_launch / autoware_map_launch references gone, drop both from package.xml; the map nodes remain available transitively through autoware_launch. Co-authored-by: Masaya Kataoka <<cld-masaya.kataoka@tier4.jp>> Co-authored-by: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>>
-
fix(deviation_evaluator, parameter_estimator): rename tier4_map_launch dependency to autoware_map_launch (#465)
* fix(deviation_evaluator, parameter_estimator): rename tier4_map_launch dependency to autoware_map_launch autowarefoundation/autoware_launch#1980 (merged) renamed the tier4_map_launch package to autoware_map_launch. deviation_evaluator and parameter_estimator still exec_depend on the now-removed tier4_map_launch, so rosdep can no longer resolve the key and autoware.universe's build-and-test-packages-above-differential job fails at dependency resolution on any PR whose reverse-dependency set includes these tools. Point the exec_depend at the new autoware_map_launch package (kept in sorted order). Both packages already exec_depend on autoware_launch, which lives in the same repository as autoware_map_launch, so the new key resolves. Note: the launch files still include [$(find-pkg-share tier4_map_launch)/launch/map.launch.xml]{.title-ref}, which was decomposed into per-node launch files in autoware_map_launch. Updating those includes is a separate runtime follow-up; this change fixes the packaging/rosdep breakage. Co-Authored-By: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>>
* style(pre-commit): autofix ---------Co-authored-by: Masaya Kataoka <<cld-masaya.kataoka@tier4.jp>> Co-authored-by: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>> Co-authored-by: pre-commit-ci[bot] <66853113+pre-commit-ci[bot]@users.noreply.github.com>
-
Contributors: Masaya Kataoka
0.7.0 (2026-05-01)
0.6.0 (2026-02-14)
0.5.0 (2025-12-30)
0.4.0 (2025-11-16)
0.3.0 (2025-08-11)
-
fix(parameter_estimatior): update package dependencies (#280)
- fix(parameter_estimatior): update package dependencies
* style(pre-commit): autofix ---------Co-authored-by: t4-adc <<grp-rd-1-adc-admin@tier4.jp>> Co-authored-by: pre-commit-ci[bot] <66853113+pre-commit-ci[bot]@users.noreply.github.com>
-
chore: sync files (#214)
-
Contributors: Kazunori-Nakajima, awf-autoware-bot[bot]
0.2.0 (2025-03-24)
0.1.0 (2025-01-28)
-
unify version to 0.0.0
-
feat(parameter_estimator)!: replace tier4_debug_msgs with tier4_internal_debug_msgs (#198)
- feat(parameter_estimator)!: replace tier4_debug_msgs with tier4_internal_debug_msgs
* style(pre-commit): autofix ---------Co-authored-by: pre-commit-ci[bot]
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/parameter_estimator.launch.xml
-
- vehicle_model [default: lexus]
- select_gear_ratio_estimator [default: true]
- select_steer_offset_estimator [default: true]
- select_wheel_base_estimator [default: true]
- invert_imu_z [default: true]
- is_showing_debug_info [default: true]
- parameter_estimator_param [default: $(find-pkg-share parameter_estimator)/config/parameter_estimator_param.yaml]
- imu_twist [default: /sensing/imu/imu_data]
- use_auto_mode [default: false]
- show_plot [default: false]
- launch/parameter_estimator_with_simulation.launch.xml
-
- map_path — point cloud and lanelet2 map directory path
- vehicle_model
- sensor_model
- rviz [default: true] — launch rviz
- lanelet2_map_file [default: lanelet2_map.osm]
- pointcloud_map_file [default: pointcloud_map.pcd]
Messages
Services
Plugins
Recent questions tagged parameter_estimator at Robotics Stack Exchange
Package Summary
| Version | 0.8.0 |
| License | Apache 2 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/autowarefoundation/autoware_tools.git |
| VCS Type | git |
| VCS Version | main |
| Last Updated | 2026-10-22 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Taiki Tanaka
- Tomoya Kimura
Authors
ParameterEstimation
This parameter estimation node estimates a default parameters from inputs for steer offset,wheel base and gear ratio.
I/O
input
The following topics are used to estimate the parameters.
-
/sensing/imu/imu_data: used as vehicle angular velocity -
/vehicle/status/twist: used as vehicle velocity -
/vehicle/status/steering: used as vehicle steering angle (Only used in Steer Offset Estimator & Wheel Base Estimator) -
/calibration/vehicle/handle_status: used as vehicle handle angle (Only used in Gear Estimator) -
/vehicle/engage: used to check the driving operation status
output
The following topics are the output
/vehicle/status/gear_ratio/vehicle/status/steering_offset/vehicle/status/wheel_base
For users, the EstimationResult.msg output contains the following items:
- result: Estimated result.
- result_mean: Average value of result.
- result_stddev: Standard deviation value of the estimated parameter
- absolute_error: Absolute error of the estimated parameters
- mean_absolute_error: Mean absolute error of the estimated parameters
- stddev_absolute_error: Standard Deviation of absolute error of the estimated parameters
These values can be confirmed in plot_juggler
- To display in the plot juggler, you need to drag the result into the table, currently plot juggler cannot auto display the value
How to Run Parameter Estimator
Note: You need to build the Autoware beforehand.
The following command will start the parameter estimation node.
ros2 launch parameter_estimator parameter_estimator.launch.xml vehicle_model:=lexus
- The following arguments are using to select the estimator, default is true
- select_gear_ratio_estimator
- select_steer_offset_estimator
- select_wheel_base_estimator
- To deselect the specific estimator, you need to set estimator to false
- Example, the following command will only launch gear ratio estimator
ros2 launch parameter_estimator parameter_estimator.launch.xml vehicle_model:=lexus select_steer_offset_estimator:=false select_wheel_base_estimator:=false
If you want to launch with Rviz, use the following launch file. Currently unavailable
# Launch parameter Estimator with the Autoware
$ ros2 launch parameter_estimator parameter_estimator_with_simulation.launch.xml map_path:=.../kashiwanoha2/ vehicle_model:=jpntaxi sensor_model:=aip_xx1 rviz:=true
How to check the estimated parameters
The necessary information is plotted in the plot_juggler, which displays the following information from top to bottom.
- First row: Estimation results confirmation
- Second row: error for estimation
You need to adjust the value of (valid_min_) or (valid_max_). according to the standard deviation to determine the validity of the data.
Estimation results confirmation
Check the estimation results.
- result : parameter estimated at each step
- result_mean : Average of the parameters
- result_stddev : Standard deviation of the estimated parameters
It is preferable to use the _mean for the calibration results.
The parameters estimation starts when enough data is stored. The output value is zero until it is ready.
Error for parameters estimation
Check the statistics of the errors in the input/output data after the parameter estimation.
- absolute_error : absolute error of measured and estimated of the parameters estimation
- mean_absolute_error : Mean of the absolute error calculated in each estimation step
File truncated at 100 lines see the full file
Changelog for package parameter_estimator
0.8.0 (2026-10-19)
-
fix(deviation_evaluator, parameter_estimator): migrate map launch to component_map.launch.xml (#466) autowarefoundation/autoware_launch#1980 renamed tier4_map_launch to autoware_map_launch and decomposed its map.launch.xml aggregator into per-node launch files, so there is no more single map.launch.xml; the exported map composition is now autoware_launch/launch/components/component_map.launch.xml. These launch files still included $(find-pkg-share tier4_map_launch)/launch/map.launch.xml, so the pre-commit "check package depends" hook kept re-adding the removed tier4_map_launch as an exec_depend even after #465 dropped it from package.xml -- leaving the dependency unresolvable and autoware.universe's build-and-test-packages-above-differential red. Switch both launch files to component_map.launch.xml (from autoware_launch, an existing exec_depend), which resolves the map paths from map_path and loads the map parameters internally from autoware_map_config. With the tier4_map_launch / autoware_map_launch references gone, drop both from package.xml; the map nodes remain available transitively through autoware_launch. Co-authored-by: Masaya Kataoka <<cld-masaya.kataoka@tier4.jp>> Co-authored-by: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>>
-
fix(deviation_evaluator, parameter_estimator): rename tier4_map_launch dependency to autoware_map_launch (#465)
* fix(deviation_evaluator, parameter_estimator): rename tier4_map_launch dependency to autoware_map_launch autowarefoundation/autoware_launch#1980 (merged) renamed the tier4_map_launch package to autoware_map_launch. deviation_evaluator and parameter_estimator still exec_depend on the now-removed tier4_map_launch, so rosdep can no longer resolve the key and autoware.universe's build-and-test-packages-above-differential job fails at dependency resolution on any PR whose reverse-dependency set includes these tools. Point the exec_depend at the new autoware_map_launch package (kept in sorted order). Both packages already exec_depend on autoware_launch, which lives in the same repository as autoware_map_launch, so the new key resolves. Note: the launch files still include [$(find-pkg-share tier4_map_launch)/launch/map.launch.xml]{.title-ref}, which was decomposed into per-node launch files in autoware_map_launch. Updating those includes is a separate runtime follow-up; this change fixes the packaging/rosdep breakage. Co-Authored-By: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>>
* style(pre-commit): autofix ---------Co-authored-by: Masaya Kataoka <<cld-masaya.kataoka@tier4.jp>> Co-authored-by: Claude Opus 4.8 (1M context) <<noreply@anthropic.com>> Co-authored-by: pre-commit-ci[bot] <66853113+pre-commit-ci[bot]@users.noreply.github.com>
-
Contributors: Masaya Kataoka
0.7.0 (2026-05-01)
0.6.0 (2026-02-14)
0.5.0 (2025-12-30)
0.4.0 (2025-11-16)
0.3.0 (2025-08-11)
-
fix(parameter_estimatior): update package dependencies (#280)
- fix(parameter_estimatior): update package dependencies
* style(pre-commit): autofix ---------Co-authored-by: t4-adc <<grp-rd-1-adc-admin@tier4.jp>> Co-authored-by: pre-commit-ci[bot] <66853113+pre-commit-ci[bot]@users.noreply.github.com>
-
chore: sync files (#214)
-
Contributors: Kazunori-Nakajima, awf-autoware-bot[bot]
0.2.0 (2025-03-24)
0.1.0 (2025-01-28)
-
unify version to 0.0.0
-
feat(parameter_estimator)!: replace tier4_debug_msgs with tier4_internal_debug_msgs (#198)
- feat(parameter_estimator)!: replace tier4_debug_msgs with tier4_internal_debug_msgs
* style(pre-commit): autofix ---------Co-authored-by: pre-commit-ci[bot]
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/parameter_estimator.launch.xml
-
- vehicle_model [default: lexus]
- select_gear_ratio_estimator [default: true]
- select_steer_offset_estimator [default: true]
- select_wheel_base_estimator [default: true]
- invert_imu_z [default: true]
- is_showing_debug_info [default: true]
- parameter_estimator_param [default: $(find-pkg-share parameter_estimator)/config/parameter_estimator_param.yaml]
- imu_twist [default: /sensing/imu/imu_data]
- use_auto_mode [default: false]
- show_plot [default: false]
- launch/parameter_estimator_with_simulation.launch.xml
-
- map_path — point cloud and lanelet2 map directory path
- vehicle_model
- sensor_model
- rviz [default: true] — launch rviz
- lanelet2_map_file [default: lanelet2_map.osm]
- pointcloud_map_file [default: pointcloud_map.pcd]