 ROS Index

|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from ros2_rm_robot repocontrol_arm_move force_position_control get_arm_state rm_bringup rm_control rm_description rm_doc rm_driver rm_example rm_gazebo rm_install rm_moveit2 rm_63_config rm_65_config rm_75_config rm_eco62_config rm_eco63_config rm_eco65_config rm_gen72_config rm_rx75_config rm_ros_interfaces |
ROS Distro
|
Package Summary
| Version | 1.7.1 |
| License | Apache-2.0 |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/realmanrobot/ros2_rm_robot.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-30 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- ubuntu
Authors
Launch examples
After building and sourcing the workspace, display an RM65 model with integrated force sensing:
# Model preview for simulation, generation 3, or older generation 4 software (GUI joint controls)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=true

# Real-robot state display (generation 4 controller software > 1.0.5; start rm_driver first)
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6fb use_rviz:=true use_joint_state_publisher_gui:=false
Generation 4 controller software 1.0.6 and later names the former 6fb end link 6f. This standalone display does not query controller generation: keep 65-6fb to select the same model. Real-robot display uses joint states from the driver without enabling the GUI joint-state publisher. See the generation-specific model table.
Content
- 1.rm_description Package Description
- 2.rm_description Package Use
- 3.rm_description Package Architecture Description
- 3.1Overview of Package Files
- 4.rm_description Topic Description
rm_description_Package_Description
rm_description is a function package for displaying the robot model and TF transformation. Through this package, we can realize the linkage effect between a virtual robotic arm in a computer and a real robot arm in reality. In the moveit2 control, we also need the support of this package. This package is introduced in detail in the following aspects.
- 1.Package use.
- 2.Package architecture description.
- 3.Package topic description. Through the introduction of the three parts, it can help you:
- 1.Understand the package use.
- 2.Familiar with the file structure and function of the package.
- 3.Familiar with the topic related to the package for easy development and use.
Source code address:https://github.com/RealManRobot/ros2_rm_robot.git.
rm_description_Package_Use
Model selection defaults to
model:=auto: variants with matching assets use colored DAE, while other variants use STL. Selectmodel:=stlfor the original appearance, ormodel:=daeto require DAE. See the supported arm_type values and MoveIt model selection.
The generic entry is recommended:
ros2 launch rm_description rm_description.launch.py \
  arm_type:=65-6f use_joint_state_publisher_gui:=true use_rviz:=true
It explicitly supports the 21 catalogued model/variant combinations. model accepts
auto/stl/dae and defaults to auto; forcing dae for a variant without matching assets
fails before nodes start. Other common arguments include use_sim_time, joint_states_topic,
use_joint_state_bridge, use_joint_state_publisher_gui, and use_rviz.
RX75 also accepts left_xyz/left_rpy/right_xyz/right_rpy. Invalid
combinations fail before nodes are started. The historical
*_display.launch.py commands below are compatibility wrappers and also default to
model:=auto. Other original arguments and defaults are retained. Append model:=stl
to display the original STL appearance.
Select the model and end-link version directly with arm_type, for example
65-6fb or eco63-6fb. A bare family selects its standard version.
First, after configuring the environment and completing the connection, we can directly start the node and run the rm_description package.
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_display.launch.py
The rm_<arm_type>_display.launch.py pattern applies to 65, 63, 63_III, 75, eco62, eco63, eco65, gen72, and gen72_II.
The command to start the six-axis force version is currently available for 63, 65, 75, and eco65:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6f_display.launch.py
The command to start the integrated six-axis force version is currently available for 63, 63_III, 65, 75, eco63, eco65, and rx75:
rm@rm-desktop:~$ ros2 launch rm_description rm_<arm_type>_6fb_display.launch.py
File truncated at 100 lines see the full file
Package Dependencies
| Deps | Name |
|---|---|
| ament_cmake | |
| ament_cmake_python | |
| ament_index_python | |
| joint_state_publisher_gui | |
| launch | |
| launch_ros | |
| rclpy | |
| robot_state_publisher | |
| rviz2 | |
| sensor_msgs | |
| xacro | |
| ament_lint_auto | |
| ament_lint_common |
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rm_description at Robotics Stack Exchange
|
|
rm_description package from rm_description reporm_description |
ROS Distro
|
Package Summary
| Version | 0.1.9 |
| License | BSD |
| Build type | CATKIN |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/rm-controls/rm_description.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2022-06-16 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Qiayuan Liao
Authors
- Qiayuan Liao
rm_description
Overview
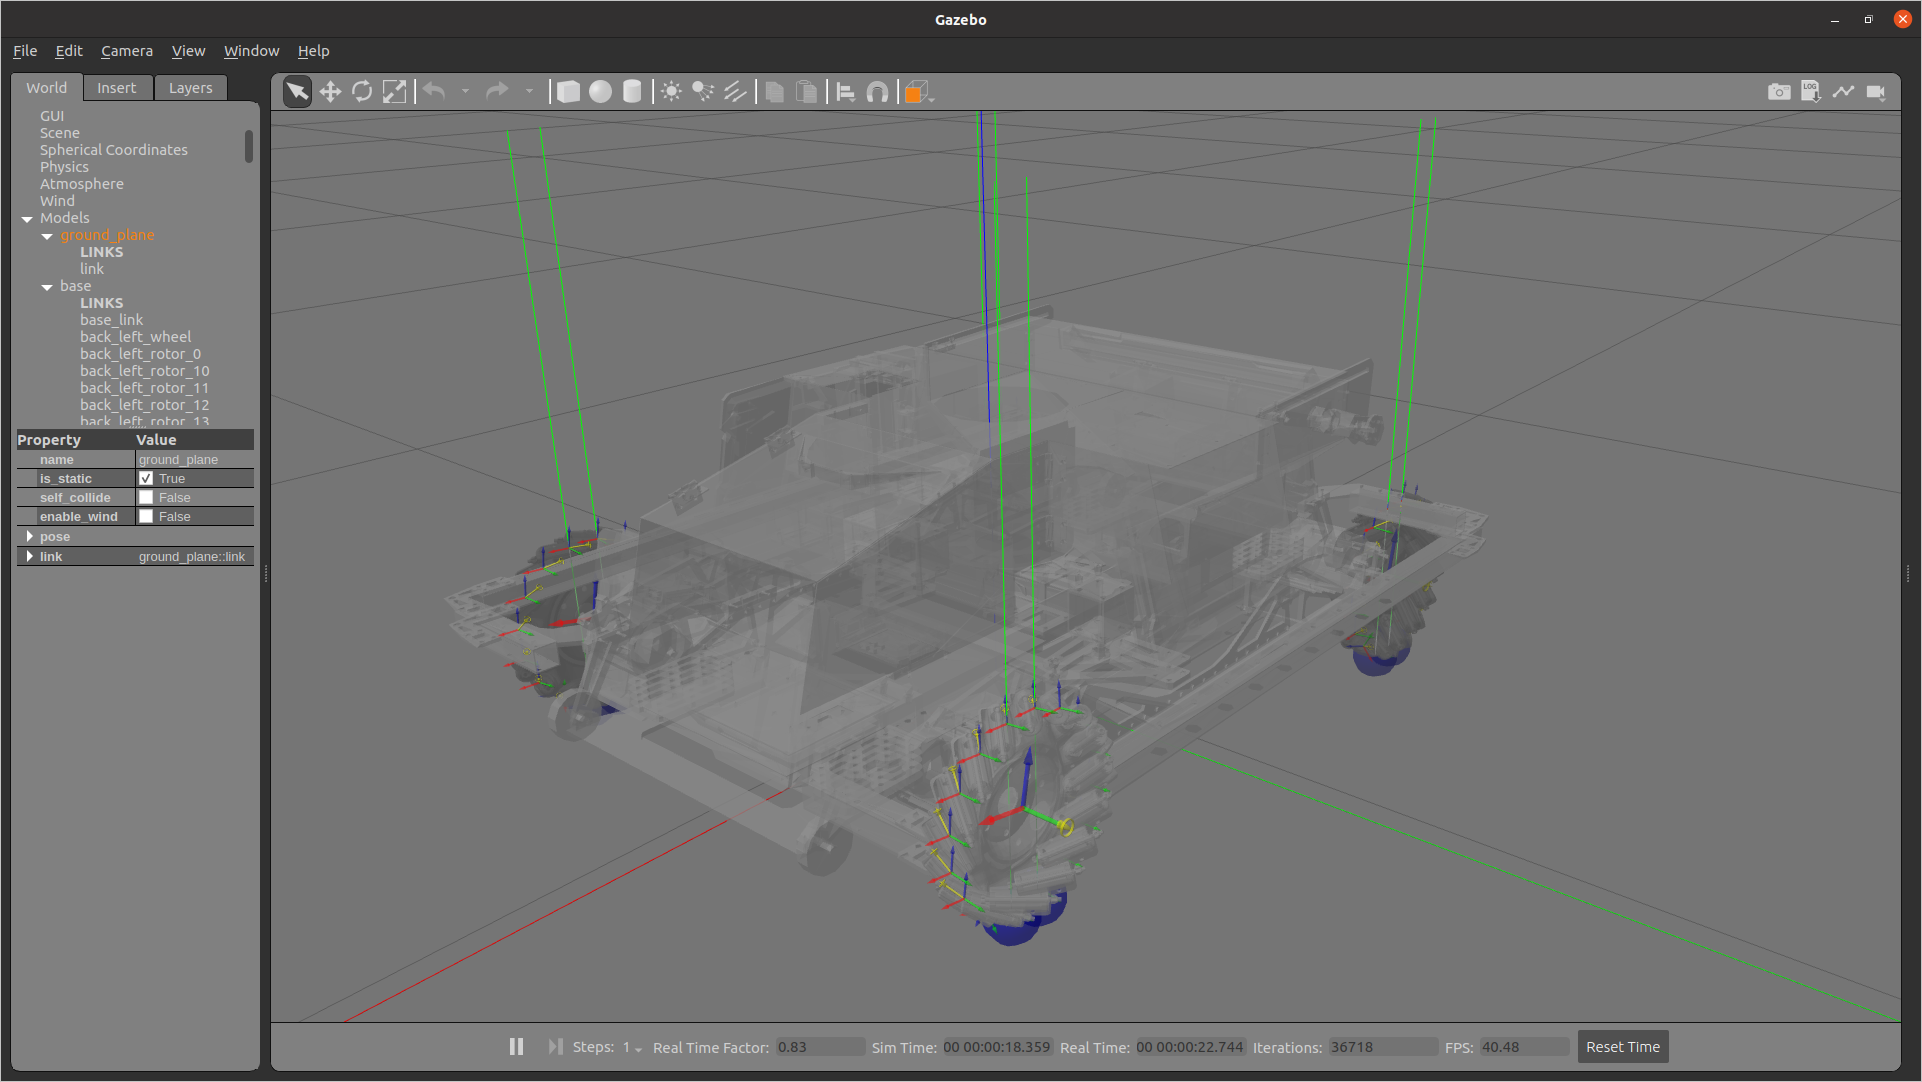
This is a ROS package with description files of RoboMaster robot made by DynamicX.
Keywords: RoboMaster, URDF, description
Or, add some keywords to the Bitbucket or GitHub repository.
License
The source code is released under a BSD 3-Clause license.
Author: QiayuanLiao
Affiliation: DynamicX
Maintainer: QiayuanLiao, liaoqiayuan@gmail.com
The rm_description package has been tested under [ROS] Noetic on respectively 18.04 and 20.04. This is research code, expect that it changes often and any fitness for a particular purpose is disclaimed.
Installation
Building from Source
Dependencies
- Robot Operating System (ROS) (middleware for robotics),
-
rm_gazebo if
use_rm_gazbe - gazebo_ros
- gazebo_ros_control
- xacro
Building
To build from source, clone the latest version from this repository into your catkin workspace and compile the package using
cd catkin_workspace/src
git clone git@github.com:gdut-dynamic-x/rm_description.git
# git clone https://github.com/gdut-dynamic-x/rm_description.git
cd ../
rosdep install --from-paths . --ignore-src
catkin build # Actually nothing to build
Usage
Run the simulation with:
roslaunch rm_description hero.launch
Config files
- worlds/empty.worlds Simulate physics eigen params.
Launch files
-
hero.launch: Launch Gazebo and load hero robot.
Loading argument set
-
load_chassisLoad chassis URDF. Default:true. -
load_gimbalLoad gimbal URDF. Default:true. -
load_shooterLoad shooter URDF. Default:true. -
load_gazeboLoad Gazebo params and run Gazebo. Default:true. -
use_rm_gazeboUse Gazebo params and run Gazebo. Default:false. -
pausedPaused simulation when load Gazbeo. Default:true.
Chassis argument set
-
roller_typeHow to simulate the roller of mecanum wheel, setsimpleto use sphere roller for speed up simulation, setnonefor real robot. Default:realistic(use one sphere with two capsule roller.stl).
-
Bugs & Feature Requests
Please report bugs and request features using the Issue Tracker .
Changelog for package rm_description
0.1.9 (2022-04-01)
- Add omni wheel urdf
- Complete omni wheel urdf
- Add test launch file to check urdf
- Rename launch file.Delete roller_type in urdf.Change args of hook
- Merge pull request #21 from ye-luo-xi-tui/omni_wheel
- Fix errors of swerve urdf
- Add CI/CD action
- Create Doxyfile
- Create .pre-commit-config.yaml
- Add permissions to script
- Delete pre_release.yml
- Merge pull request #3 from YuuinlH/-master
- Merge pull request #4 from YuuinlH/-master
- Update deb_package.yml
- Merge pull request #5 from YuuinlH/-master
- Update package.sh
- Delete doxygen action(Uesless)
- Add"none"type of omni_wheel roller.Set"none"for real robot
- Fix error in check_joint.launch.Add rviz launch.
- Merge pull request #8 from ye-luo-xi-tui/-master
- Add LICENSE file
- Update the hero description files
- Modify the format error of hero urdf files
- Merge pull request #11 from Edwinlinks/-hero_urdf
- Contributors: Edwinlinks, QiayuanLiao, YuuinIH, qiayuan, yezi, mlione
0.1.8 (2021-12-7)
- Merge pull request #19 from ye-luo-xi-tui/fix_rmua_bug Fix rmua bug
- Change limit of rmua. (cherry picked from commit a1e4d841dd4cda83d50189a8f5d3bd84d604d244)
- Fix a bug in rmua urdf (cherry picked from commit cd6f7fac5c375cd74408620438039ca2c83437cd)
- Merge branch 'master' into master
- Update standard4.urdf.xacro and rm_hw/config/standard4.yaml.
- Merge remote-tracking branch 'origin/master'
- Merge pull request #16 from Edwinlinks/master Modify the date of standard in rm_description
- Modify the date of standard in rm_description
- Fix imu inertia and add imu to balance
- Merge branch 'master' into gimbal/opti_or_simplify
- Update CHANGELOG
- Update standard5's imu orientation
- Update IMU orientation of standard5.urdf.xacro
- Merge branch 'master' into gimbal/opti_or_simplify
- Merge branch 'master' into gimbal/opti_or_simplify
- Update URDF of imu
- Contributors: BruceLannn, Edwinlinks, QiayuanLiao, YuuinIH, qiayuan, yezi
0.1.7 (2021-09-26)
- 0.1.6
- Update CHANGELOG
- Update URDF of imu
- Contributors: qiayuan
0.1.6 (2021-09-26)
- Update URDF of imu
- Contributors: qiayuan
0.1.5 (2021-09-02)
0.1.4 (2021-09-02)
0.1.3 (2021-09-01)
- Merge branch 'master' into master
- Contributors: QiayuanLiao
- Merge branch 'master' into master
- Contributors: QiayuanLiao
0.1.2 (2021-08-14)
- Run pre-commit
- Contributors: qiayuan
0.1.1 (2021-08-12)
File truncated at 100 lines see the full file
Dependant Packages
| Name | Deps |
|---|---|
| rm_control | |
| rm_gazebo |
Launch files
- launch/check_joint.launch
-
- robot_type [default: $(env ROBOT_TYPE)] — Robot type [standard, hero, engineer]
- load_chassis [default: true]
- load_gimbal [default: true]
- load_shooter [default: true]
- load_arm [default: true]
- roller_type [default: simple] — simple or realistic