 ROS Index

Package Summary
| Version | 0.0.0 |
| License | BSD-3-Clause-Clear |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/castacks/airstack.git |
| VCS Type | git |
| VCS Version | develop |
| Last Updated | 2026-09-11 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Andrew Jong
Authors
RViz Tasks Panel
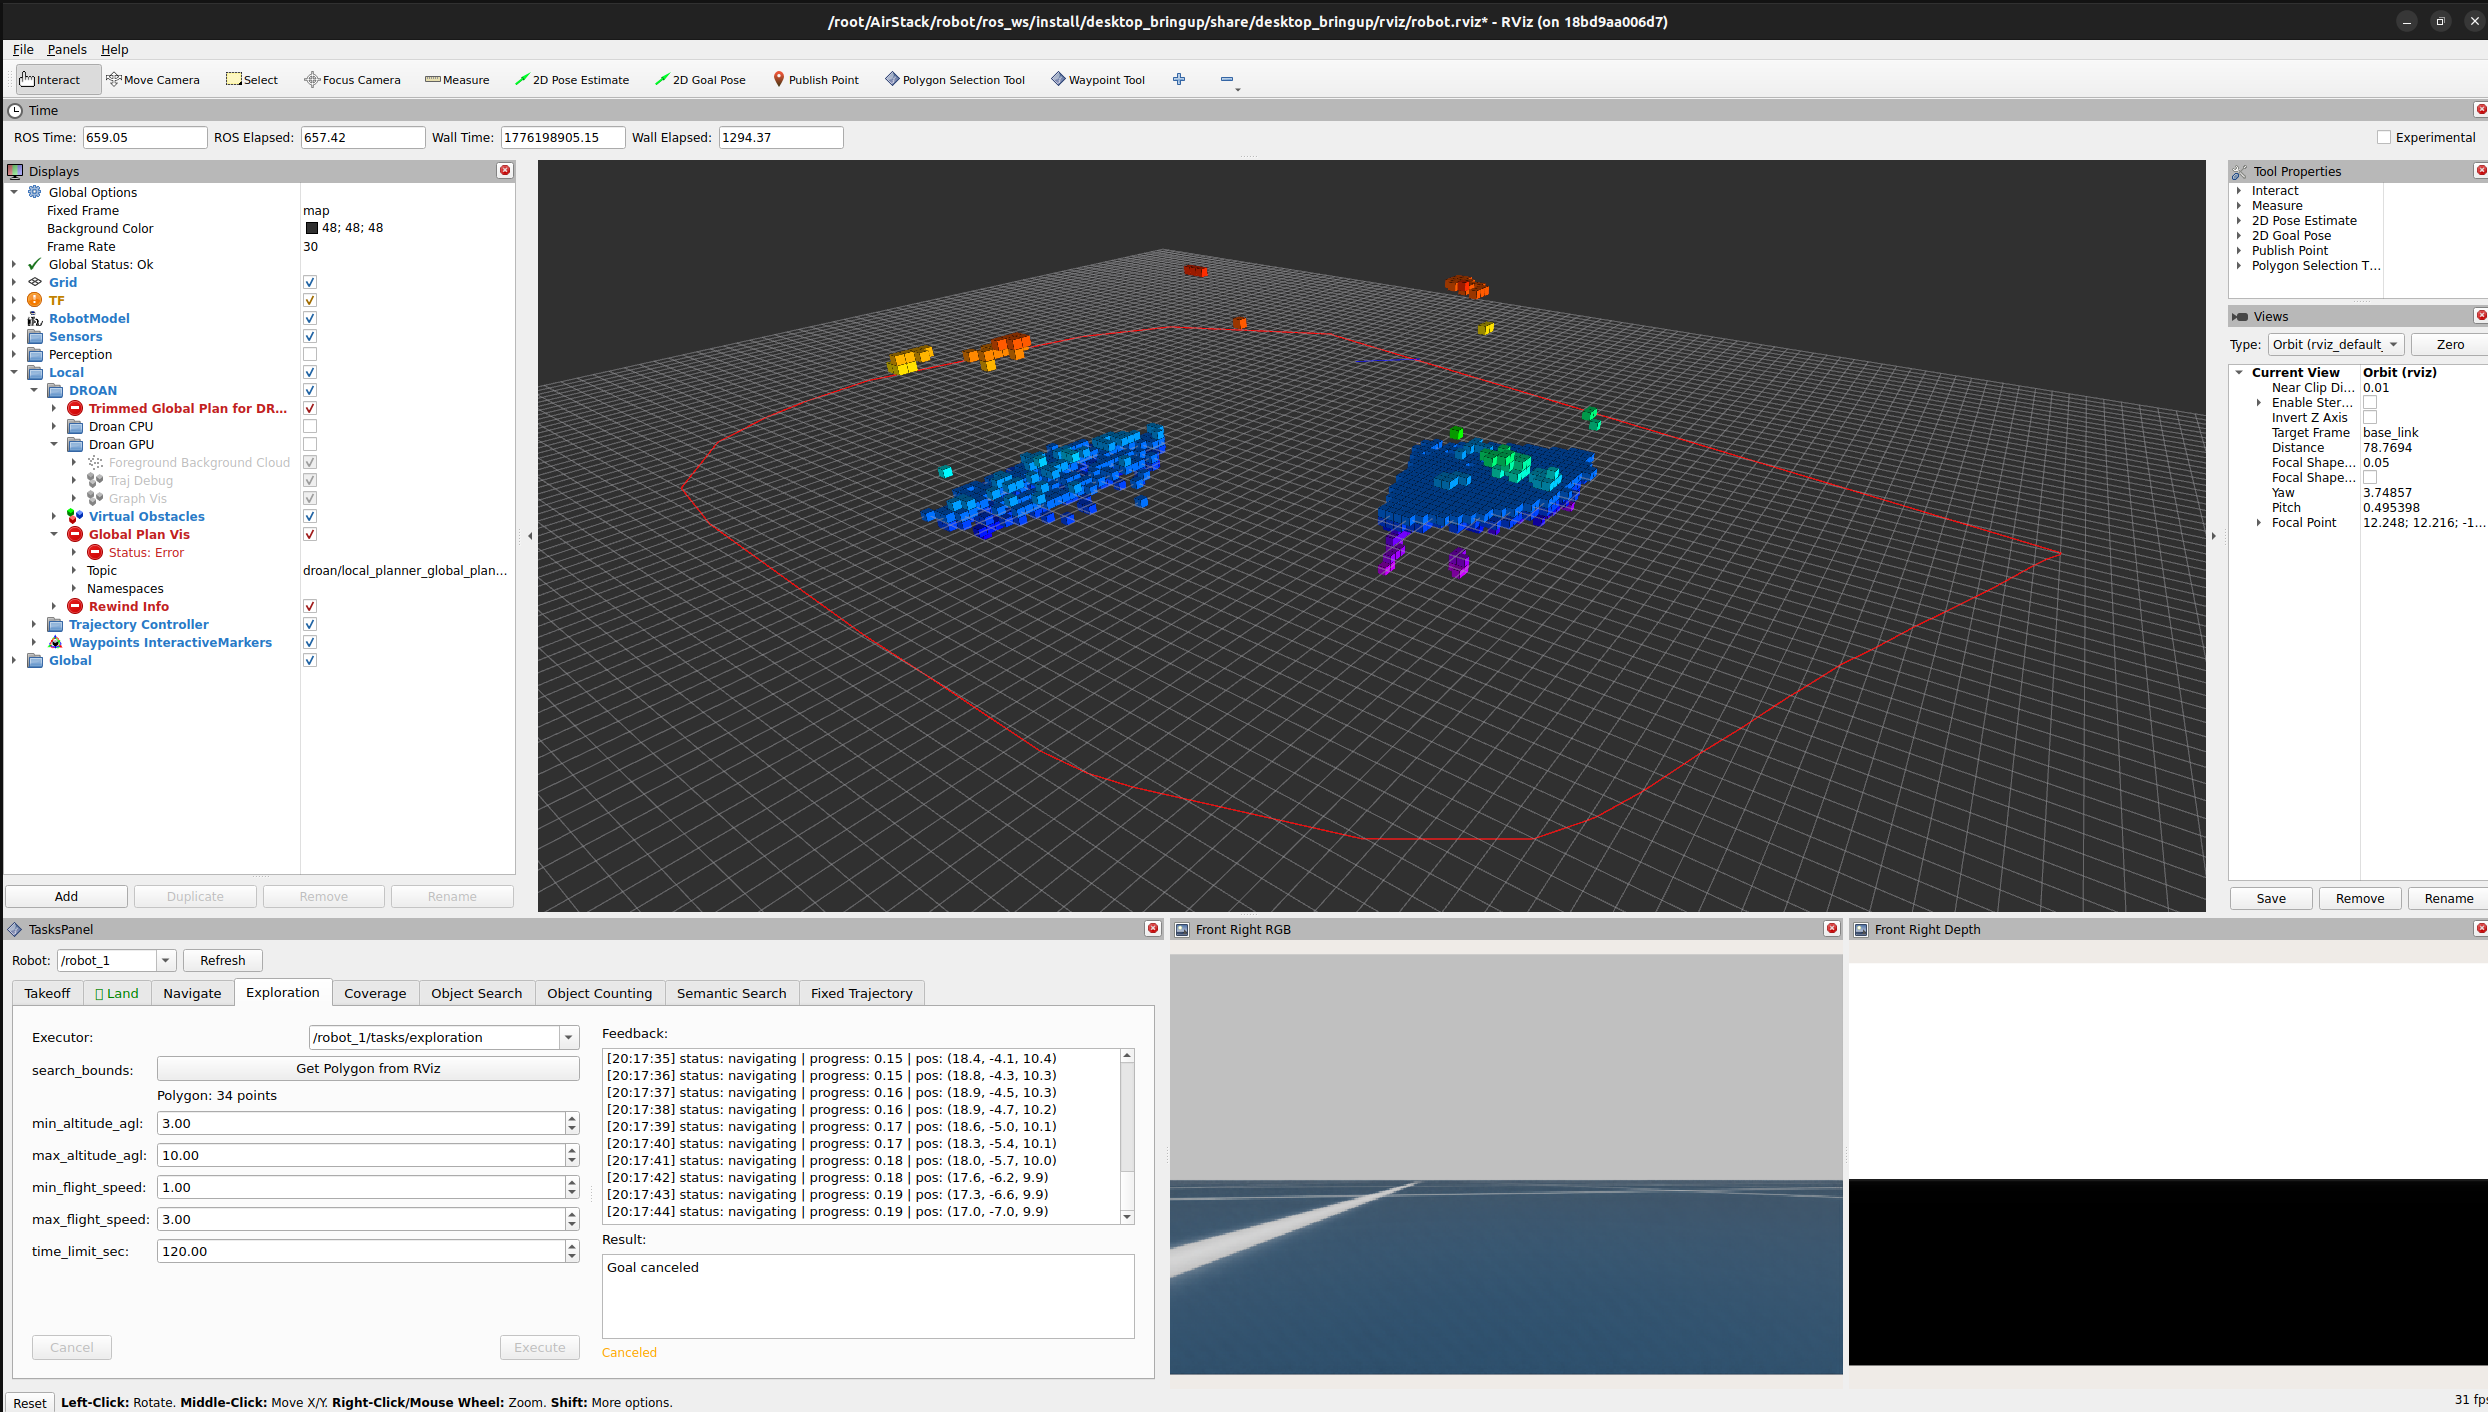
RViz2 panel plugin for dispatching and monitoring ROS 2 task action goals. Provides a tabbed GUI where operators can parameterize, execute, and cancel tasks on any discovered robot, with live feedback and result display.
Overview
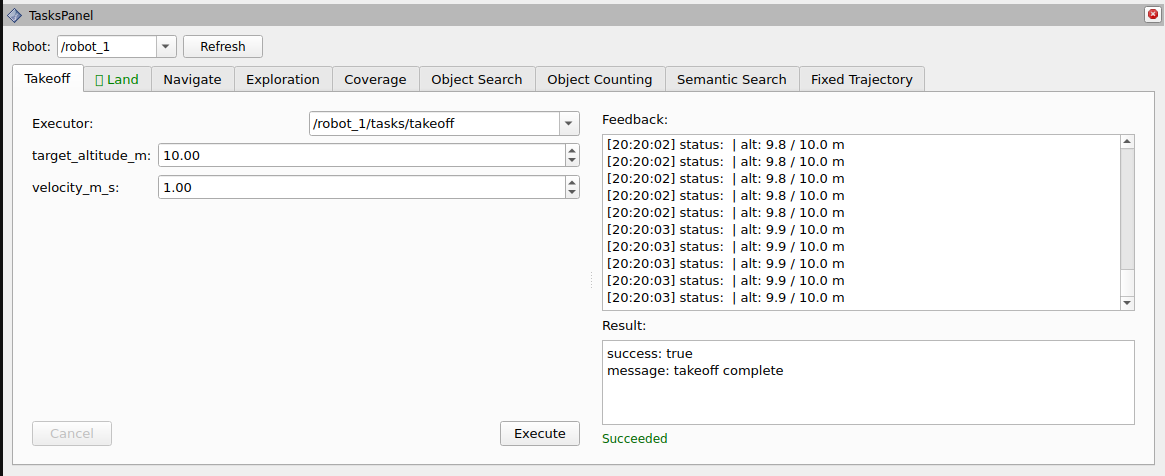
The Tasks Panel replaces CLI-based action goal dispatch with a graphical interface for all 8 AirStack task types. Each task type gets its own tab with auto-generated parameter widgets, an executor selector, and a feedback/result view.
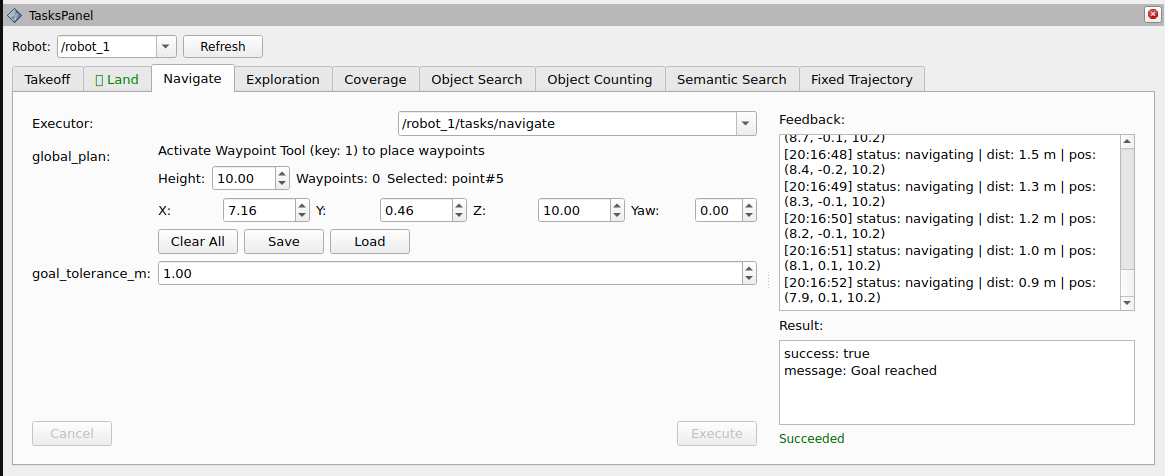
The Navigate tab integrates directly with the
waypoint_rviz2_plugin package’s shared WaypointManager
singleton, providing inline controls for placing, editing,
saving/loading, and executing waypoint-based navigation – no
separate waypoint panel needed.
+-----------------------------------------------------+
|  Tasks Panel                      Robot: [robot_1]   |
+-----------------------------------------------------+
| [Takeoff] [Land] [Navigate] [Exploration] [Coverage] |
+-----------------------------------------------------+
|  +- Goal Parameters -----+  +- Feedback & Result -+ |
|  | Executor: [/robot1/..] |  | Feedback:           | |
|  | Height: [2.0]  Wp: 3   |  | [live stream]       | |
|  | X:[1] Y:[2] Z:[2] Y:[0]|  |                     | |
|  | [Clear] [Save] [Load]  |  | Result:             | |
|  | goal_tolerance_m: [1.0] |  | [goal outcome]      | |
|  | [Cancel]     [Execute]  |  |                     | |
|  +-------------------------+  +---------------------+ |
+-----------------------------------------------------+
Features
- 8 task tabs with auto-generated goal parameter widgets
- Executor discovery – scans ROS 2 topics every 5 seconds to find running action servers
- Robot namespace selector – auto-populated from discovered action server namespaces
-
Polygon input – integrates with
rviz_polygon_selection_toolto capture 3D polygon selections -
Integrated waypoint controls – the Navigate tab embeds
waypoint management (height, X/Y/Z/Yaw editing, Clear, Save,
Load) via the shared
WaypointManagersingleton fromwaypoint_rviz2_plugin - Fixed Trajectory editor – type dropdown with auto-populated default attributes in an editable key-value table
- Live feedback – timestamped feedback messages stream in real time
- Result display – color-coded status (green = succeeded, red = aborted, orange = canceled)
- Config persistence – robot and executor selections are saved/restored with the RViz config
- Single-task lock – only one action may execute at a time to prevent conflicts
-
Airborne-only tasks – Land, Navigate, and all mission
tasks are disabled until the drone is airborne (subscribes to
is_airbornefromtakeoff_landing_planner); Takeoff is always available while idle
Supported Task Types
Tasks marked airborne-only are disabled until the drone is in the air.
| Tab | Action Type | Key Parameters | Airborne-only |
|---|---|---|---|
| Takeoff | TakeoffTask |
target_altitude_m, velocity_m_s
|
|
| Land | LandTask |
velocity_m_s |
✓ |
| Navigate | NavigateTask |
global_plan (Path), goal_tolerance_m
|
✓ |
| Exploration | ExplorationTask |
search_bounds (Polygon), altitude/speed, time_limit_sec
|
✓ |
| Coverage | CoverageTask |
coverage_area (Polygon), line_spacing_m, heading_deg
|
✓ |
| Semantic Search | SemanticSearchTask |
query, background_queries, search_area, confidence_threshold
|
✓ |
| Chat | ChatTask |
text, images (file upload) |
|
| Fixed Trajectory | FixedTrajectoryTask |
trajectory_spec, loop
|
✓ |
Widget Type Mapping
| ROS Type | Widget | Notes |
|---|---|---|
float32/float64
|
QDoubleSpinBox |
Range from registry |
int32 |
QSpinBox |
Range from registry |
string |
QLineEdit |
Free-text input |
bool |
QCheckBox |
Toggle |
geometry_msgs/Polygon |
QPushButton |
Calls get_selection service |
nav_msgs/Path |
Waypoint controls | Inline height/pose/buttons via WaypointManager |
airstack_msgs/FixedTrajectory |
QComboBox + QTableWidget
|
Type + attributes |
Dependencies
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
| Name |
|---|
| qtbase5-dev |
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged rviz_tasks_panel at Robotics Stack Exchange
Package Summary
| Version | 0.0.0 |
| License | BSD-3-Clause-Clear |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | |
| Checkout URI | https://github.com/castacks/airstack.git |
| VCS Type | git |
| VCS Version | develop |
| Last Updated | 2026-09-11 |
| Dev Status | UNKNOWN |
| Released | UNRELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Andrew Jong
Authors
RViz Tasks Panel
RViz2 panel plugin for dispatching and monitoring ROS 2 task action goals. Provides a tabbed GUI where operators can parameterize, execute, and cancel tasks on any discovered robot, with live feedback and result display.
Overview
The Tasks Panel replaces CLI-based action goal dispatch with a graphical interface for all 8 AirStack task types. Each task type gets its own tab with auto-generated parameter widgets, an executor selector, and a feedback/result view.
The Navigate tab integrates directly with the
waypoint_rviz2_plugin package’s shared WaypointManager
singleton, providing inline controls for placing, editing,
saving/loading, and executing waypoint-based navigation – no
separate waypoint panel needed.
+-----------------------------------------------------+
|  Tasks Panel                      Robot: [robot_1]   |
+-----------------------------------------------------+
| [Takeoff] [Land] [Navigate] [Exploration] [Coverage] |
+-----------------------------------------------------+
|  +- Goal Parameters -----+  +- Feedback & Result -+ |
|  | Executor: [/robot1/..] |  | Feedback:           | |
|  | Height: [2.0]  Wp: 3   |  | [live stream]       | |
|  | X:[1] Y:[2] Z:[2] Y:[0]|  |                     | |
|  | [Clear] [Save] [Load]  |  | Result:             | |
|  | goal_tolerance_m: [1.0] |  | [goal outcome]      | |
|  | [Cancel]     [Execute]  |  |                     | |
|  +-------------------------+  +---------------------+ |
+-----------------------------------------------------+
Features
- 8 task tabs with auto-generated goal parameter widgets
- Executor discovery – scans ROS 2 topics every 5 seconds to find running action servers
- Robot namespace selector – auto-populated from discovered action server namespaces
-
Polygon input – integrates with
rviz_polygon_selection_toolto capture 3D polygon selections -
Integrated waypoint controls – the Navigate tab embeds
waypoint management (height, X/Y/Z/Yaw editing, Clear, Save,
Load) via the shared
WaypointManagersingleton fromwaypoint_rviz2_plugin - Fixed Trajectory editor – type dropdown with auto-populated default attributes in an editable key-value table
- Live feedback – timestamped feedback messages stream in real time
- Result display – color-coded status (green = succeeded, red = aborted, orange = canceled)
- Config persistence – robot and executor selections are saved/restored with the RViz config
- Single-task lock – only one action may execute at a time to prevent conflicts
-
Airborne-only tasks – Land, Navigate, and all mission
tasks are disabled until the drone is airborne (subscribes to
is_airbornefromtakeoff_landing_planner); Takeoff is always available while idle
Supported Task Types
Tasks marked airborne-only are disabled until the drone is in the air.
| Tab | Action Type | Key Parameters | Airborne-only |
|---|---|---|---|
| Takeoff | TakeoffTask |
target_altitude_m, velocity_m_s
|
|
| Land | LandTask |
velocity_m_s |
✓ |
| Navigate | NavigateTask |
global_plan (Path), goal_tolerance_m
|
✓ |
| Exploration | ExplorationTask |
search_bounds (Polygon), altitude/speed, time_limit_sec
|
✓ |
| Coverage | CoverageTask |
coverage_area (Polygon), line_spacing_m, heading_deg
|
✓ |
| Semantic Search | SemanticSearchTask |
query, background_queries, search_area, confidence_threshold
|
✓ |
| Chat | ChatTask |
text, images (file upload) |
|
| Fixed Trajectory | FixedTrajectoryTask |
trajectory_spec, loop
|
✓ |
Widget Type Mapping
| ROS Type | Widget | Notes |
|---|---|---|
float32/float64
|
QDoubleSpinBox |
Range from registry |
int32 |
QSpinBox |
Range from registry |
string |
QLineEdit |
Free-text input |
bool |
QCheckBox |
Toggle |
geometry_msgs/Polygon |
QPushButton |
Calls get_selection service |
nav_msgs/Path |
Waypoint controls | Inline height/pose/buttons via WaypointManager |
airstack_msgs/FixedTrajectory |
QComboBox + QTableWidget
|
Type + attributes |
Dependencies
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
| Name |
|---|
| qtbase5-dev |